Motion planning
Plan a move among obstacles with plan_ompl, a move whose straight joint path is nearly
collision-free with plan_freespace, and a Cartesian toolpath with plan_cartesian; replan
every tick from the last solution with the low-level SQP API. Each plan_*
call runs a pipeline: the planner, a contact check of
the result, then time parameterization, and returns a PlanningResult. This page covers the
choice, the settings that matter for each planner, and what to do when a plan fails. The terms
(waypoint, profile, pipeline, TCP) are defined in the glossary.
Choosing a planner
flowchart TD
    Q0{"Replanning every tick<br/>from the last solution?"}
    Q0 -->|yes| S["Low-level SQP<br/>TrajOpt-Ifopt"]
    Q0 -->|no| Q1{"Are the targets a dense<br/>Cartesian toolpath?"}
    Q1 -->|yes| D["plan_cartesian<br/>Descartes"]
    Q1 -->|no| Q2{"Must the path go<br/>around obstacles?"}
    Q2 -->|"yes, or unsure"| O["plan_ompl<br/>OMPL, then TrajOpt"]
Q2 -->|"no: the straight path<br/>is nearly right"| T["plan_freespace<br/>TrajOpt"]| Planner | Kind | Use for | What it guarantees |
|---|---|---|---|
| OMPL | sampling | free space among obstacles | probabilistically complete: finds a path if one exists, given enough time; nothing within a fixed time |
| TrajOpt | sequential convex optimization | smoothing, Cartesian paths, constraints | on success, a local (stationary) point of the costs with constraints holding to the solver tolerance at the evaluated points; a failed solve guarantees neither |
| TrajOpt-Ifopt | SQP with OSQP | replanning from a warm start | as TrajOpt: on success, a local (stationary) point of the costs with constraints holding to the solver tolerance at the evaluated points; a failed solve guarantees neither |
| Descartes | graph search over IK solutions | dense Cartesian toolpaths | the minimum-cost path through the sampled solutions: optimal for that discretization, not for the continuous problem |
| Simple | interpolation | seeds, joint moves | none; no collision checking |
On one freespace problem, measured:
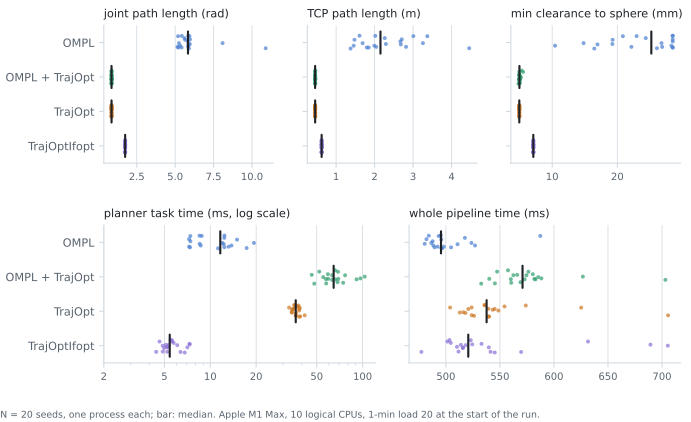
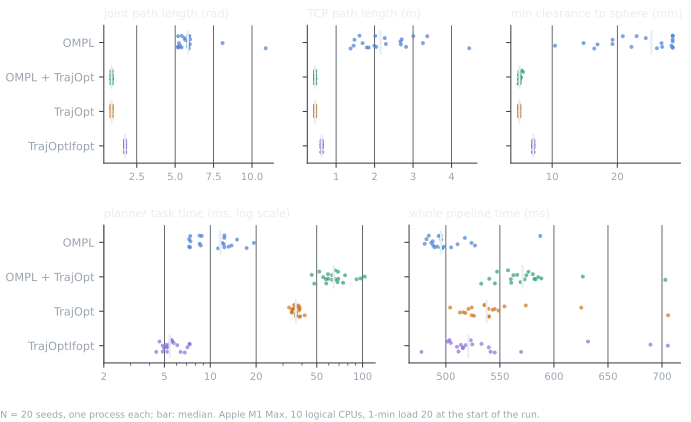
TaskComposer.warmup, OMPL with one planner thread; Apple M1 Max (10 logical CPUs), macOS 15.3.2, 1-min load 20 during the run (other work on the host: absolute times are pessimistic). Descartes is not compared: it follows Cartesian paths and has no joint-to-joint query. Data: docs/assets/figures/data/planner_comparison.json (hardware, OS, library build, git commit, seeds, raw rows). Re-measure: pixi run docs-figures-measure planner_comparison, then pixi run docs-figures planner_comparison.Plan with the high-level calls
All three calls take a Robot and a MotionProgram (or a CompositeInstruction) and return a
PlanningResult.
FreespacePipeline: parallel RRTConnect finds a path, TrajOpt smooths it, a discrete contact
check validates it and iterative spline parameterization times it.
import numpy as np
from tesseract_robotics.planning import (
    Robot, MotionProgram, JointTarget, plan_ompl,
)

locator = GeneralResourceLocator(paths=[get_tesseract_resource_path()])  # the tesseract-robotics-nanobind-support wheel
robot = Robot.from_tesseract_support("abb_irb2400", locator)
program = (
    MotionProgram("manipulator", tcp_frame="tool0", working_frame="base_link")
    .move_to(JointTarget(np.zeros(6)))
    .move_to(JointTarget(np.array([0.5, -0.5, 0.5, 0.0, 0.5, 0.0])))  # rad
)

result = plan_ompl(robot, program)
if result.successful:
    for state in result.trajectory:
        print(state.positions)
TrajOptPipeline: TrajOpt optimizes the program, then the same contact check and time
parameterization run. TrajOpt is a local method: use it when the
straight path is nearly collision-free.
DescartesDPipeline: Descartes searches the IK solutions of every Cartesian waypoint for the
cheapest joint path, then the contact check and time parameterization run. Use it when the
program is a sequence of CartesianTarget poses the tool must hit.
from tesseract_robotics.planning import CartesianTarget, Pose, plan_cartesian

cartesian_program = (
    MotionProgram("manipulator", tcp_frame="tool0", working_frame="base_link")
    # m in base_link, tool pointing down: [qx, qy, qz, qw] = [0, 1, 0, 0]
    .move_to(CartesianTarget(Pose.from_xyz_quat(0.8, -0.2, 0.5, 0.0, 1.0, 0.0, 0.0)))
    .linear_to(CartesianTarget(Pose.from_xyz_quat(0.8, 0.2, 0.5, 0.0, 1.0, 0.0, 0.0)))
)

result = plan_cartesian(robot, cartesian_program)
assert result.successful, result.message
| Call | Pipeline | Default profiles | Settings |
|---|---|---|---|
plan_ompl |
FreespacePipeline |
create_freespace_pipeline_profiles() |
OMPL, TrajOpt |
plan_freespace |
TrajOptPipeline |
create_trajopt_default_profiles() |
TrajOpt |
plan_cartesian |
DescartesDPipeline |
create_descartes_default_profiles() |
Descartes |
Every call takes pipeline= to run another pipeline (plan_ompl(..., pipeline="OMPLPipeline")
returns OMPL's path without the TrajOpt step), profiles= to replace the defaults, and
composer=. Without composer=, each call loads the task composer plugins again: hold one
TaskComposer and pass it to every call when you plan more than once
(Plugin warmup).
Trajectory output
if result.successful:
    print(f"Waypoints: {len(result.trajectory)}")
    first = result.trajectory[0]
    print(first.joint_names, first.positions, first.velocities, first.time)
    positions = result.to_numpy()  # (N, joints)
PlanningResult is truthy when successful. Its fields:
| Field | Content |
|---|---|
trajectory |
TrajectoryPoints: joint_names, positions (rad, or m for a prismatic joint), and velocities, accelerations, time (s from the start) where the pipeline time-parameterized the waypoint, else None |
message |
"Planning successful", or "<task>: <message>" for each task that failed |
raw_results |
the output CompositeInstruction, for the viewer, an emitter or a second plan |
task_infos |
one TaskComposerNodeInfo per node that ran (name, status_message, elapsed_time) |
data_storage |
the run's data storage, with each nested pipeline's own storage under its uuid |
The time stamps come from the pipeline's time parameterization task, which moves along the planned path as fast as the joint limits allow. The shipped pipelines run iterative spline parameterization; the figure shows TOTG:
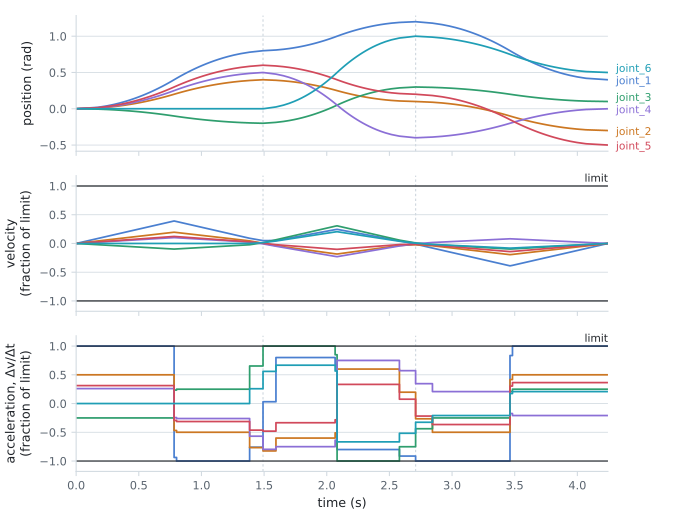
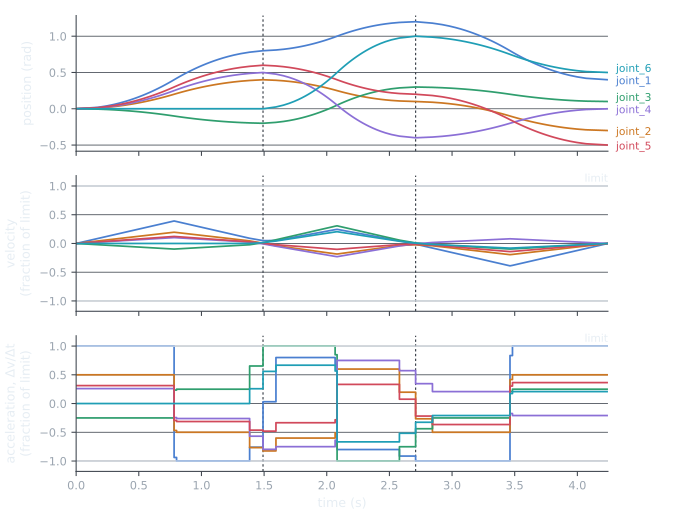
TimeOptimalTrajectoryGeneration with the default composite profile. Velocity and acceleration are fractions of each joint's limit; acceleration is the change of TOTG's waypoint velocities over each interval (Δv/Δt). Reproduce: pixi run docs-figures time_parameterization.Motion types
Each builder method of MotionProgram adds a move of one type to a target:
| Method | Move type | The TCP between waypoints |
|---|---|---|
move_to(target) |
FREESPACE |
any collision-free path |
linear_to(target) |
LINEAR |
a straight line in the working frame |
circular_to(target) |
CIRCULAR |
an arc |
from tesseract_robotics.planning import CartesianTarget

moves = (
    MotionProgram("manipulator", tcp_frame="tool0", working_frame="base_link")
    .move_to(JointTarget(joint_values))
    .move_to(CartesianTarget(pose))  # freespace to a pose
    .linear_to(CartesianTarget(pose))
)
A target is a JointTarget, a StateTarget or a CartesianTarget, and may name a profile;
without one it takes the program's. A raster combines the move types: a freespace approach, then
linear strokes joined by linear step-overs.
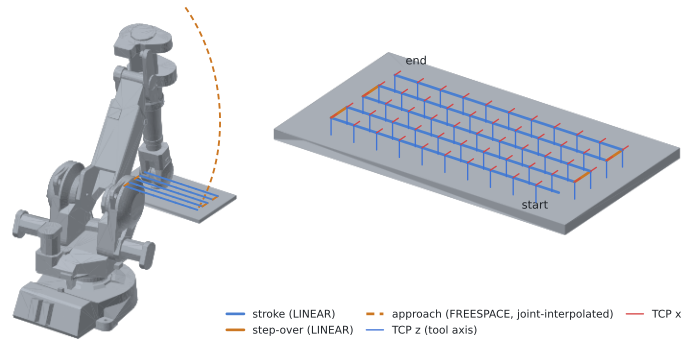
CartesianPipeline (Descartes, then TrajOpt): five 50 cm strokes 5 cm apart, 35 cm above base_link, tool down, joined by linear step-overs, after a freespace approach from home. Path and glyphs are forward kinematics of the planned joint states: blue strokes, orange step-overs, the dashed approach is the TCP under joint-space interpolation (not a straight line). Glyphs: TCP z (tool axis, blue) and x (red) at every planned state; the strokes stay on the plane to within 1 mm. Reproduce: pixi run docs-figures raster_toolpath.MotionProgram builds a CompositeInstruction of MoveInstructions; the planning calls accept
either. The command_language reference shows the instruction
types.
Frames and the TCP
A MotionProgram names its tcp_frame and working_frame, and optionally a tcp_offset; the
planner puts tcp_frame · tcp_offset on each Cartesian target, expressed in working_frame.
Frames and poses defines each frame with a figure and a worked check;
TCP offsets has the lookup rule of a named offset.
Robot.fk and Robot.ik take a link, not a named TCP: apply or strip the offset yourself (see
Tool frames).
Standard toolpaths
tesseract_robotics.planning.toolpaths has fixed, parametric toolpaths, so a new solver,
constraint or emitter is judged on the same path every time (#84). Each factory returns a
list[Pose] in the working frame; profiles and move types stay with the caller.
| Factory | Shape | Poses | Used by |
|---|---|---|---|
zigzag_square() |
0.8 m × 0.8 m square outline (x 0.6 to 1.4 m, y −0.4 to 0.4 m, z = 0.4 m), then 11 zigzag lines at 0.08 m spacing, tool down | OUTLINE_POSE_COUNT + 2 * ZIGZAG_LINE_COUNT = 27 |
the RAPID golden test (tests/emitters/rapid/test_zigzag_square.py) |
circle(radius_m, n_waypoints, center=, z_m=) |
horizontal circle, tool down, evenly spaced, counter-clockwise from +X, start not repeated |
n_waypoints (≥ 3) |
the Descartes pool measurements of #140 (84 to 419 waypoints on the IRB 2400) |
from tesseract_robotics.planning import CartesianTarget, MotionProgram
from tesseract_robotics.planning.toolpaths import OUTLINE_POSE_COUNT, circle, zigzag_square

raster = MotionProgram("manipulator", tcp_frame="tool0", working_frame="base_link")
for i, pose in enumerate(zigzag_square()):
    raster.linear_to(CartesianTarget(pose, profile="OUTLINE" if i < OUTLINE_POSE_COUNT else "RASTER"))

contour = circle(0.25, 210, center=(0.8, 0.0), z_m=0.6)  # m
Every zigzag pose has ZIGZAG_QUAT_XYZW = (0, 1, 0, 0): 180° about the working frame's y axis,
so the TCP z axis points along −z, into the workpiece. The IRB 2400 reaches every pose of the
default placement tool down. tests/conftest.py serves the zigzag square as the
zigzag_square_poses fixture.
OMPL
OMPL samples joint space for a collision-free path. plan_ompl runs it in FreespacePipeline,
with create_freespace_pipeline_profiles (the OMPL settings below plus the
TrajOpt defaults for the smoothing step); create_ompl_default_profiles takes the
same OMPL arguments for OMPLPipeline.
| Argument | Default | Effect |
|---|---|---|
planning_time |
10 s | wall-clock budget of all planners together |
num_planners |
min(4, CPU count) |
parallel RRTConnect planners |
optimize |
True |
keep solving until the budget, max_solutions or the objective ends the loop; False returns the first path |
max_solutions |
10 | solutions after which the loop ends |
planner_range |
0: OMPL's estimate from the joint ranges | longest RRTConnect extension step, rad of joint-space norm |
simplify (create_ompl_default_profiles only) |
False |
simplify the path after planning |
A state closer than 10 mm to an obstacle is invalid (OMPL_CONTACT_MARGIN_M). Any argument out
of range raises InvalidProfileArgumentError.
from tesseract_robotics.planning import TaskComposer, plan_ompl
from tesseract_robotics.planning.profiles import create_freespace_pipeline_profiles

composer = TaskComposer.from_config()
profiles = create_freespace_pipeline_profiles(planning_time=5.0, num_planners=2, optimize=False)
result = plan_ompl(robot, program, profiles=profiles, composer=composer)
assert result.successful, result.message
create_ompl_planner_configurators(planners=[...], num_planners=n, **fields) builds the
planner list of a profile from any OMPLPlannerType: SBL, EST, LBKPIECE1, BKPIECE1,
KPIECE1, BiTRRT, RRT, RRTConnect, RRTstar, TRRT, PRM, PRMstar, LazyPRMstar,
SPARS; the OMPL reference shows it on a profile.
OMPL optimization objectives
With optimize = True, the OMPL planner re-solves until planning_time runs out,
max_solutions solutions exist, or the objective calls the best path good enough
(objective.isSatisfied(cost)). The default objective is joint-space path length with no
threshold, so the loop ends on time or count. A Python subclass of OMPLRealVectorMoveProfile
can supply its own objective by overriding createOptimizationObjective(si, env, manip); the
planner calls it once per solve, and a cost threshold on the returned objective ends the loop as
soon as a path meets it (#362).
from tesseract_robotics.motion_planners_ompl import (
    Cost,
    MaximizeMinClearanceObjective,
    MultiOptimizationObjective,
    OMPLRealVectorMoveProfile,
    PathLengthOptimizationObjective,
)


class LengthAndClearance(OMPLRealVectorMoveProfile):
    def createOptimizationObjective(self, si, env, manip):
        objective = MultiOptimizationObjective(si)
        objective.addObjective(PathLengthOptimizationObjective(si), 1.0)
        objective.addObjective(MaximizeMinClearanceObjective(si), 0.5)
        objective.setCostThreshold(Cost(6.0))  # rad of joint-space path length
        return objective
Register the instance under OMPL_DEFAULT_NAMESPACE like any OMPL profile.
| Type | Role |
|---|---|
SpaceInformation |
the problem's OMPL space information; opaque, the objectives are built on it |
Cost |
a cost value: Cost(2.0), .value() |
OptimizationObjective |
base: isSatisfied, setCostThreshold, getCostThreshold, getDescription |
PathLengthOptimizationObjective |
joint-space path length, the default |
MaximizeMinClearanceObjective |
maximise the smallest clearance along the path |
MechanicalWorkOptimizationObjective |
mechanical work, plus a small path-length term |
MultiOptimizationObjective |
weighted sum: addObjective(objective, weight) |
StateCostIntegralObjective |
integral of a per-state cost; subclass it to price states in Python |
The override may return None for no objective; anything else that is not an
OptimizationObjective raises OMPLObjectiveReturnTypeError from solve, and a Python error
raised in it propagates from solve as itself. Of the objectives, only
StateCostIntegralObjective can be subclassed in Python.
A threshold that the first path meets ends the loop at that path. On
freespace_clearance_objective_example.py, a 4.0 rad threshold ended OMPL in 0.04 to 0.07 s
against 10.81 to 11.98 s for the default objective at planning_time = 10
(evidence and per-seed table); on the sphere sweep of
freespace_hybrid_example.py, tests/tesseract_motion_planners/test_ompl_objective.py asserts
that an infinite threshold returns in under 2 s at planning_time = 10.0.
Clearance is not reported on this stack
tesseract's OMPL state validators do not implement clearance(), so OMPL's default,
0, applies to every state and MaximizeMinClearanceObjective adds a constant. A
clearance-weighted objective therefore optimizes path length alone.
A per-state cost in Python
StateCostIntegralObjective prices each state with stateCost and integrates the cost along
each motion: the mean of the two end states' costs times the motion's length, or the sum over
validSegmentCount sub-motions with enable_motion_cost_interpolation=True. Without an override
every state costs 1, so the integral is path length. Override stateCost(self, values) -> float
to price states in Python; values is a copy of the state's joint positions (rad, or m for a
prismatic joint, in the group's joint order). Since the validators report no clearance, this is
the way to price clearance.
from tesseract_robotics.motion_planners_ompl import (
    Cost,
    OMPLRealVectorMoveProfile,
    StateCostIntegralObjective,
)


class AvoidJointA1Extremes(StateCostIntegralObjective):
    def stateCost(self, values):
        return 1.0 + values[0] ** 2  # values[0]: joint_a1 (rad)


class Profile(OMPLRealVectorMoveProfile):
    def createOptimizationObjective(self, si, env, manip):
        objective = AvoidJointA1Extremes(si)
        objective.setCostThreshold(Cost(6.0))
        return objective
Only the optimize loop prices paths: with optimize = False the planner builds no objective,
so stateCost is never called.
| Raised | When |
|---|---|
OMPLStateCostError (a TypeError), from solve |
stateCost returned something other than a float (a numpy float qualifies) |
OMPLStateSpaceTypeError (a TypeError), building the subclass |
the planning space is not a RealVectorStateSpace |
the override's own exception, from solve |
stateCost raised on the thread that called solve (see the warning below) |
scripts/bench_state_cost.py measures what the Python calls cost: one RRTConnect planner on
seed 1 on the sphere sweep, an infinite cost threshold so the loop prices the first path once,
motion-cost interpolation on, a C++ arm against a Python stateCost arm, each in its own
processes. Run it on your machine; the figures depend on the hardware and the scene.
Each call takes the GIL
solve releases the GIL and every stateCost call takes it back. Parallel planners
that price states serialise on the GIL while they do, and a slow stateCost slows
every planner thread.
Optimizing planners: a raising stateCost aborts the process
RRTConnect never prices states itself. tesseract's optimize loop does, on the thread
that called solve, so a Python error reaches the caller. An optimizing planner such
as RRT* prices states inside its own solve, on an OMPL ParallelPlan worker thread,
and an exception there ends the process (std::terminate). Use a Python stateCost
with RRTConnect, or make sure it cannot raise.
TrajOpt
TrajOpt optimizes the whole trajectory by sequential convex optimization: it linearizes the
costs and constraints around the current trajectory, solves a QP inside a trust region, and
repeats until it converges. It finds a local optimum near its seed. Two profiles configure it,
both in the TrajOptMotionPlannerTask namespace: the move profile
(TrajOptDefaultMoveProfile, per waypoint: how a target is held) and the composite profile
(TrajOptDefaultCompositeProfile, over the trajectory: collision and smoothing).
create_trajopt_default_profiles() sets them from the C++ examples:
| Setting | Default profiles |
|---|---|
| Joint and Cartesian targets | constraints (joint_constraint_config, cartesian_constraint_config); the cost forms are off |
| Collision constraint | margin 0 m, buffer 5 mm, coefficient 10 |
| Collision cost | margin 5 mm, buffer 10 mm, coefficient 50 |
| Collision evaluator | LVS_CONTINUOUS, longest_valid_segment_length 0.1 (joint-space norm) |
| Smoothing | smooth_velocities, smooth_accelerations and smooth_jerks stay at the C++ default (True); the Ifopt helper, create_trajopt_ifopt_default_profiles, sets all three to False |
from tesseract_robotics.planning.profiles import create_trajopt_profile_pair

composite, move = create_trajopt_profile_pair()
composite.collision_cost_config.contact_manager_config.default_margin = 0.025  # m
Collision configuration
The margin is the clearance a collision term drives toward; it lives in
contact_manager_config.default_margin, which TrajOptCollisionConfig's first argument sets.
collision_margin_buffer only widens the distance within which contacts are collected and adds
no error, so it cannot stand in for the margin. Distance, margin and
penetration shows what a check reports inside and
outside the margin.
from tesseract_robotics.trajopt_ifopt import TrajOptCollisionConfig
from tesseract_robotics.collision import CollisionEvaluatorType

collision_config = TrajOptCollisionConfig(0.025, 20.0)  # margin (m), coefficient
collision_config.collision_margin_buffer = 0.005  # m: collect contacts 5 mm past the margin
collision_config.collision_check_config.type = CollisionEvaluatorType.LVS_DISCRETE
collision_config.collision_check_config.longest_valid_segment_length = 0.05  # LVS step
TrajOptCollisionConfig lives in trajopt_ifopt and is shared by both TrajOpt planners. A
default-constructed config has no margin (default_margin is None): the term then engages
only at contact, TrajOpt settles paths on the obstacle's surface, and the pipeline's contact
check can reject them. DISCRETE checks the waypoints only, so a thin obstacle can sit between
two collision-free waypoints; the LVS and CONTINUOUS evaluators check the motion between them
(Discrete, continuous and LVS checks).
Costs vs constraints (soft vs hard)
| Kind | The solver | Use for |
|---|---|---|
| Cost | minimises its weighted error; it may stay nonzero | preferences: clearance beyond the minimum, smoothness, a preferred pose |
| Constraint | drives its error to zero at the evaluated points, raising its penalty until it does or the solve stops | requirements: a target pose, a minimum clearance, an orientation |
The default profiles use both for collision: a cost with a 5 mm margin pushes the path clear, and a constraint at 0 m forbids penetration at the checked states. Without the cost, TrajOpt converged onto the zero-distance boundary and the pipeline's contact check rejected the path whenever the solver's residual came out negative (#103).
from tesseract_robotics.collision import CollisionEvaluatorType
from tesseract_robotics.motion_planners_trajopt import (
    TrajOptDefaultCompositeProfile,
    TrajOptDefaultMoveProfile,
)

composite = TrajOptDefaultCompositeProfile()
composite.collision_cost_config.enabled = True
composite.collision_cost_config.contact_manager_config.default_margin = 0.025  # m
composite.collision_cost_config.collision_coeff_data.setDefaultCollisionCoeff(20.0)
composite.collision_cost_config.collision_check_config.type = CollisionEvaluatorType.DISCRETE
composite.collision_constraint_config.enabled = True
composite.collision_constraint_config.contact_manager_config.default_margin = 0.01  # m
composite.collision_constraint_config.collision_check_config.type = CollisionEvaluatorType.DISCRETE

move = TrajOptDefaultMoveProfile()
move.cartesian_cost_config.enabled = True  # try to reach the pose ...
move.cartesian_cost_config.coeff = [10, 10, 10, 5, 5, 5]  # x, y, z, rx, ry, rz
move.cartesian_constraint_config.enabled = False  # ... instead of having to
A coeff weights each axis' error, [x, y, z, rx, ry, rz] for a Cartesian term and one per
joint for a joint term; a zero frees that axis. Start with costs, check the solution, and add
constraints one at a time: a set of constraints with no common solution ends the solve at
OPT_PENALTY_ITERATION_LIMIT.
Orientation and joint constraints
The UPRIGHT profile holds the tool's orientation and leaves its position free (Cartesian
constraint coeff = [0, 0, 0, 1, 1, 1], as the C++ glass upright example); a program uses it by
naming it:
from tesseract_robotics.planning import StateTarget, plan_freespace
from tesseract_robotics.planning.profiles import create_trajopt_upright_profiles

names = robot.get_joint_names("manipulator")
upright = (
    MotionProgram("manipulator", tcp_frame="tool0", working_frame="base_link", profile="UPRIGHT")
    .set_joint_names(names)
    .linear_to(StateTarget(np.zeros(6), names=names))
    .linear_to(StateTarget(np.array([0.4, 0.0, 0.0, 0.0, 0.0, 0.0]), names=names))  # rad
)
result = plan_freespace(robot, upright, profiles=create_trajopt_upright_profiles(), composer=composer)
assert result.successful, result.message
A joint term weights joints the same way. joint_cost_config is disabled by default and the joint
constraint is the default, so enable the cost and set the weights:
The first joint's deviation from a joint target now weighs a hundred times that of the others. The glass upright example runs the full scene.
Descartes
Descartes samples the IK solutions of every Cartesian waypoint, links the solutions of
consecutive waypoints into a ladder graph, and returns the cheapest path through it (joint-space
distance by default). It follows the poses exactly or fails; it does not smooth. Use it for dense
toolpaths (welding, painting, machining), alone (plan_cartesian) or as the seed of TrajOpt
(CartesianPipeline, the raster pipelines).
create_descartes_default_profiles argument |
Default | Effect |
|---|---|---|
enable_collision |
on | reject waypoint solutions in collision |
enable_edge_collision |
off | also check the motion between solutions; slower |
num_threads |
CPU count | threads of the ladder-graph solver |
sample_axis, sample_resolution, sample_min, sample_max |
target fixed; once one is set, the library's −π to π/2 in π/2 steps | sample the target's rotation about a tool axis (rad), for axis-symmetric tools; set sample_max with the resolution |
ik_solver |
the group's | IK solver used for sampling, such as "OPWInvKin" |
use_redundant_joint_solutions |
off | also sample joint-redundant solutions (wrist flips) |
move_profile |
none | a whole DescartesDefaultMoveProfileD / F; excludes the arguments above |
from tesseract_robotics.planning.profiles import create_descartes_default_profiles

profiles = create_descartes_default_profiles(
    enable_collision=True,
    enable_edge_collision=False,
    num_threads=1,
)
result = plan_cartesian(robot, cartesian_program, profiles=profiles, composer=composer)
assert result.successful, result.message
Two scalar types
plan_cartesian's DescartesDPipeline runs Descartes on double states and reads the D
profiles; CartesianPipeline, DescartesFPipeline and every raster pipeline run it on
float states and read the F ones. The helpers register both, and TaskComposer.plan
raises ProfileTypeMismatchError if a pipeline would find only the other type (see the
Descartes API page).
Custom edge and state evaluators in Python
To change which IK branch Descartes picks (penalise wrist flips, weight joints, score edges with an external signal), subclass the evaluator interfaces in Python:
| Class | Override | When it runs |
|---|---|---|
DescartesWaypointSamplerD |
sample() -> list[DescartesStateSampleD] |
generating IK candidates for a waypoint |
DescartesEdgeEvaluatorD |
evaluate(start, end) -> (valid, cost) |
an edge between two graph states |
DescartesStateEvaluatorD |
evaluate(state) -> (valid, cost) |
a per-state cost |
Each has an F twin (DescartesEdgeEvaluatorF, …) on float32 states; use the type of the
pipeline you plan with. start and end are DescartesStateD objects whose .values is a 1-D
numpy array of joint positions in the group's order. A subclass of DescartesMoveProfileD
returns your objects from its three factory methods and delegates the others to a
DescartesDefaultMoveProfileD:
import numpy as np
from tesseract_robotics.motion_planners_descartes import (
    DescartesDefaultMoveProfileD,
    DescartesEdgeEvaluatorD,
    DescartesMoveProfileD,
)

class WristFlipPenaltyEvaluator(DescartesEdgeEvaluatorD):
    """Cost = L2 joint delta; reject a wrist swing over 90 degrees."""

    def evaluate(self, start, end):
        delta = end.values - start.values
        cost = float(np.linalg.norm(delta))
        if abs(delta[-1]) > np.pi / 2:   # wrist joint flip
            return (False, cost)         # reject this edge
        return (True, cost)


class MyMoveProfile(DescartesMoveProfileD):
    def __init__(self):
        super().__init__()
        self._inner = DescartesDefaultMoveProfileD()
        # One evaluator instance for every edge evaluation
        self._edge_evaluator = WristFlipPenaltyEvaluator()

    def createWaypointSampler(self, move_instruction, composite_manip_info, env):
        return self._inner.createWaypointSampler(move_instruction, composite_manip_info, env)

    def createEdgeEvaluator(self, move_instruction, composite_manip_info, env):
        return self._edge_evaluator

    def createStateEvaluator(self, move_instruction, composite_manip_info, env):
        return self._inner.createStateEvaluator(move_instruction, composite_manip_info, env)
Register it in a ProfileDictionary yourself, under the namespace and the profile name the
instructions carry; create_descartes_default_profiles(move_profile=...) refuses a subclass,
because its hooks have no twin of the other scalar type.
from tesseract_robotics.command_language import ProfileDictionary

profiles = ProfileDictionary()
profiles.addProfile("DescartesMotionPlannerTask", "MY_PROFILE", MyMoveProfile())
An edge evaluator is also how to keep one IK branch across a raster program: the raster pipeline does not backtrack when a later transition fails, so the branch has to be chosen during the Descartes search.
Threading and the GIL
Each call into Python takes the GIL, so with num_threads > 1 the Python evaluators run
one at a time; only the C++ IK sampling runs in parallel. Keep evaluate small (numpy
operations, no allocations). On macOS a wheel installed into a conda or pixi environment
brings a second OpenMP runtime, and the ladder solver segfaults above one thread
(macOS wheel gotchas).
Setup cost with vertex collision
With vertex collision on, a Descartes solve is dominated by setup, not search. Building each
waypoint's sampler constructs a DescartesCollision, which clones the environment's Bullet
contact manager, and a Bullet clone rebuilds and zero-fills its pool allocators. A sample
profile of DescartesMotionPlannerD.solve on a 419-waypoint contour (abb_irb2400, redundant
solutions on) puts about 97 % of the solve there, serially on the calling thread, before the
parallel ladder build starts. Source: #140 (0.35.0.7, macOS arm64; the issue does not record
the chip):
| Vertex collision | Threads | Wall | CPU / wall |
|---|---|---|---|
| on | 1 | 435.4 ms | 1.00 |
| on | 8 | 432.3 ms | 1.02 |
| off | 1 | 2.7 ms | 1.00 |
| off | 8 | 1.9 ms | 1.78 |
So num_threads changes nothing measurable while vertex collision is on. Turning vertex
collision off needs allow_collision = True as well, or the planner refuses for want of a
checker, and collisions must then be checked elsewhere, such as by the pipeline's
DiscreteContactCheckTask.
Smaller Bullet pools cut the clone cost. They are sized by default for a physics world (4096 persistent manifolds, 4096 collision algorithms; about 7 MiB per clone), and the Bullet plugins read both sizes from the contact-manager plugin YAML your SRDF points to:
contact_manager_plugins:
  discrete_plugins:
    default: BulletDiscreteBVHManager
    plugins:
      BulletDiscreteBVHManager:
        class: BulletDiscreteBVHManagerFactory
        config:
          max_persistent_manifold_pool_size: 16
          max_collision_algorithm_pool_size: 16
Pool size is capacity, not semantics: the contacts are the same
(tests/tesseract_collision/test_bullet_pool_config.py). Measured in
#140 (0.35.0.7, macOS arm64; the issue does not record the chip):
| Scene | Planner | Default pools (4096/4096) | 16/16 pools | Output |
|---|---|---|---|---|
| free space, 419 wp | Descartes | 413 ms, +2922 MiB peak RSS | 17.8 ms, +30 MiB | identical joints |
docs/assets/sample.ply octree (333 boxes), tool 5 cm above, 210 wp |
Descartes | 247 ms | 43 ms | identical joints |
| same scan at 1 cm (4021 boxes), edge collision on | Descartes | 6.6 s | 5.6 s | identical joints |
| BasicCartesianExample, C++ example's octomap | TrajOpt | 60 ms, +404 MiB | 38 ms, +8 MiB | both plan |
The per-waypoint clones are upstream's: TrajOpt's are trajopt#625 (fix in tesseract_planning#789); Descartes's have no upstream issue yet.
When a plan fails
A planner that ran and found no solution returns successful=False, and result.message names
the task that failed, "<task>: <message>". A configuration error (an unknown pipeline, profiles
of the wrong type, an empty program) raises instead; the
task composer page lists those. The messages below were
recorded on the IRB2400:
result.message |
Cause | Fix |
|---|---|---|
DescartesMotionPlannerTask: Failed to build graph |
a Cartesian waypoint has no valid IK solution: out of reach, every solution in collision, or no edge to the next waypoint | check the pose and the TCP (Frames and the TCP); sample the tool axis (sample_axis) |
TrajOptMotionPlannerTask: Failed to find valid solution: OPT_PENALTY_ITERATION_LIMIT |
the constraints cannot all hold near the seed: a target out of reach or in collision, or an obstacle the straight seed cannot be pushed around | check the targets; plan around obstacles with plan_ompl |
OMPLMotionPlannerTask: Failed to find valid solution: Exceeded allowed time |
no path within planning_time, or the start or goal is in collision (the log then reads Goal state is in collision with the link pair) |
check the start and goal states; raise planning_time |
DiscreteContactCheckTask: Contact(s) found:, a Format: header, then one line per contact, Step <n>: [link_a, link_b] @ <distance m> (negative is penetration) |
the planned path is within the contact check's margin at the listed step | widen TrajOpt's collision cost margin; check the motion between waypoints with an LVS evaluator |
Check the start and goal states for contacts before you change planners:
from tesseract_robotics.collision import CollisionCheckConfig, CollisionEvaluatorType
from tesseract_robotics.environment import checkTrajectory

endpoints = np.array([np.zeros(6), np.full(6, 0.2)])  # start and goal, rad

config = CollisionCheckConfig()
config.type = CollisionEvaluatorType.DISCRETE
manager = robot.env.getDiscreteContactManager()
results, contacts = checkTrajectory(manager, robot.env.getJointGroup("manipulator"), endpoints, config)
print(results.condensedSummary() if results else "start and goal are collision-free")
result.task_infos holds every node that ran, with its status_message and elapsed_time;
the annotated pipeline graph shows which node
stopped the run.
Next steps
- Task composer: pipelines, profiles, custom graphs.
- Low-level SQP: build and step the optimization problem yourself.
- Planning examples: runnable scenes for each planner.