Examples
Every example is a script that runs on its own: installed as a console script, importable as a module, and tested in CI. The recorded ones play in the browser on their page: click a poster, then orbit, scrub and change the playback speed, with nothing installed.
tesseract_car_seat_example                              # an installed console script
python -m tesseract_robotics.examples.car_seat_example  # the same, as a module
Run as a script, an example plans, opens the viewer and prints its URL.
Its run() function plans without the viewer and returns the results; the tests call that. A
plan that fails raises PlanningFailedError or TimeParameterizationFailedError
(tesseract_robotics.examples.failures) and the script exits non-zero.
Planning
Cartesian toolpaths, orientation constraints, attach-and-place and multi-step programs.
-
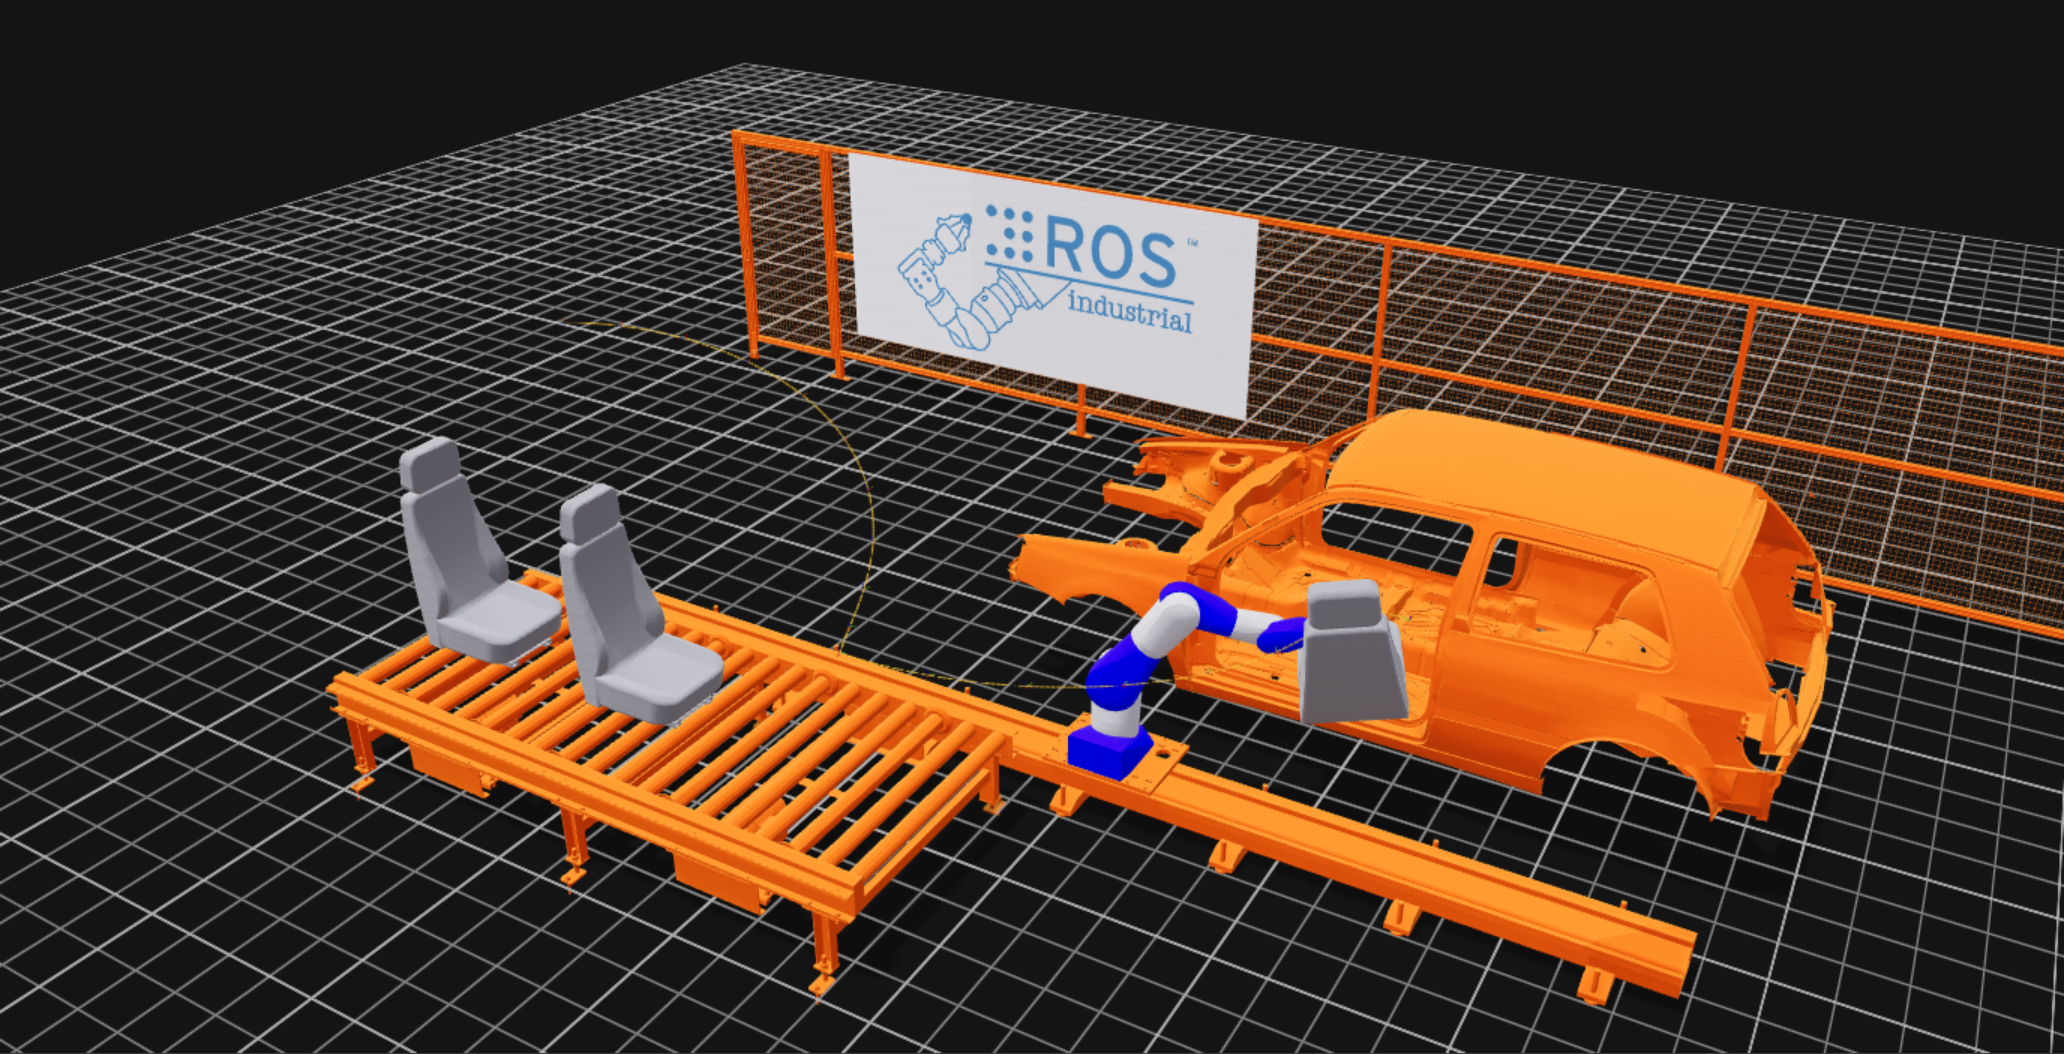
Picks a seat off a conveyor and places it through a car's door opening, on a rail-mounted robot.
tesseract_car_seat_example -
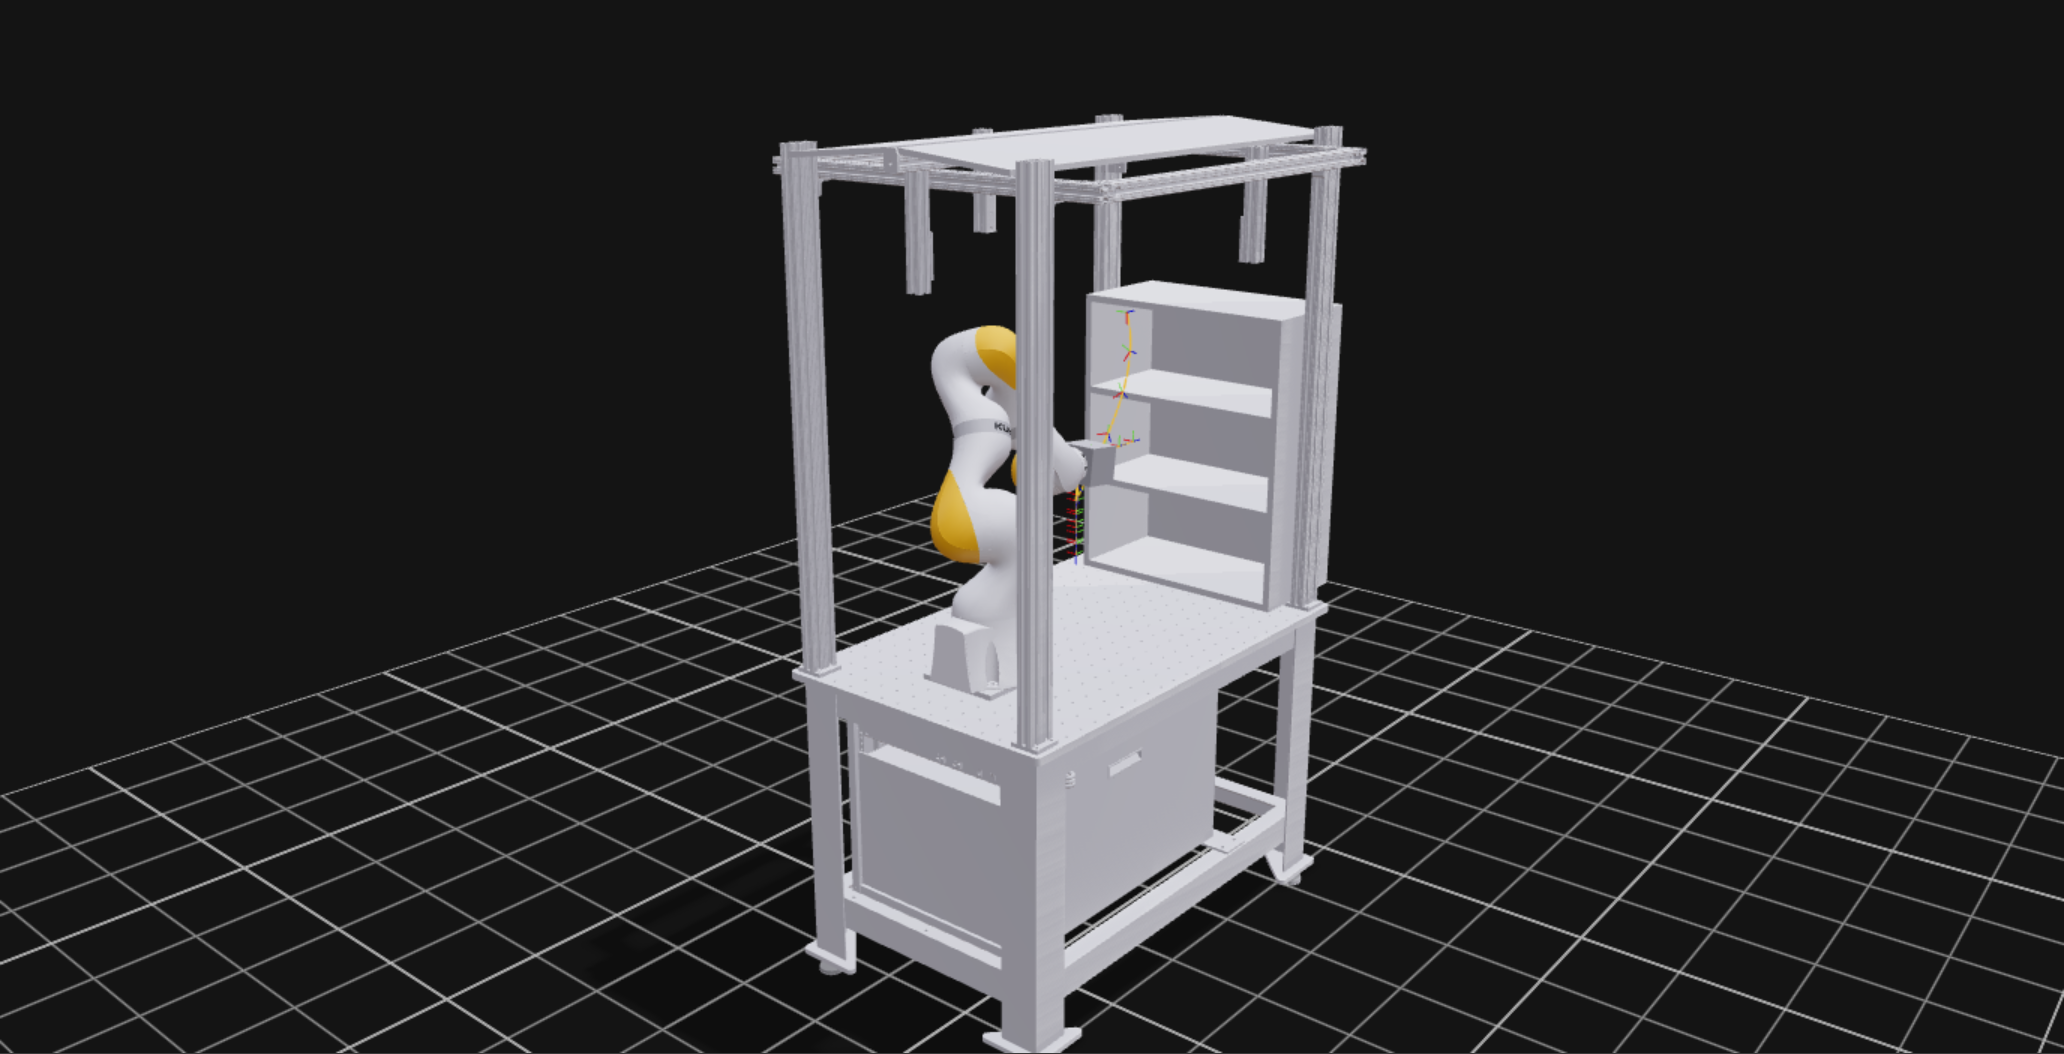
Picks a box, attaches it to the tool and places it on a shelf.
tesseract_pick_and_place_example -
An industrial raster pattern, as used for welding or milling.
tesseract_raster_example -
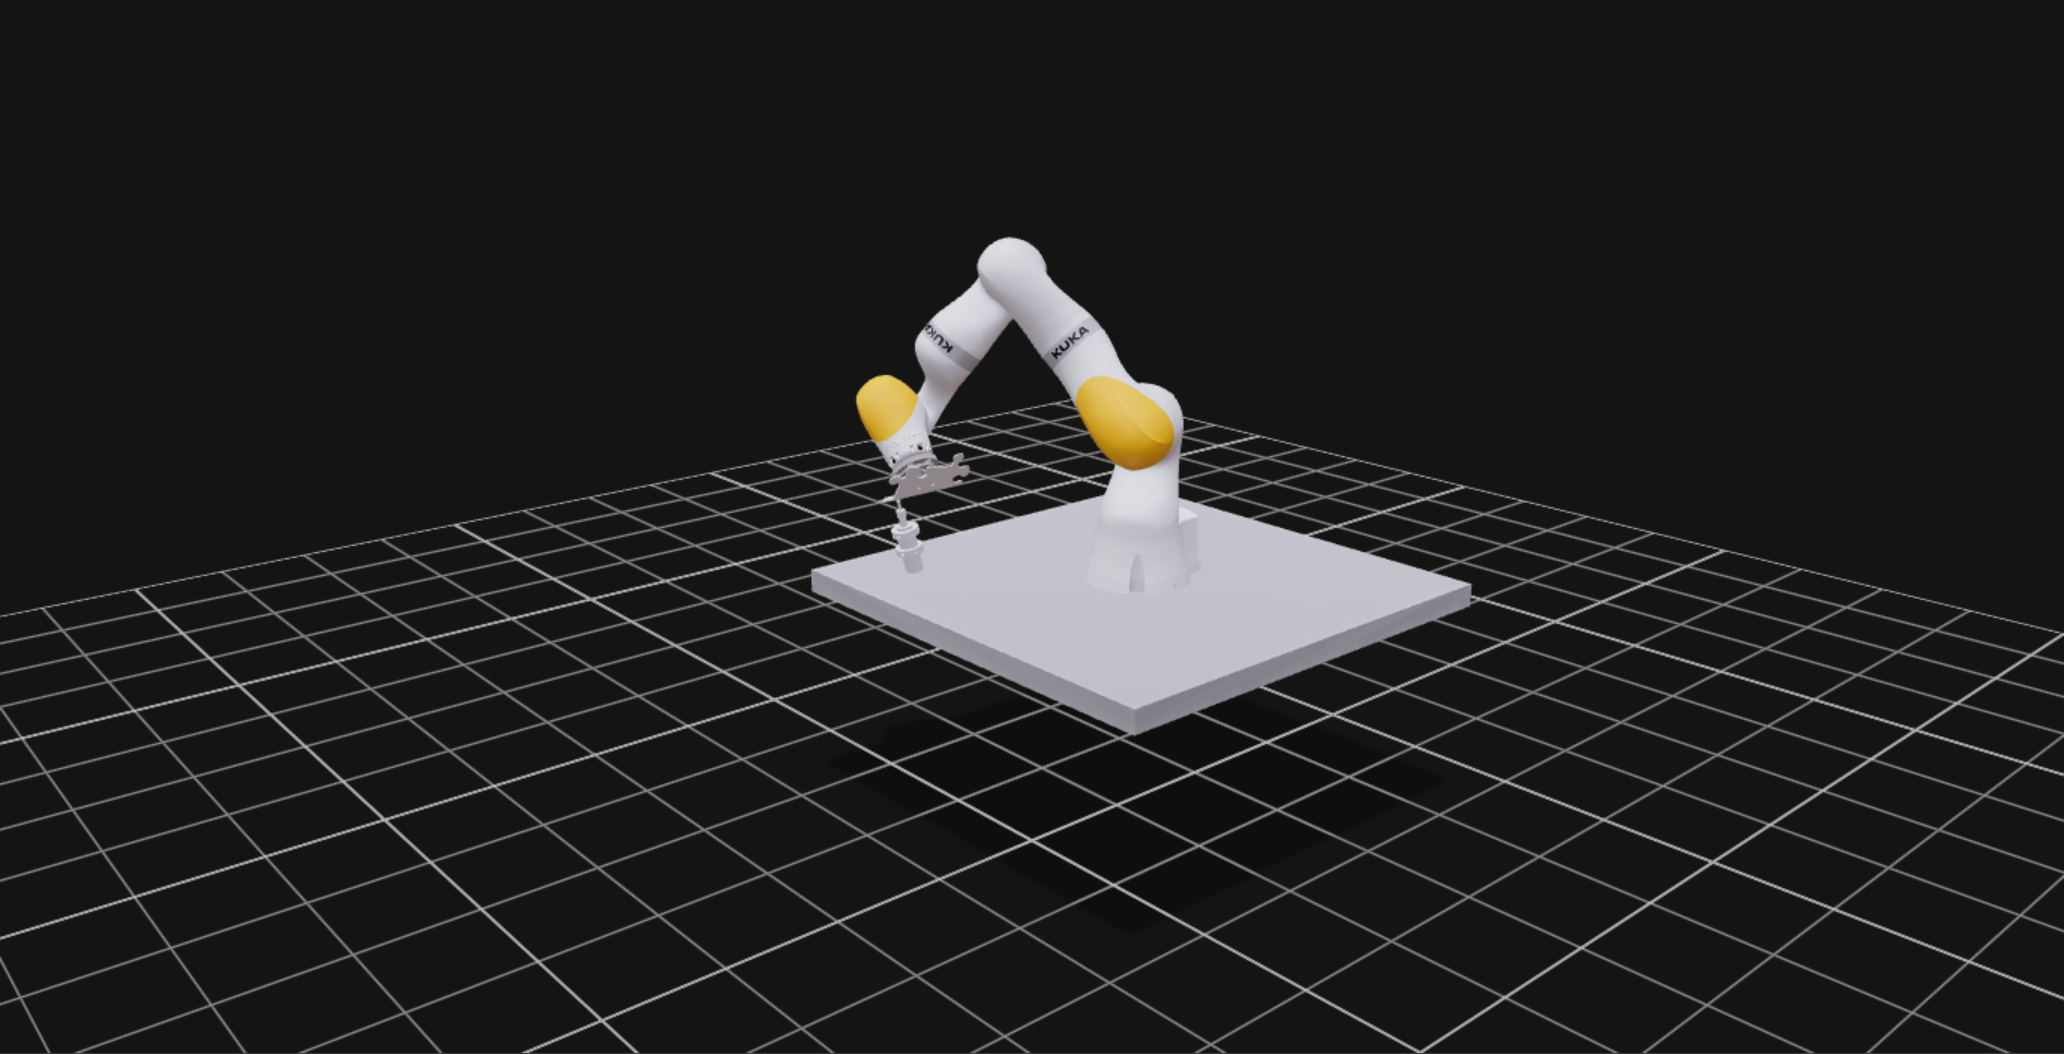
A 9-DOF Cartesian toolpath: a robot and two auxiliary axes grind a part's edge.
tesseract_puzzle_piece_auxillary_axes_example -
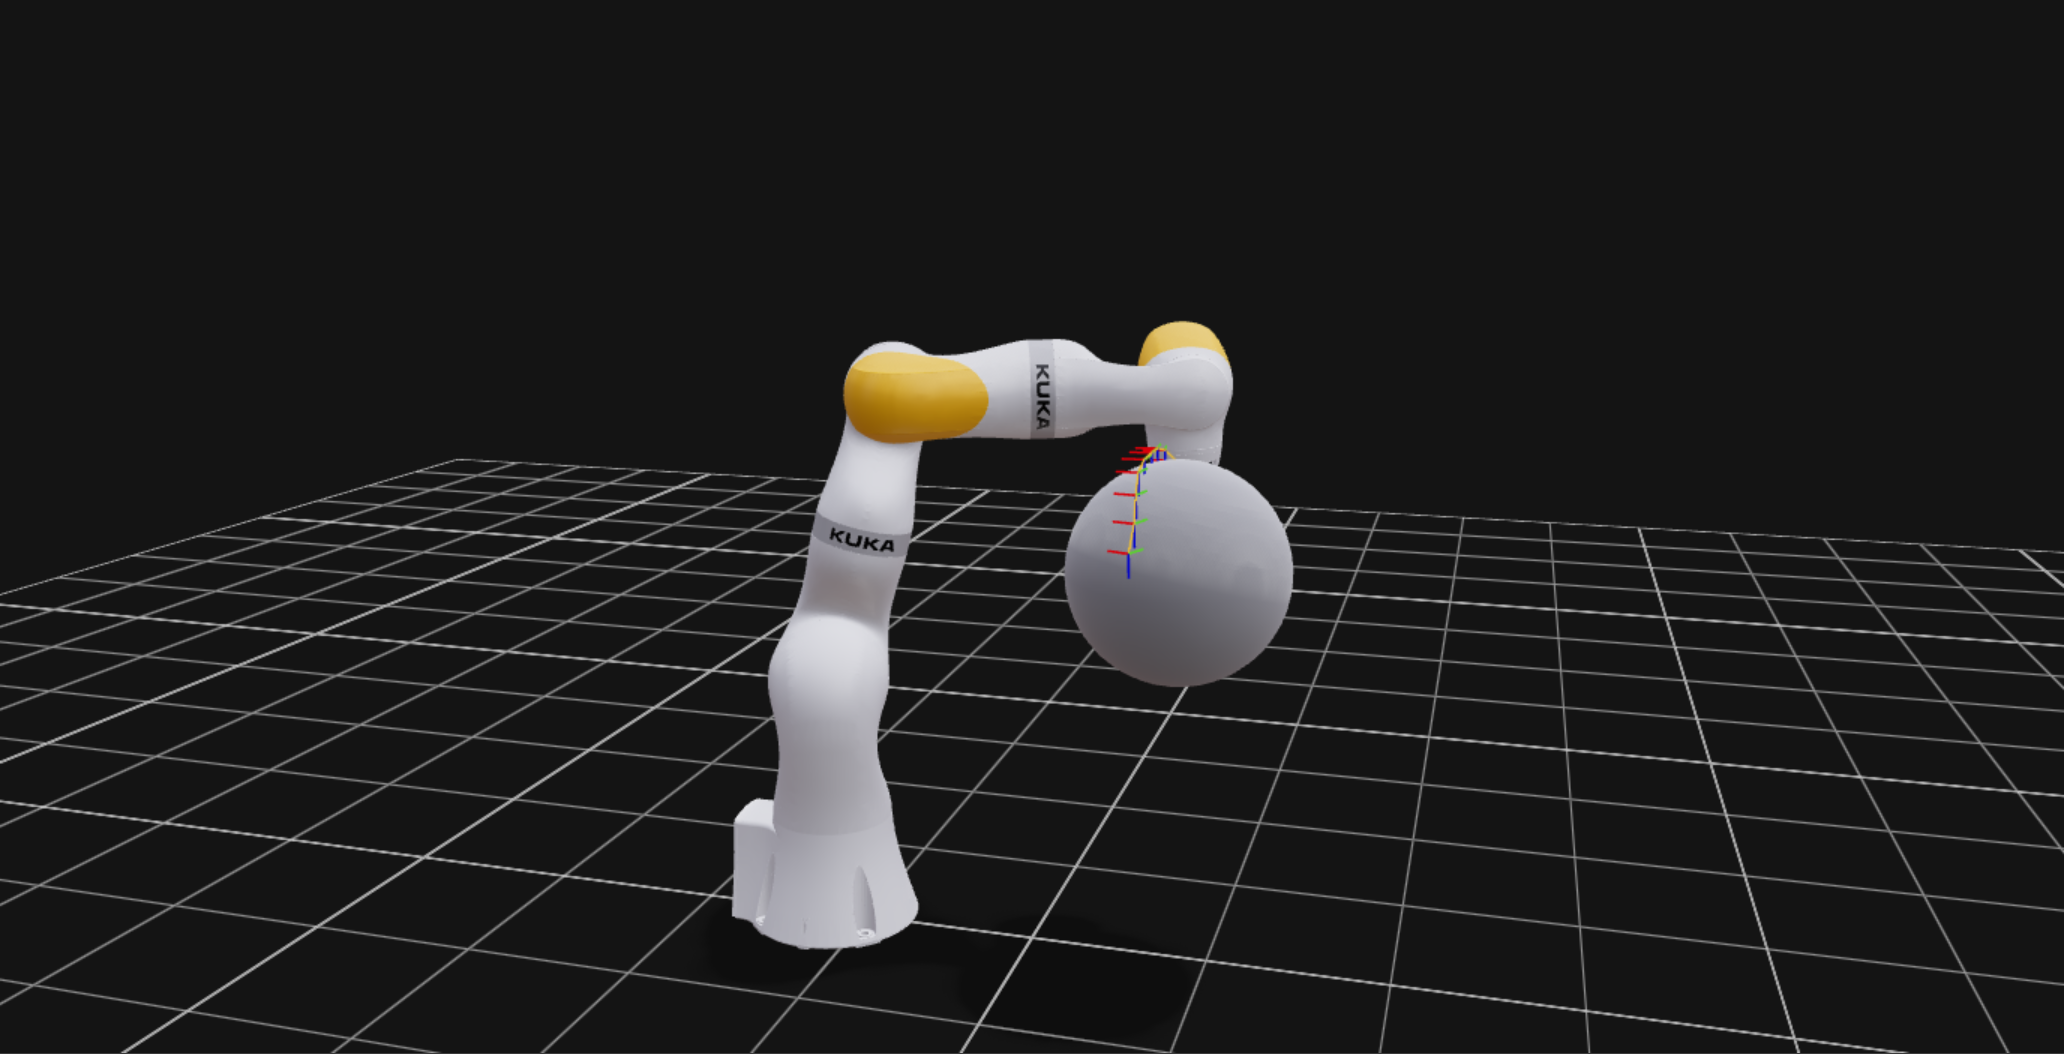
A raster planned with Descartes and refined with TrajOpt.
tesseract_chain_example -
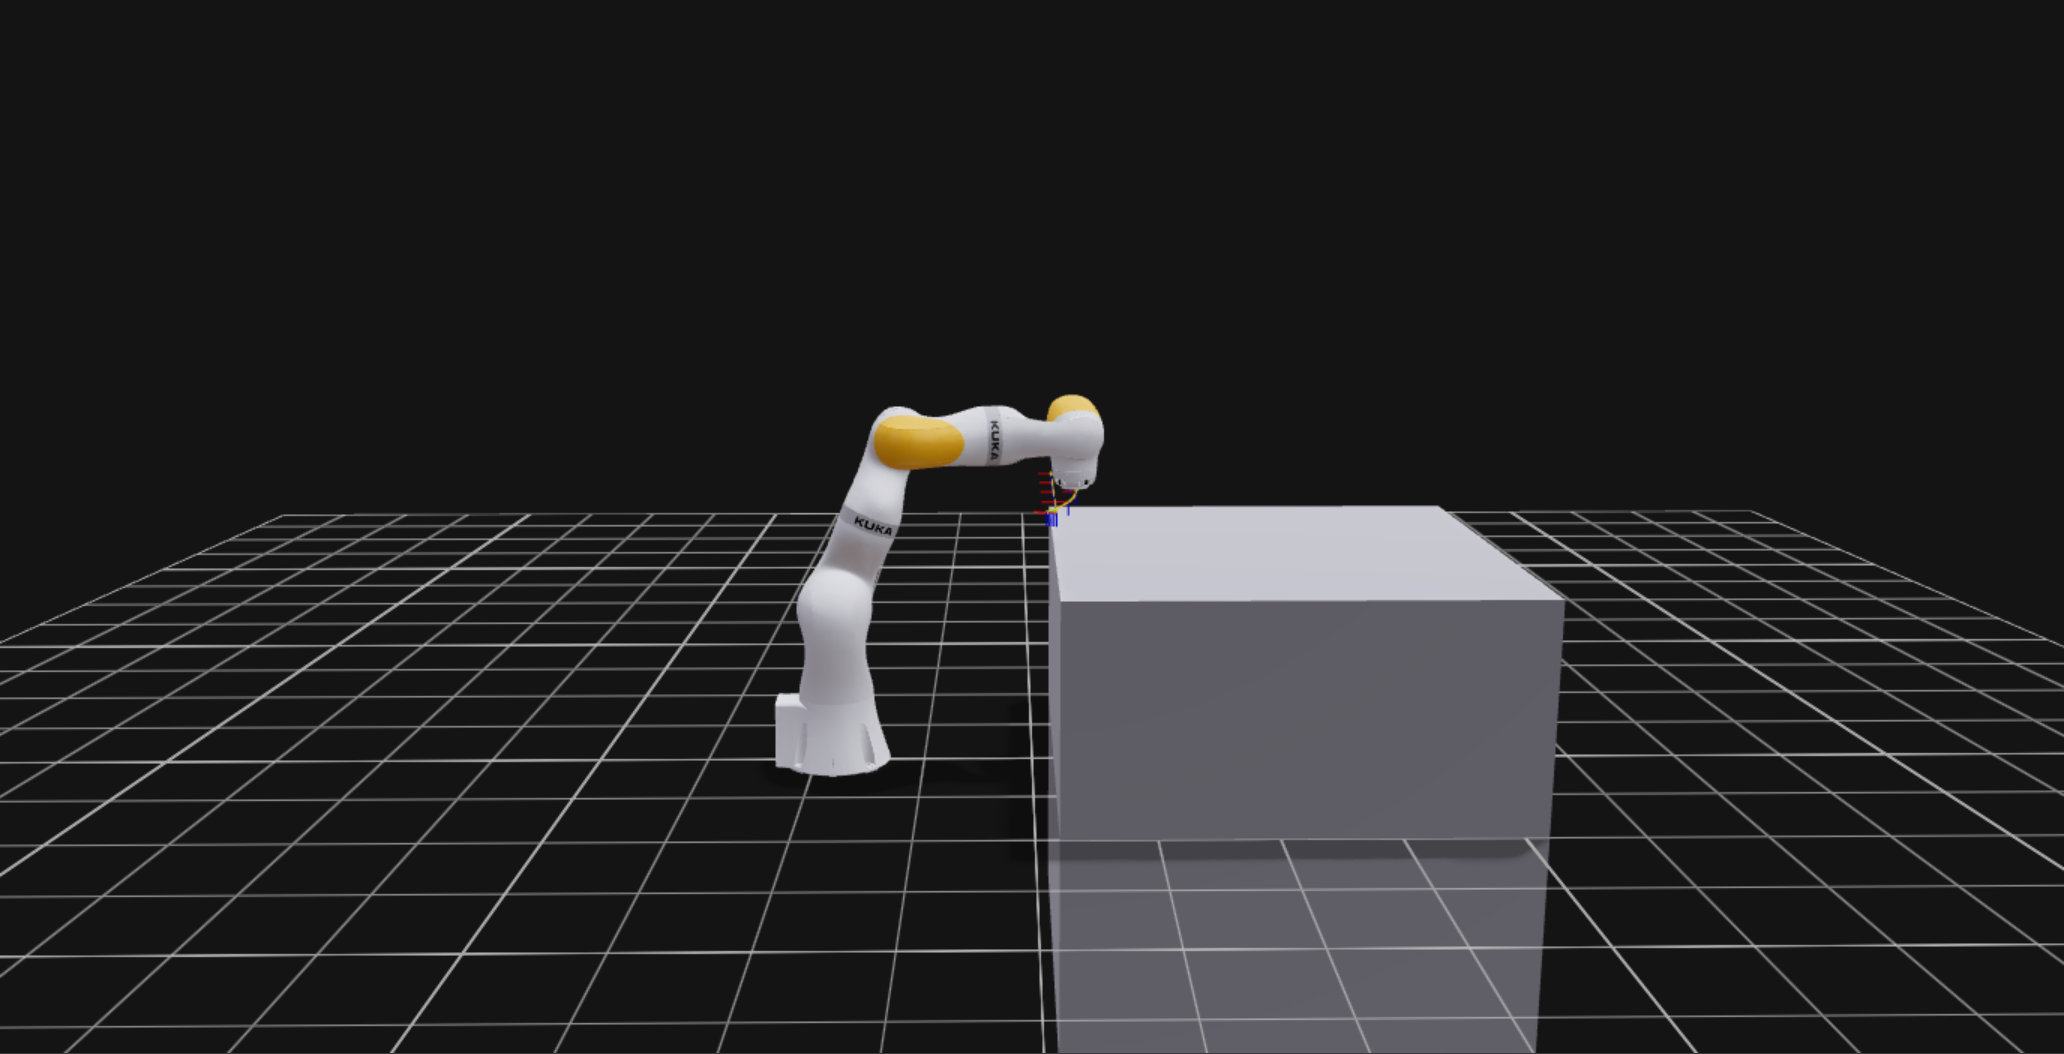
Moves a tool while an orientation constraint keeps it upright.
tesseract_glass_upright_example -
A Cartesian path planned with TrajOpt.
tesseract_basic_cartesian_example
Sampling-based and hybrid
OMPL alone, and OMPL followed by TrajOpt.
-
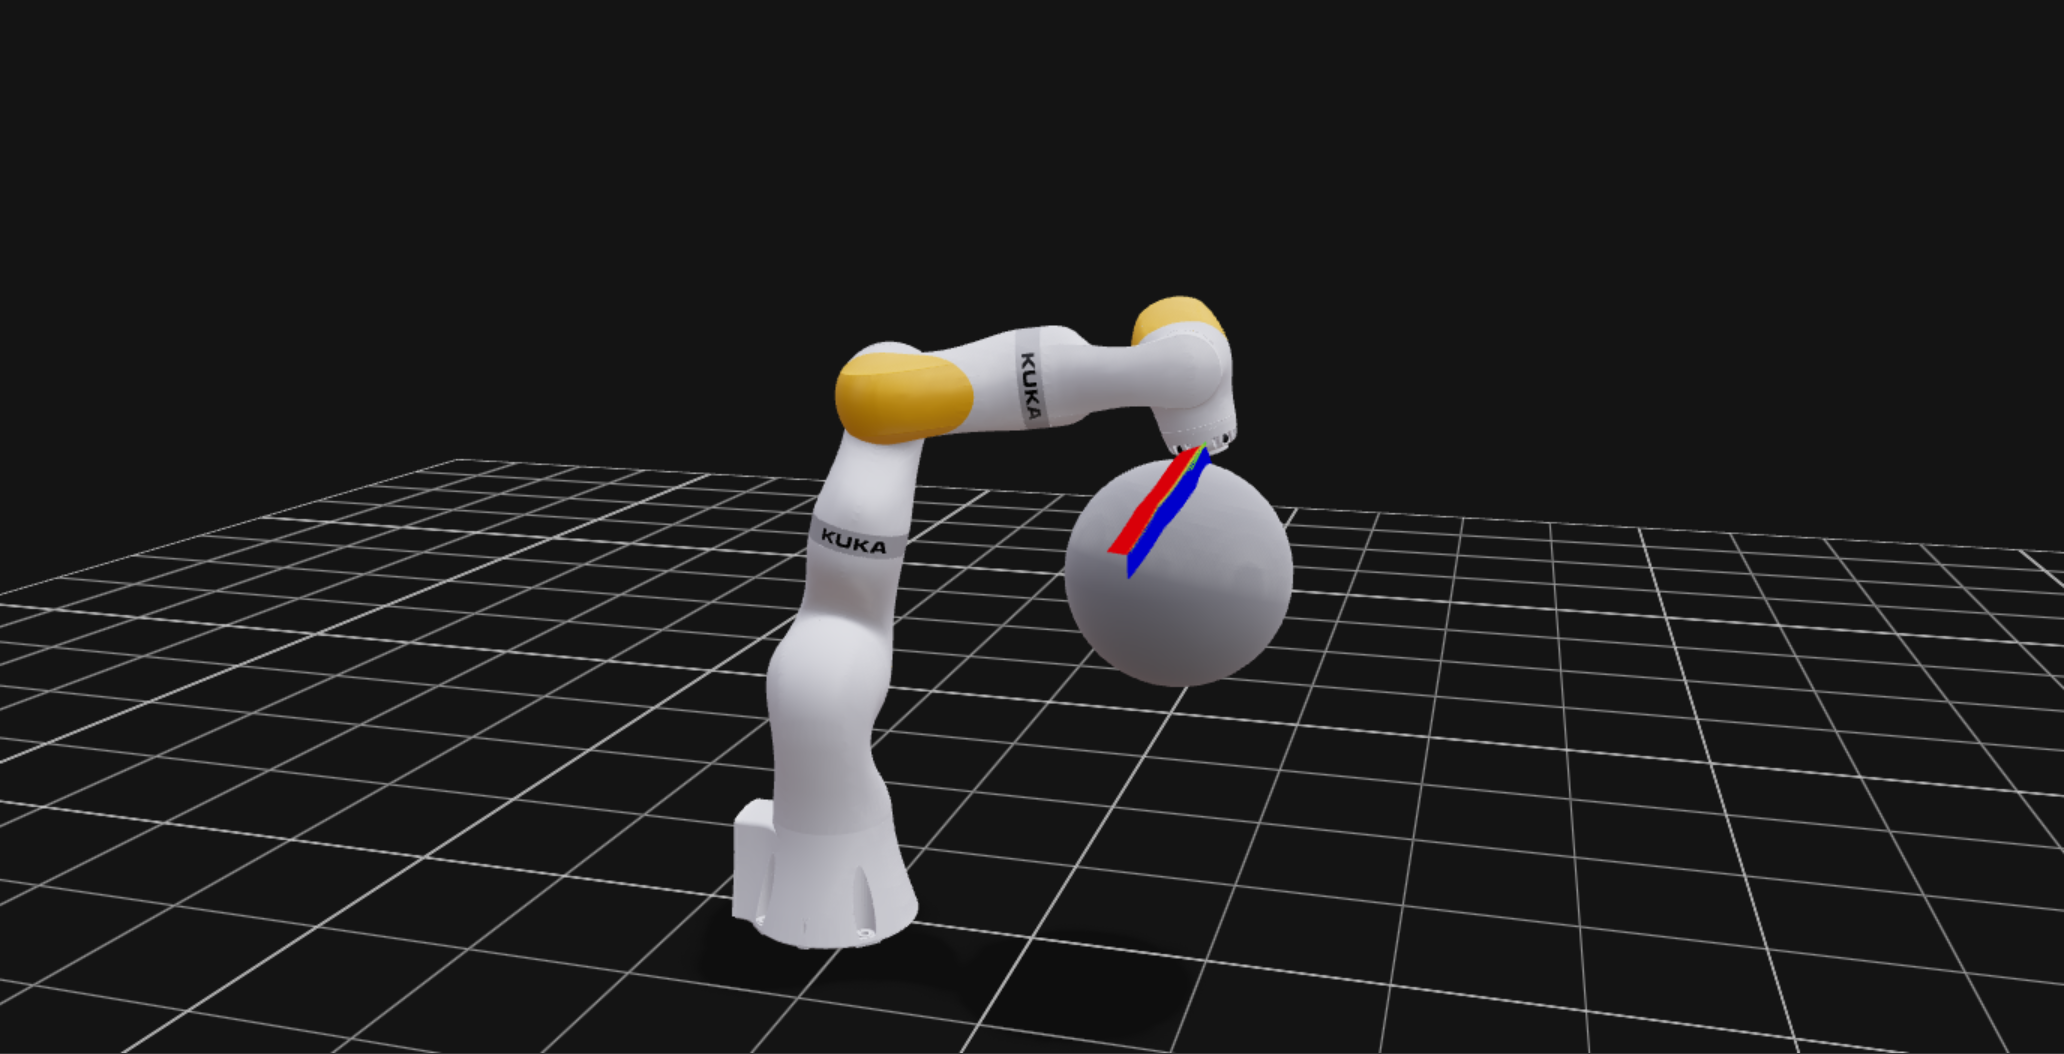
Freespace motion around an obstacle, planned with OMPL.
tesseract_freespace_ompl_example -
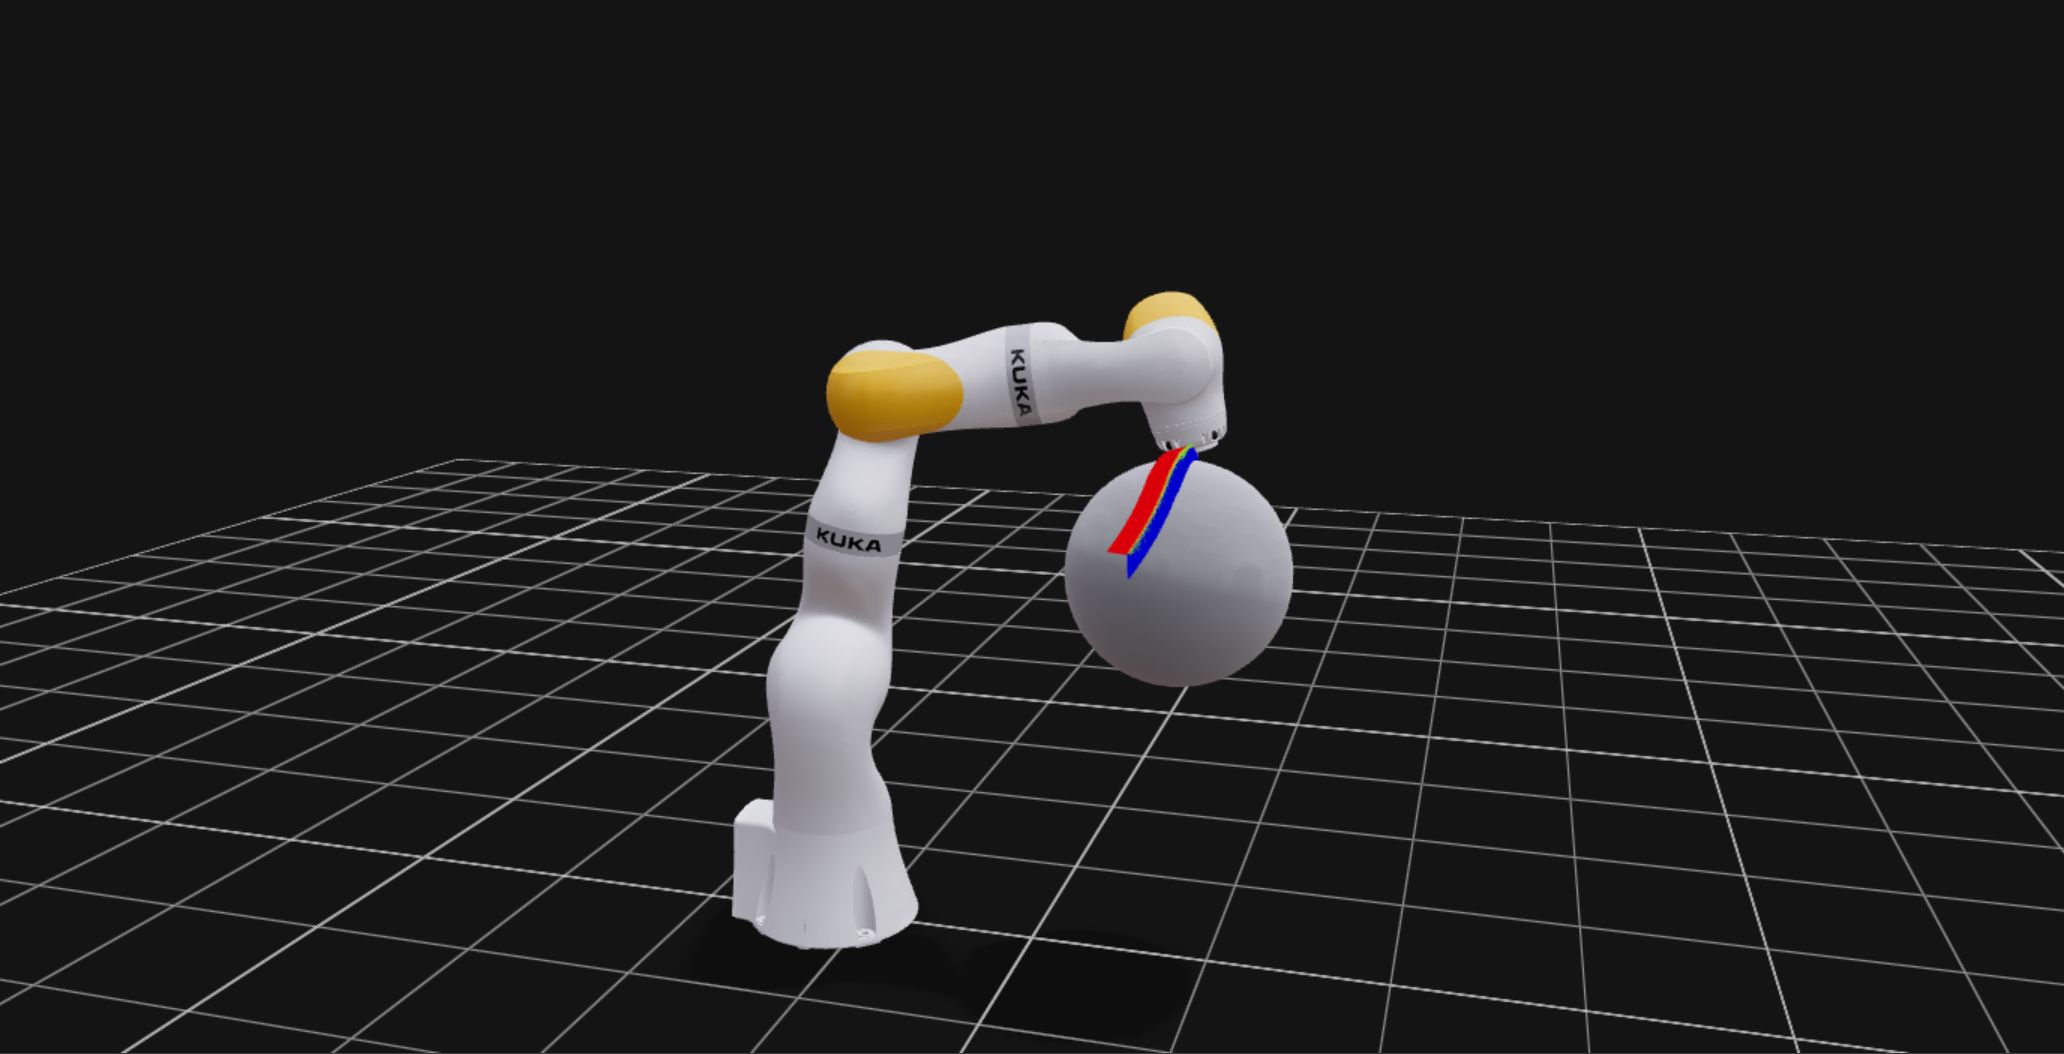
OMPL finds a path around an obstacle; TrajOpt smooths it.
tesseract_freespace_hybrid_example
Online planning
Replanning while the world changes.
-

Replans the gantry's run while a person walks up to the arm and back.
tesseract_online_planning_example -

Replanning through the low-level SQP API, one warm-started solve per tick.
tesseract_online_planning_sqp_example -
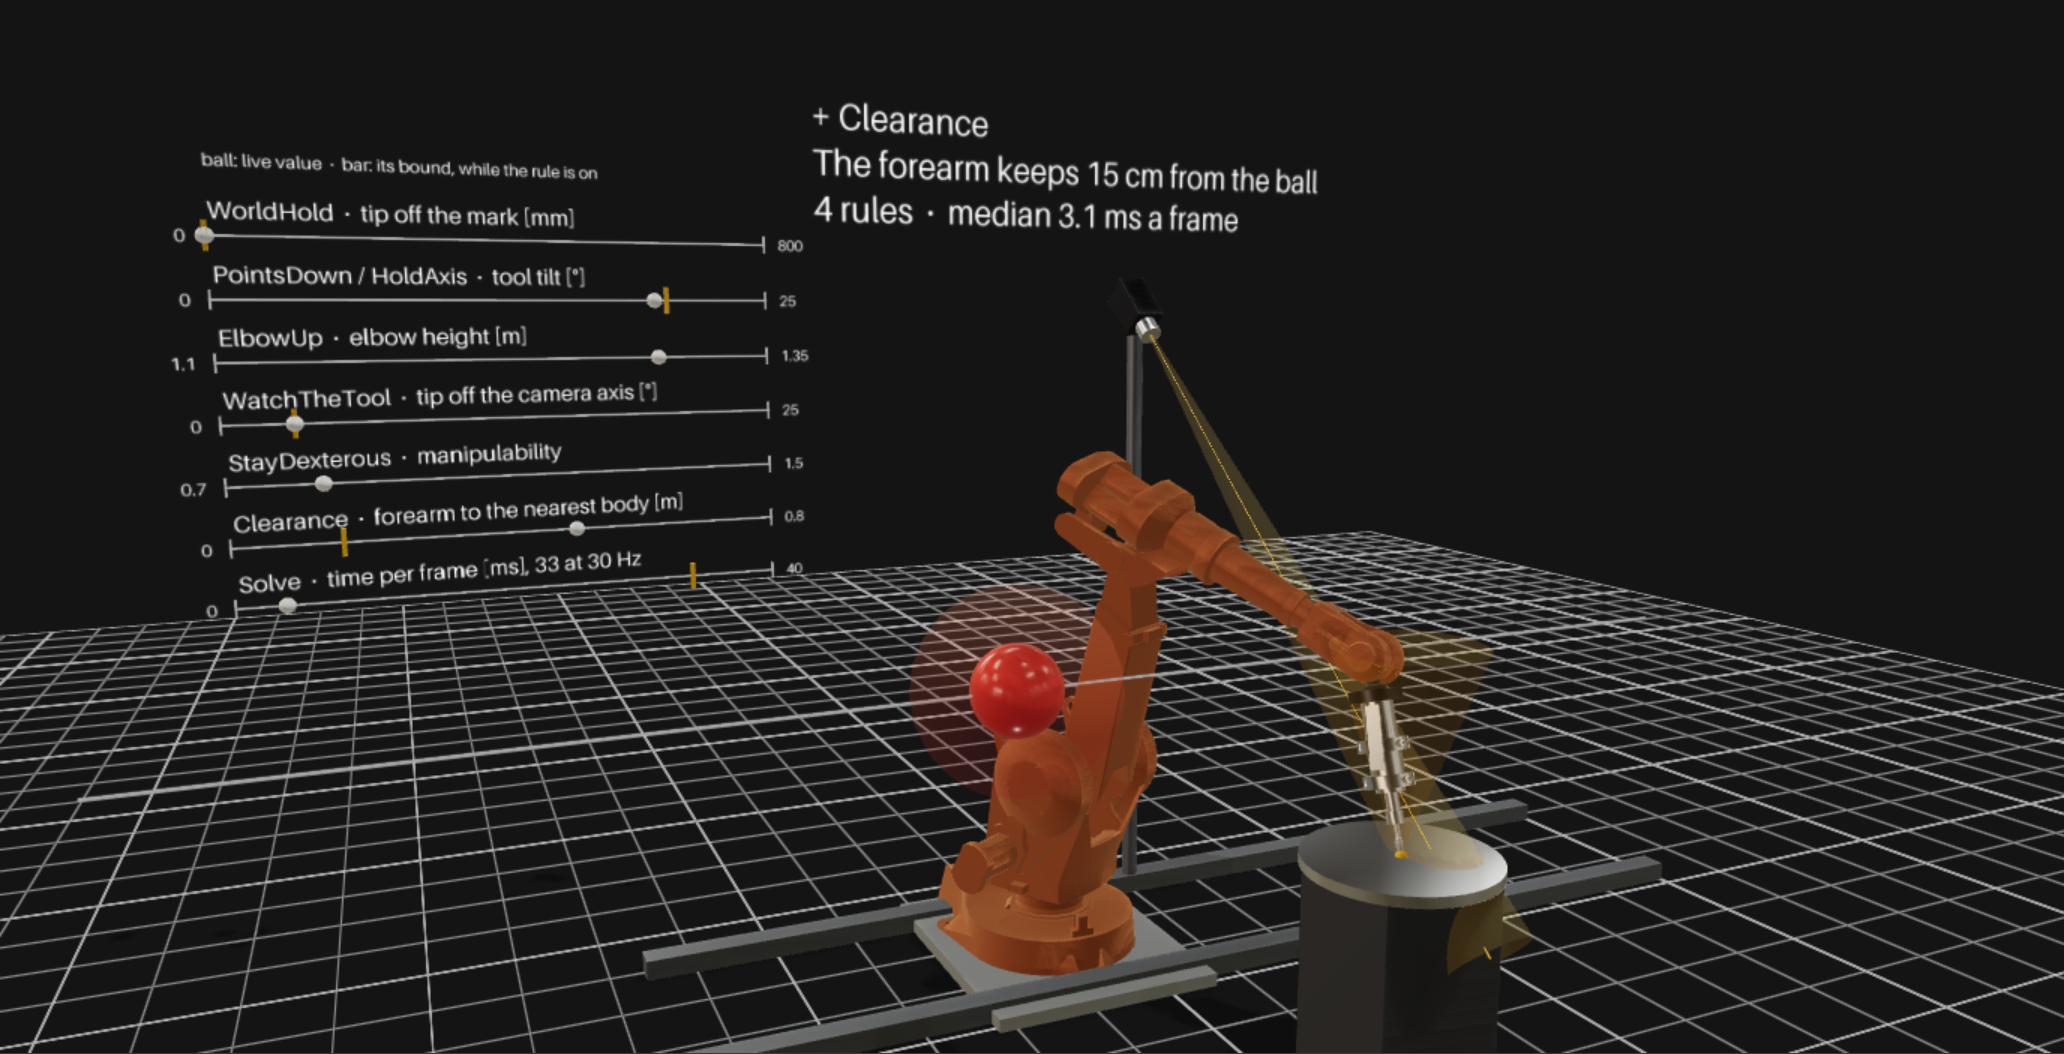
Seven rules written in Python, switched on one after another in a live loop: one solve per frame, a gauge per rule, the solve time against the frame.
tesseract_python_constraints_example
Collision and scenes
Point clouds, signed distance fields, workcells, scene graphs and geometry.
-
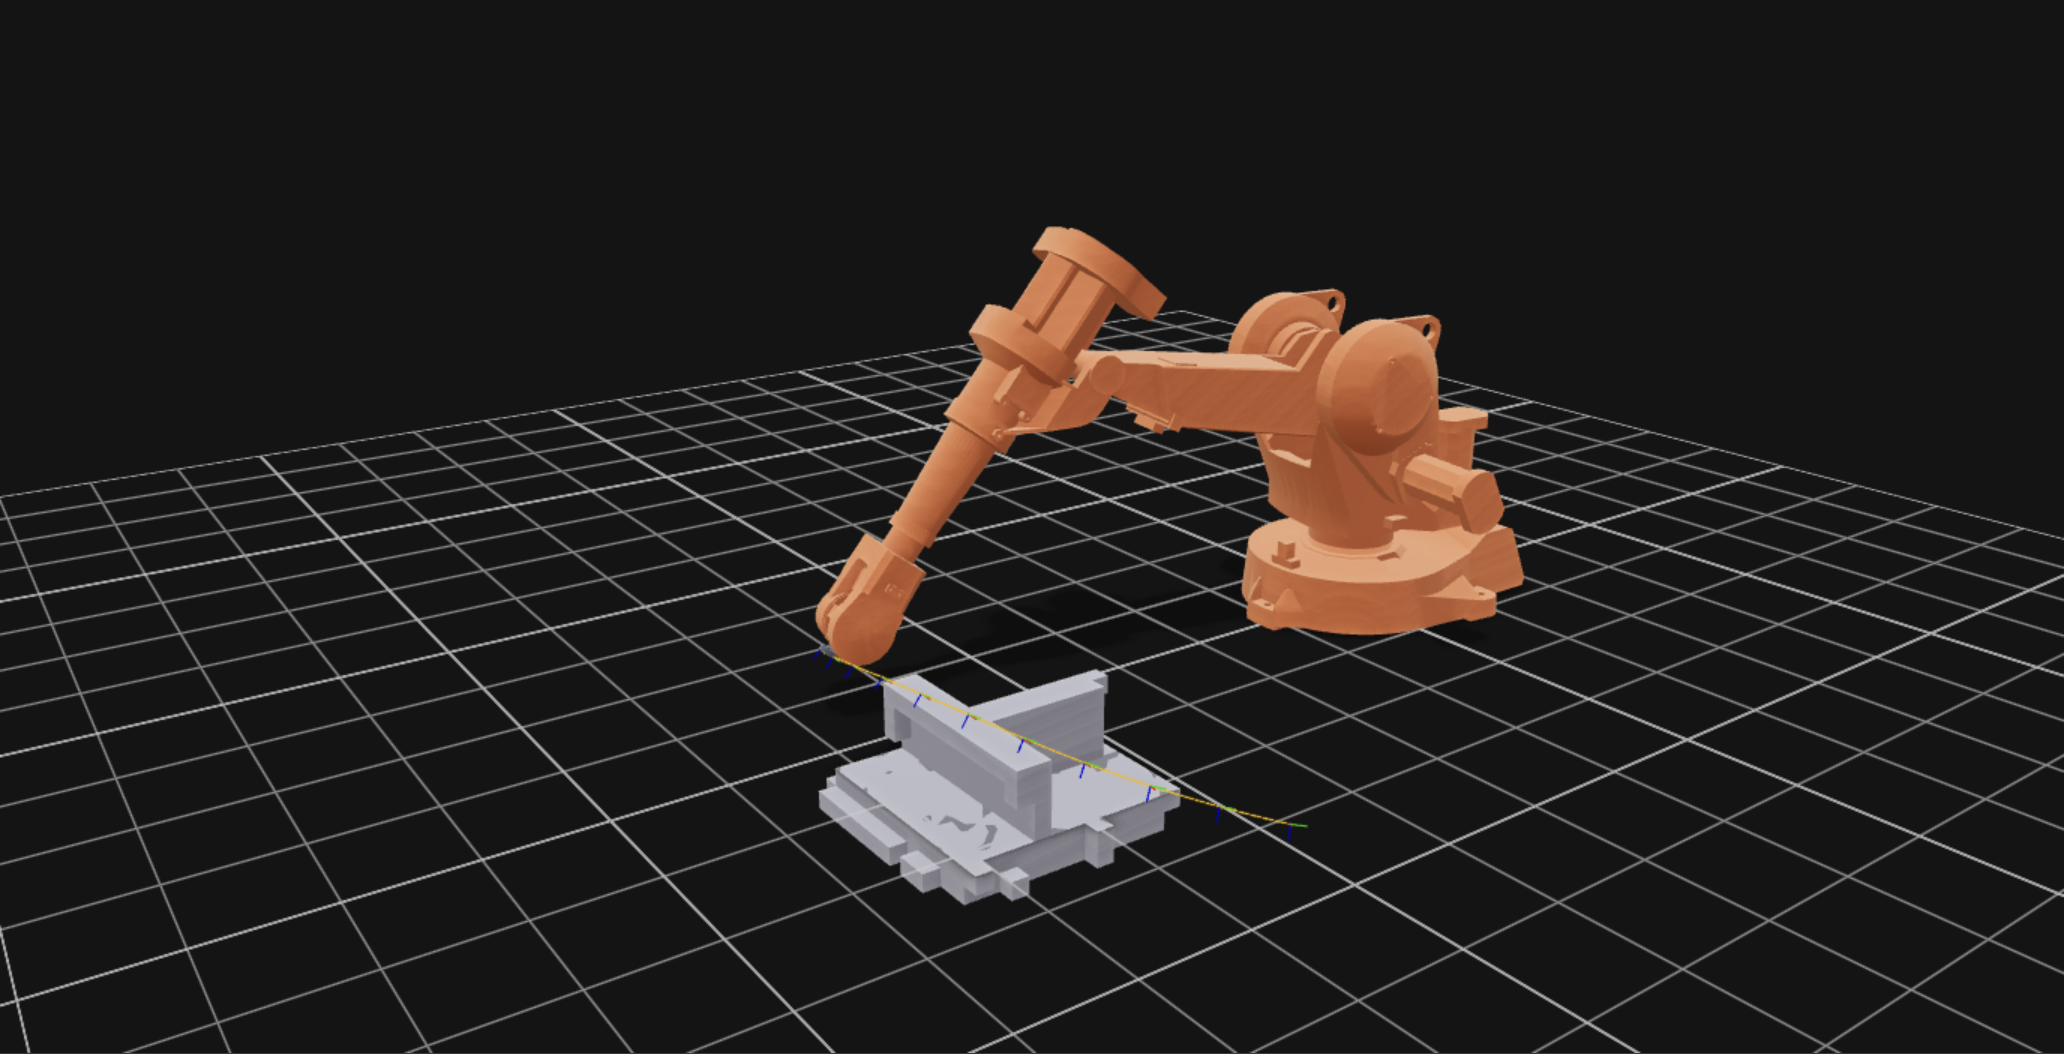
Point cloud collision · source
Plans around an obstacle known only as a point cloud, through an octree.
tesseract_pointcloud_octree_collision_example -
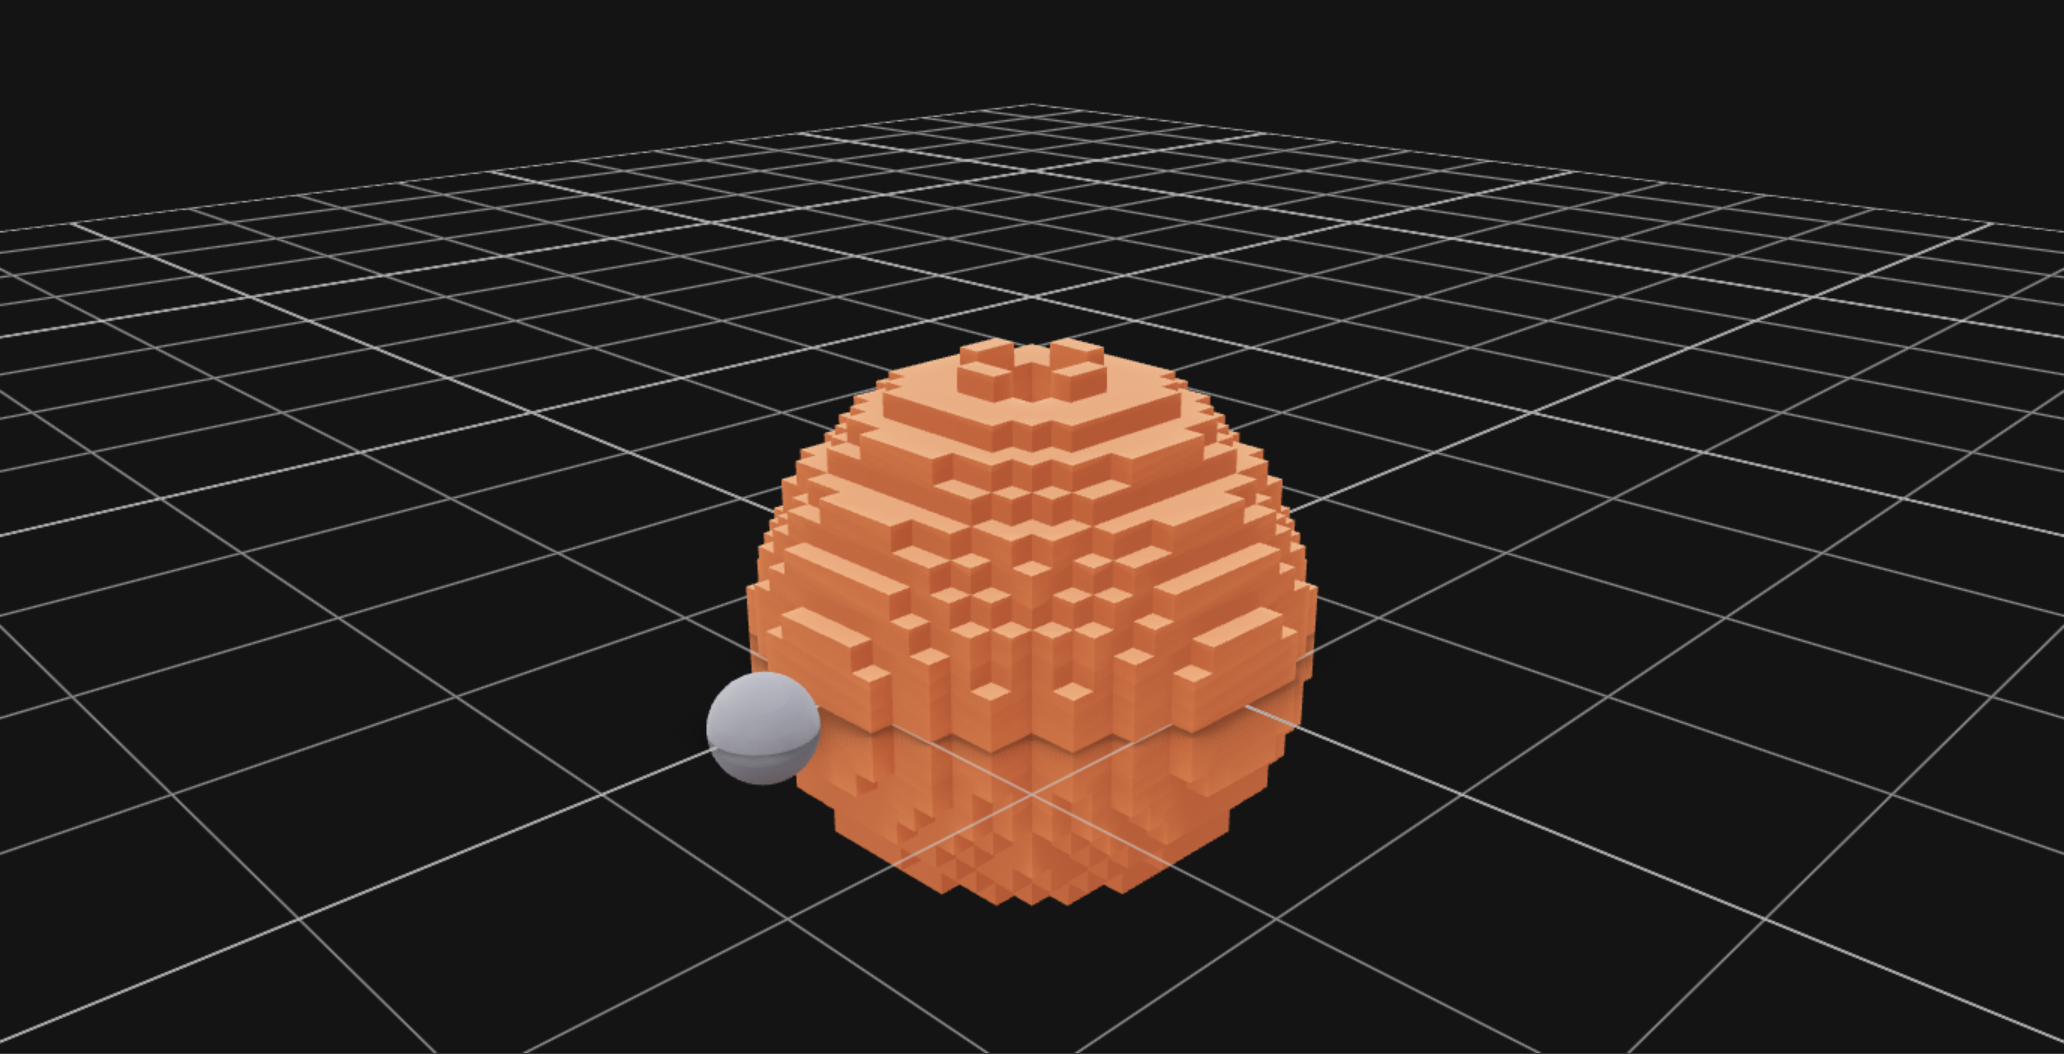
A probe swept through a signed distance field.
tesseract_sdf_collision_example -
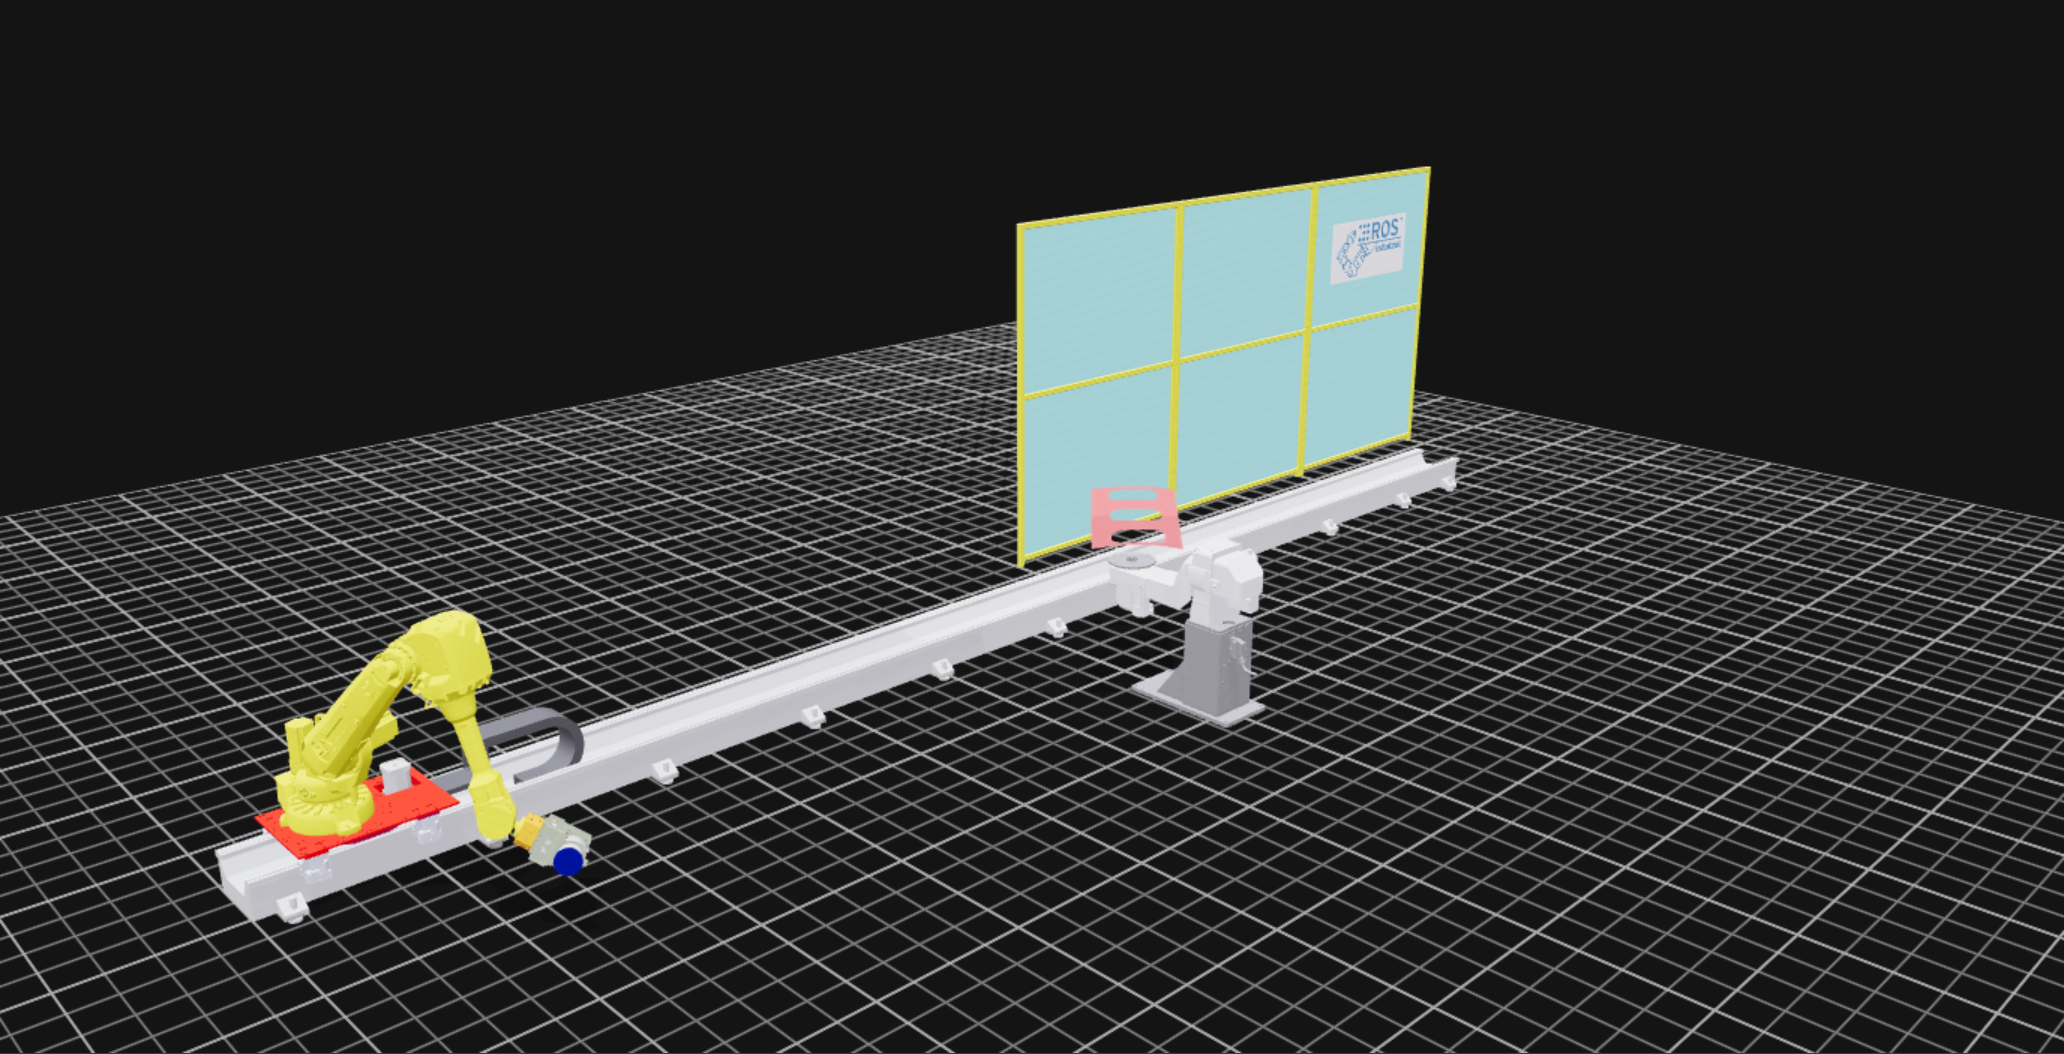
An industrial workcell: a robot on a 12 m rail, beside a positioner.
tesseract_twc_workcell_positioner_viewer -
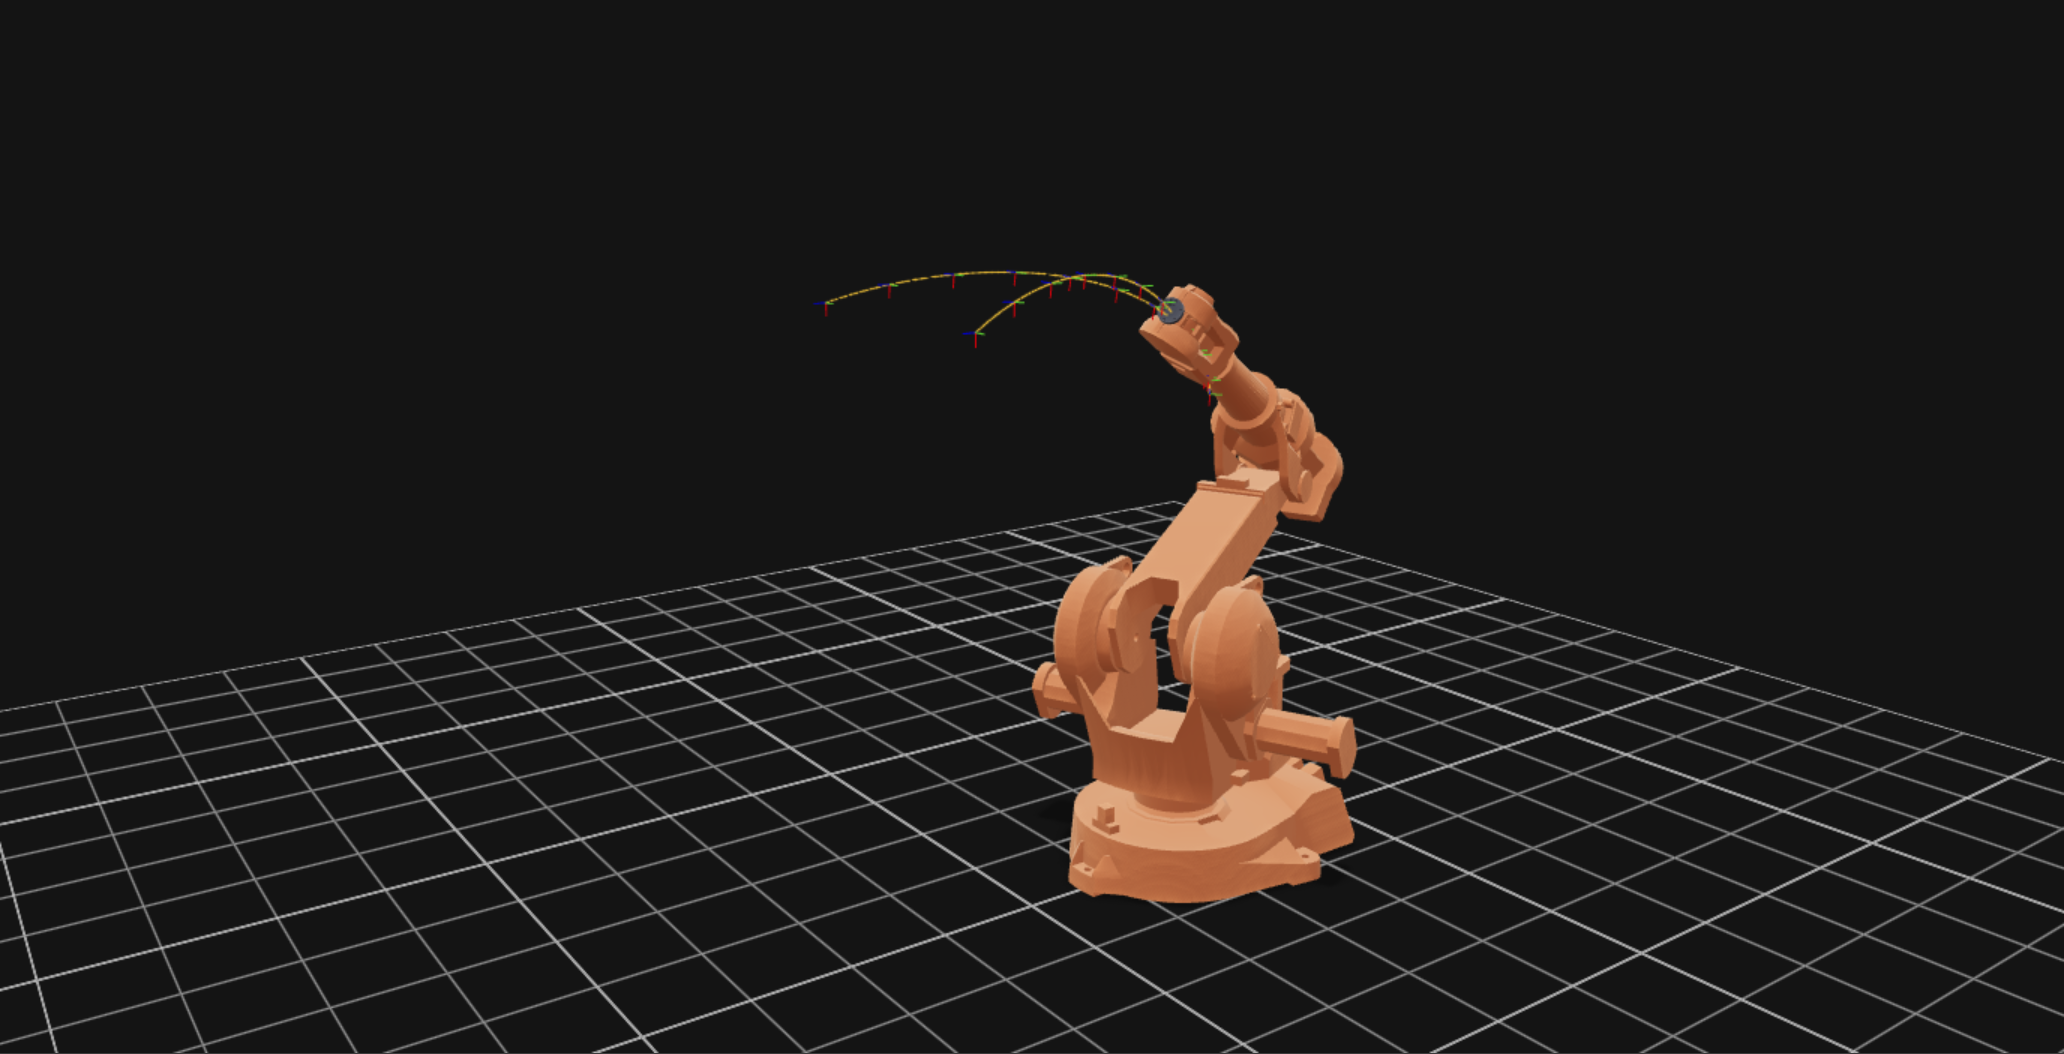
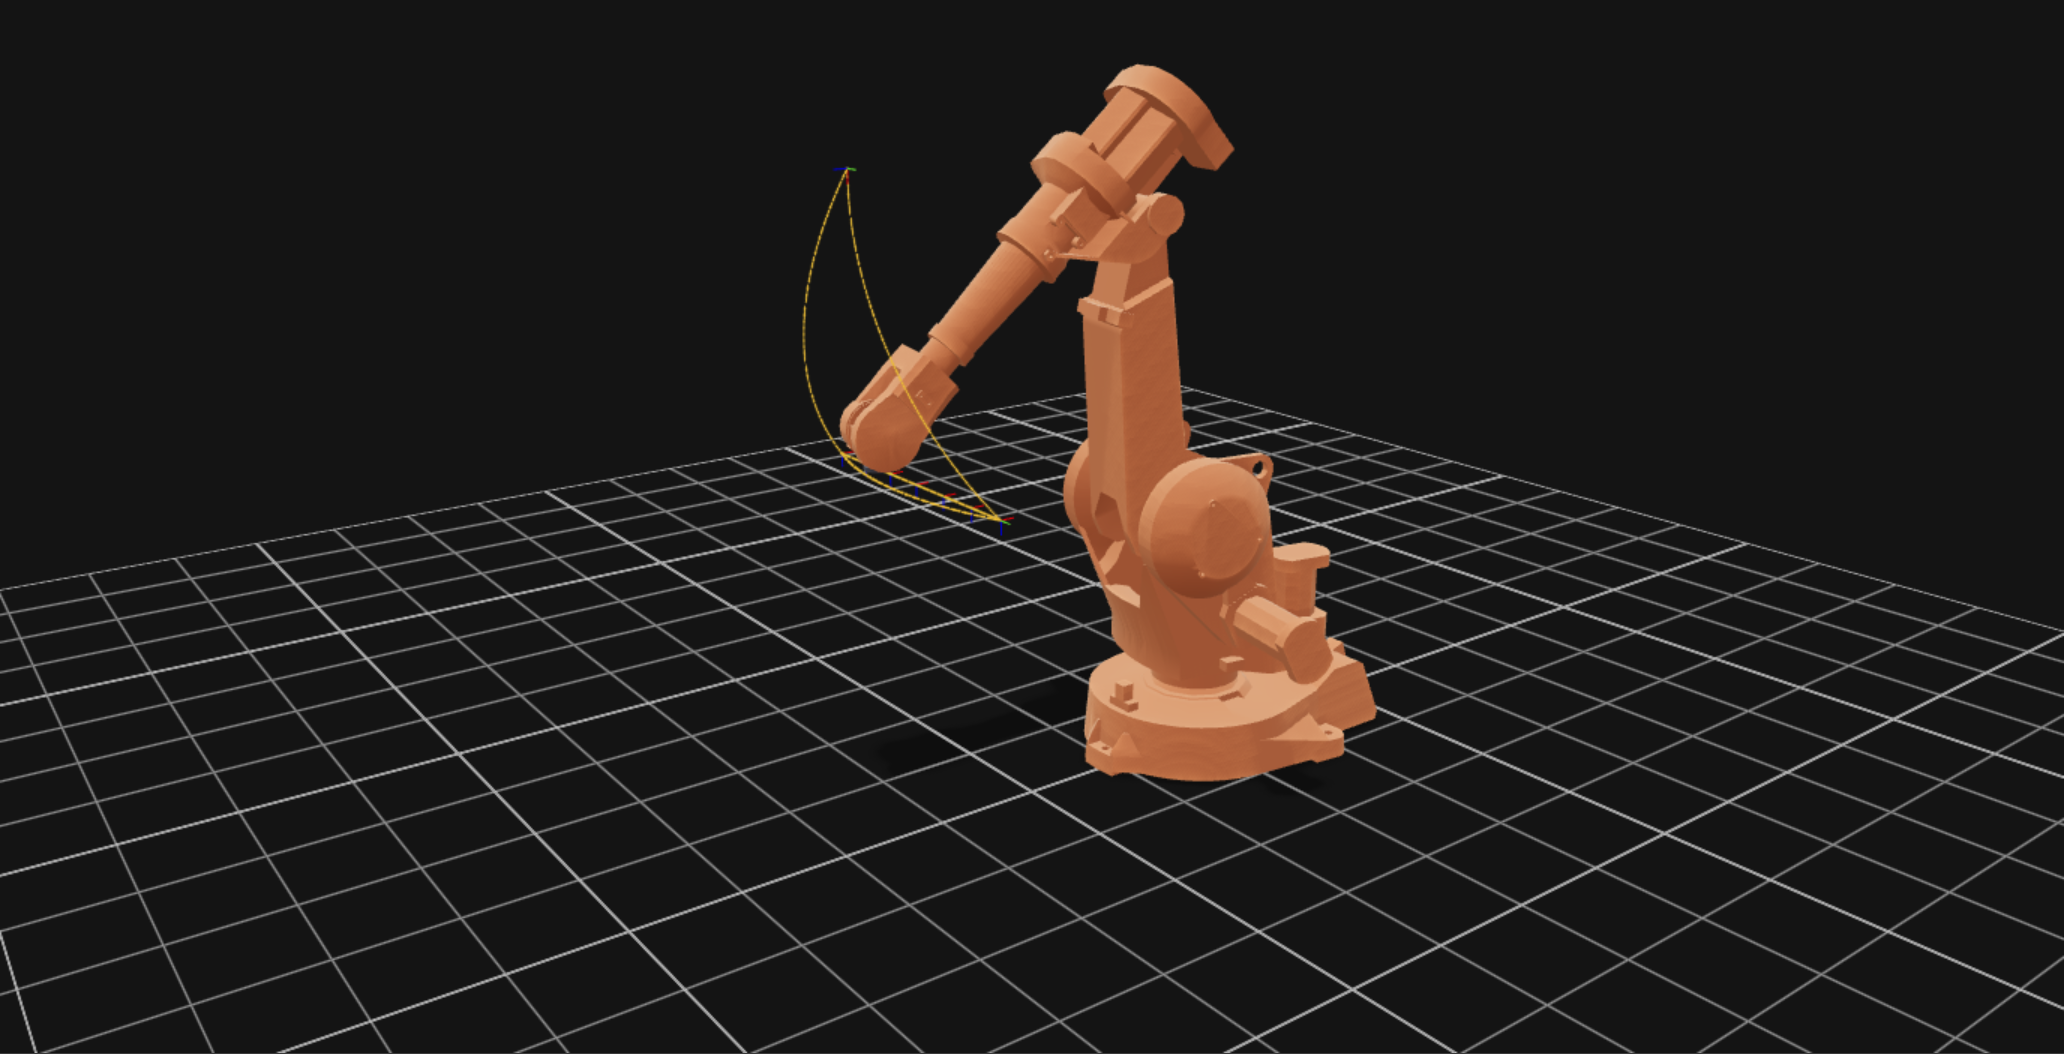
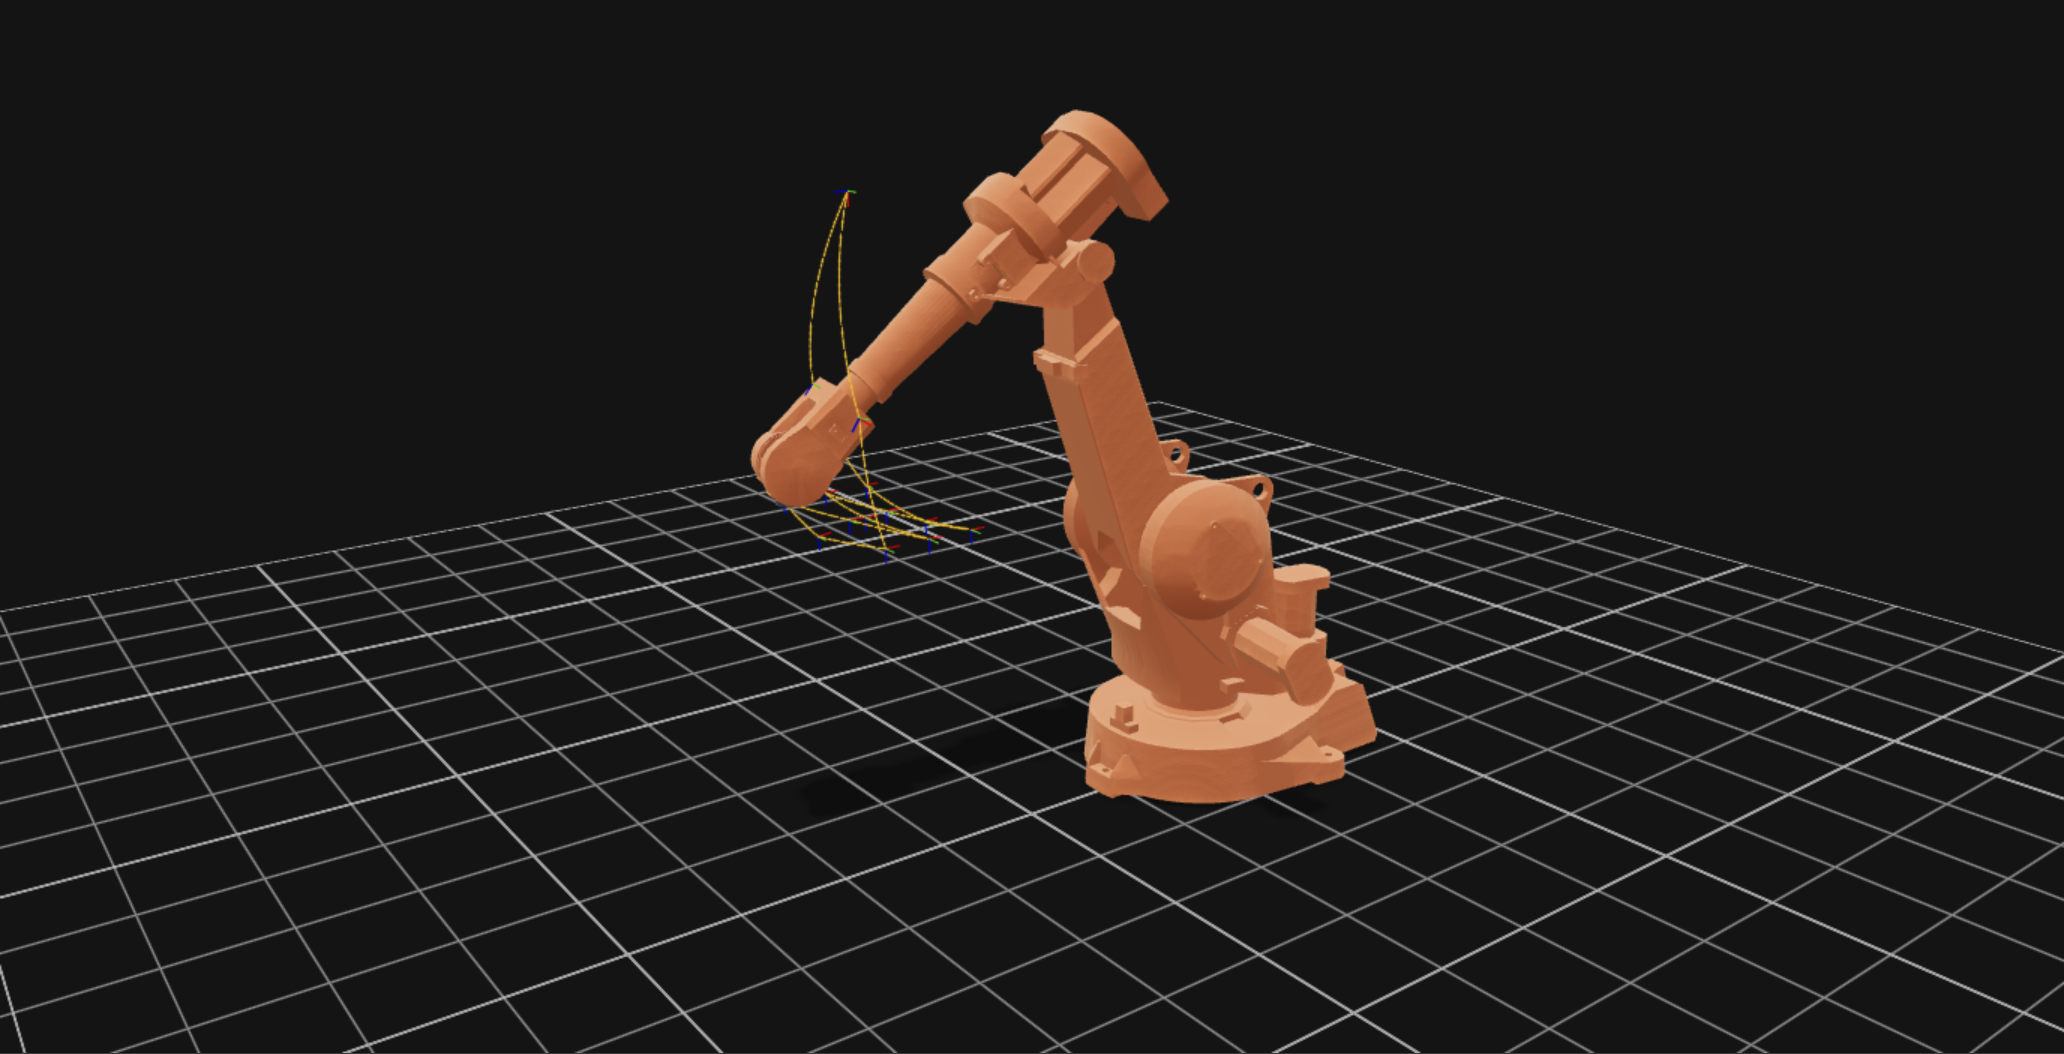
Plans a move on the ABB IRB2400 and draws its TCP path.
tesseract_abb_irb2400_viewer -
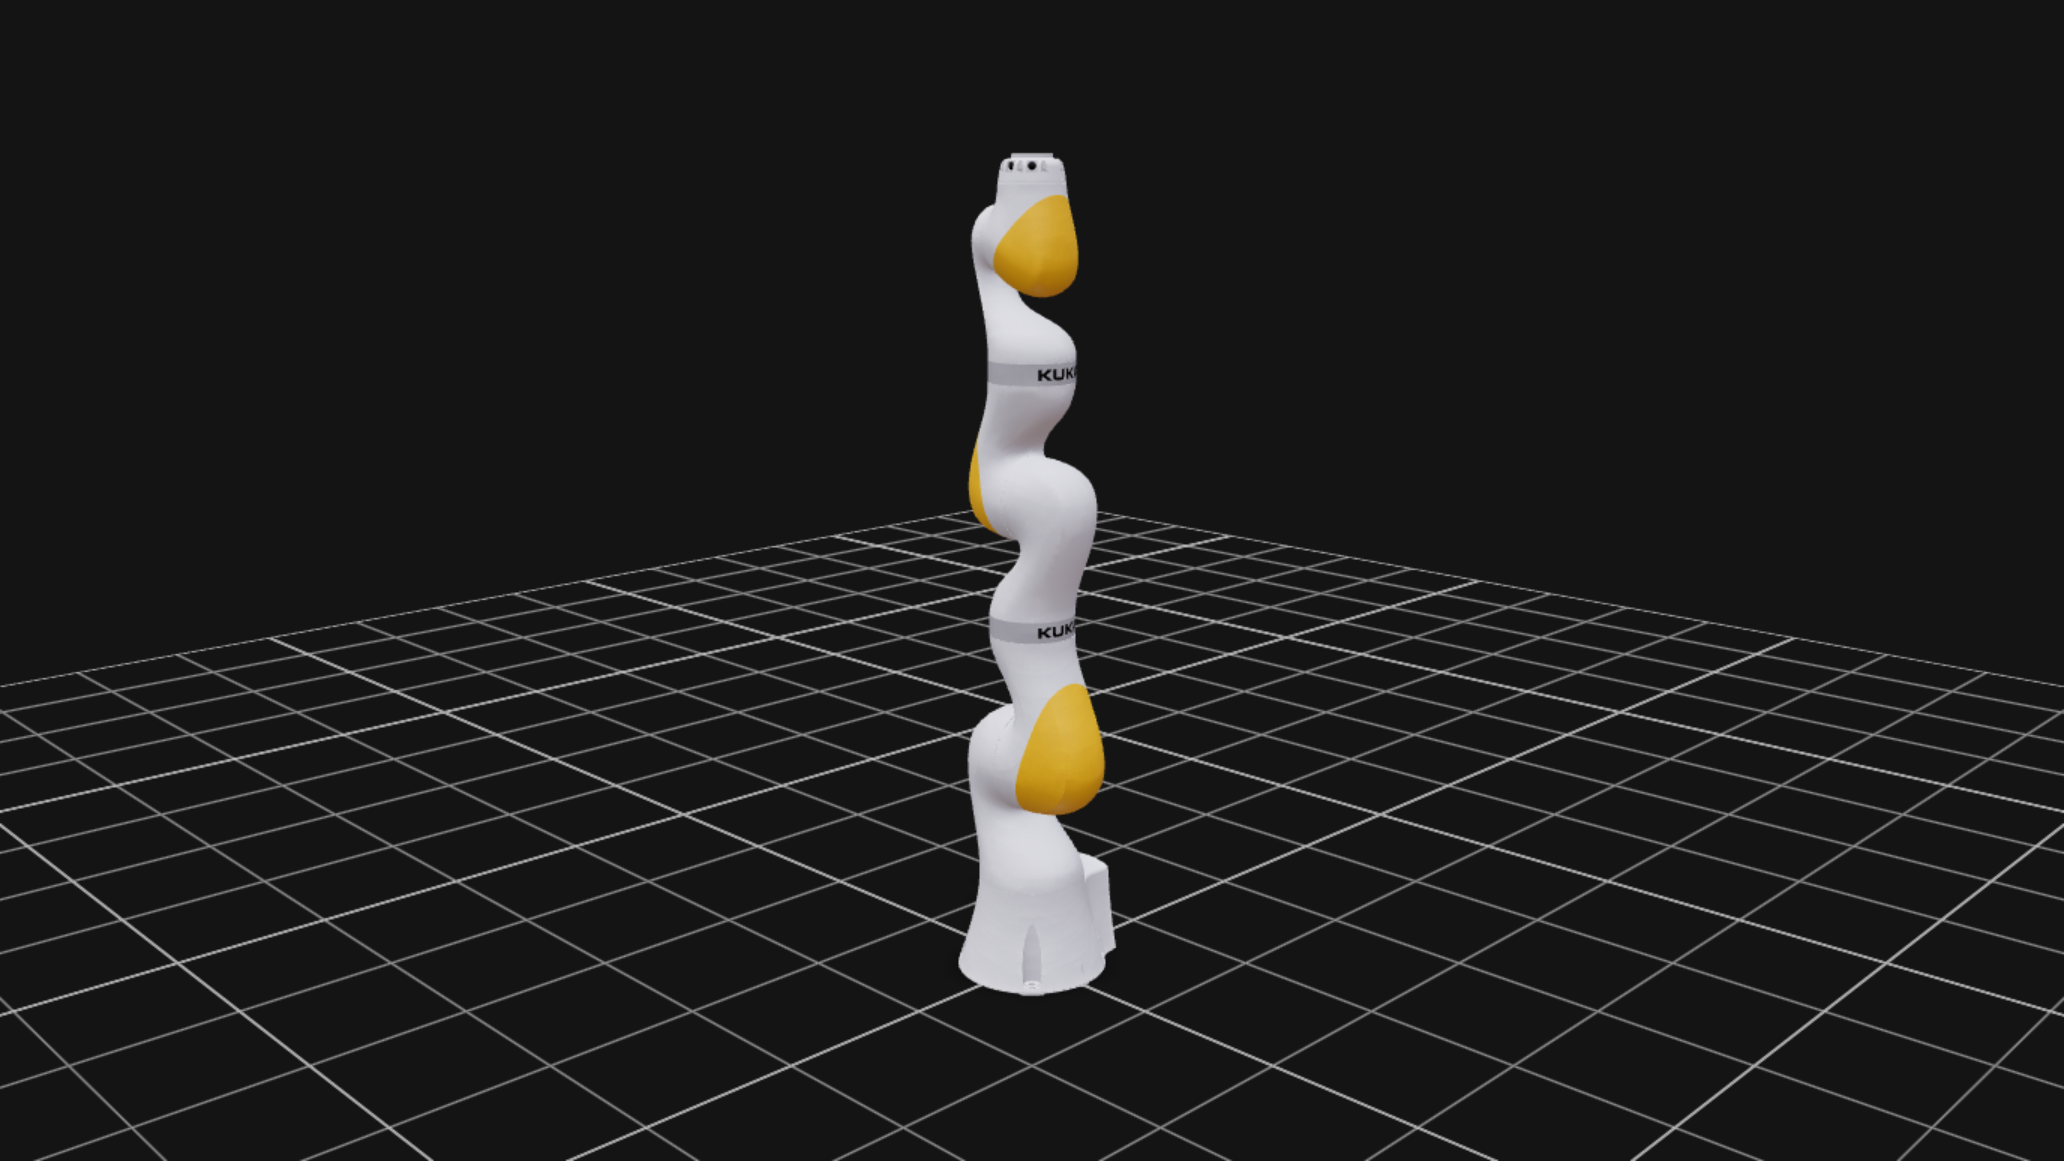
A robot built from a scene graph.
tesseract_scene_graph_example -
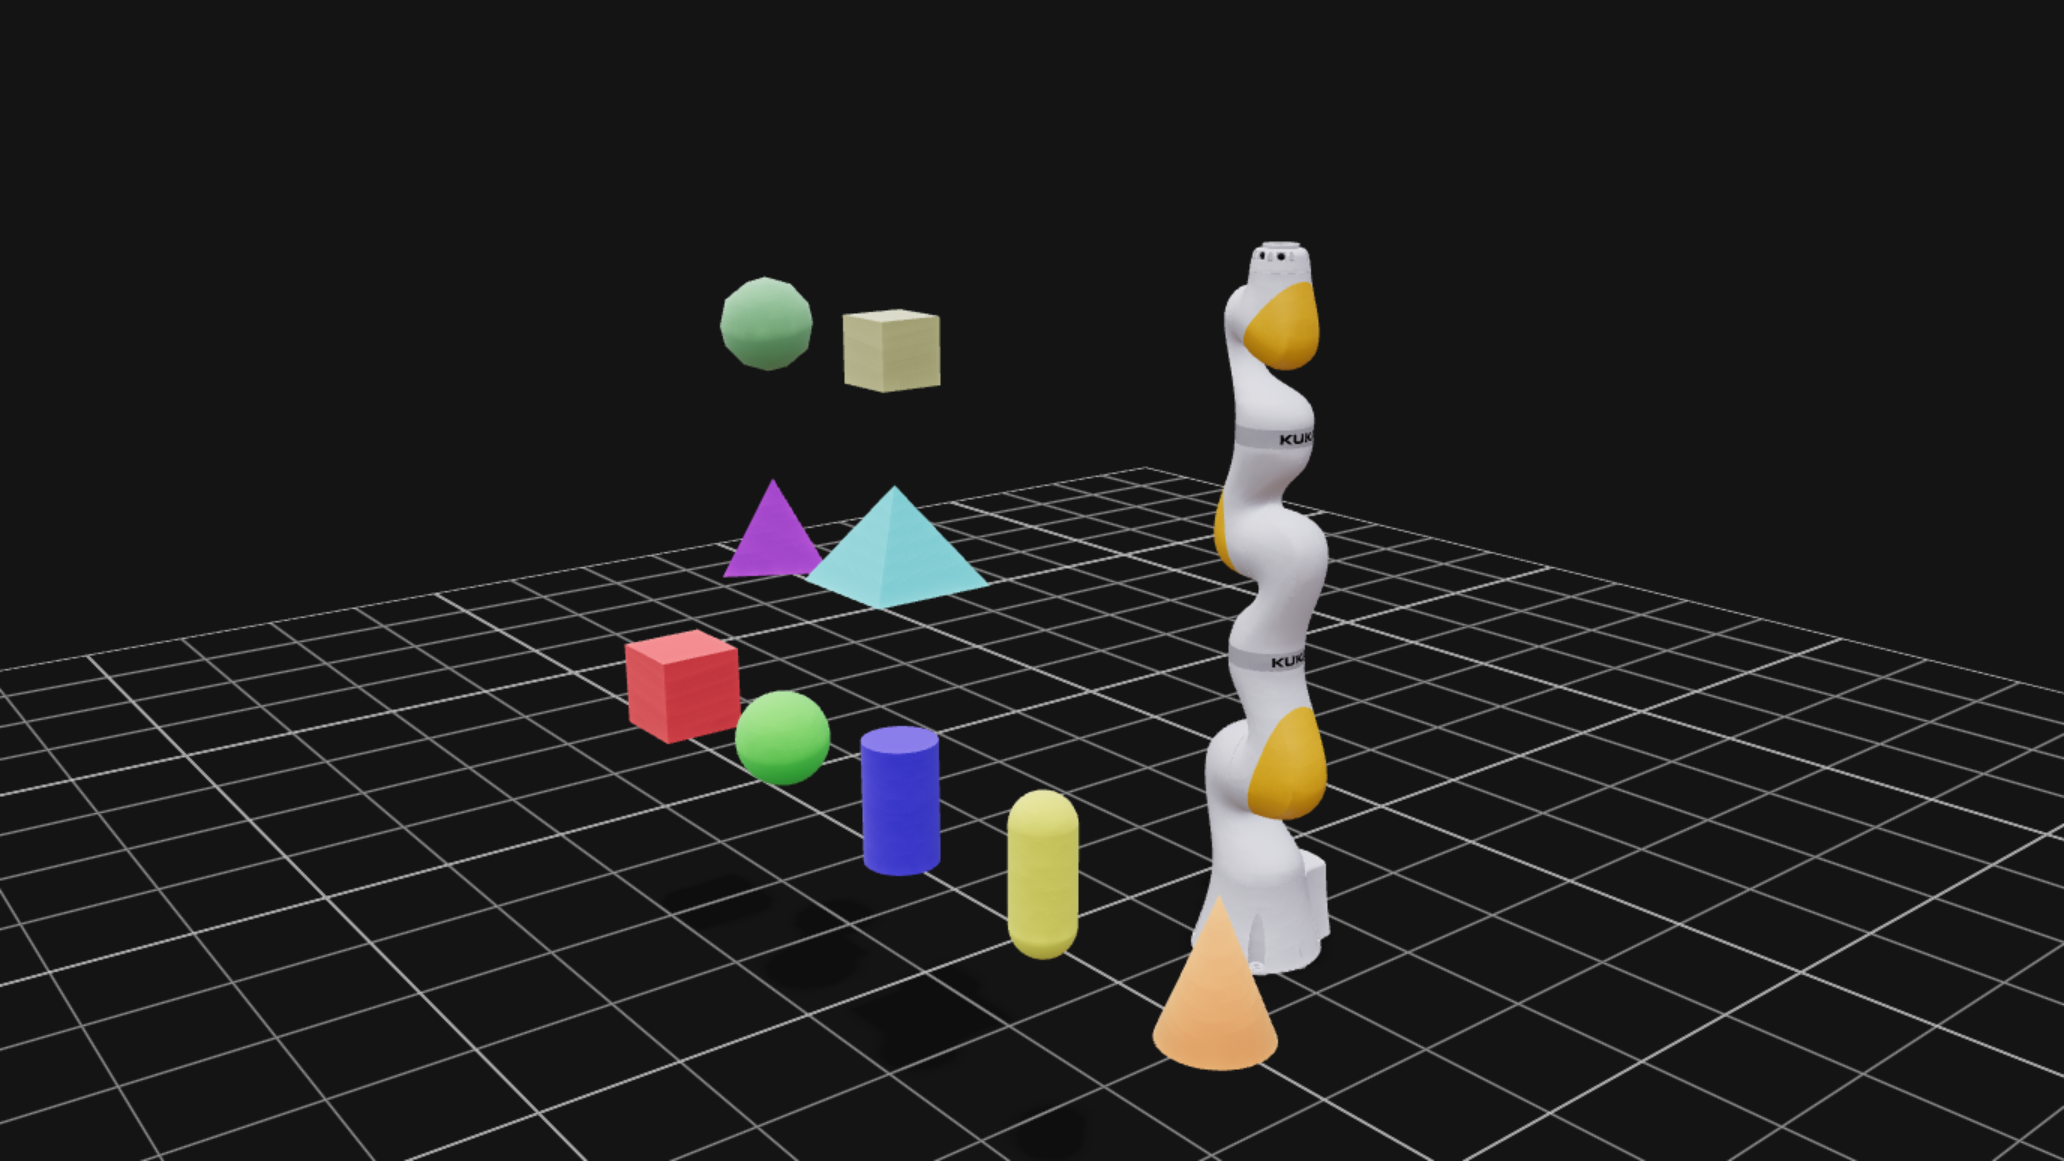
Every geometry type the environment holds: box, sphere, cylinder, mesh and more.
tesseract_geometry_showcase_example -
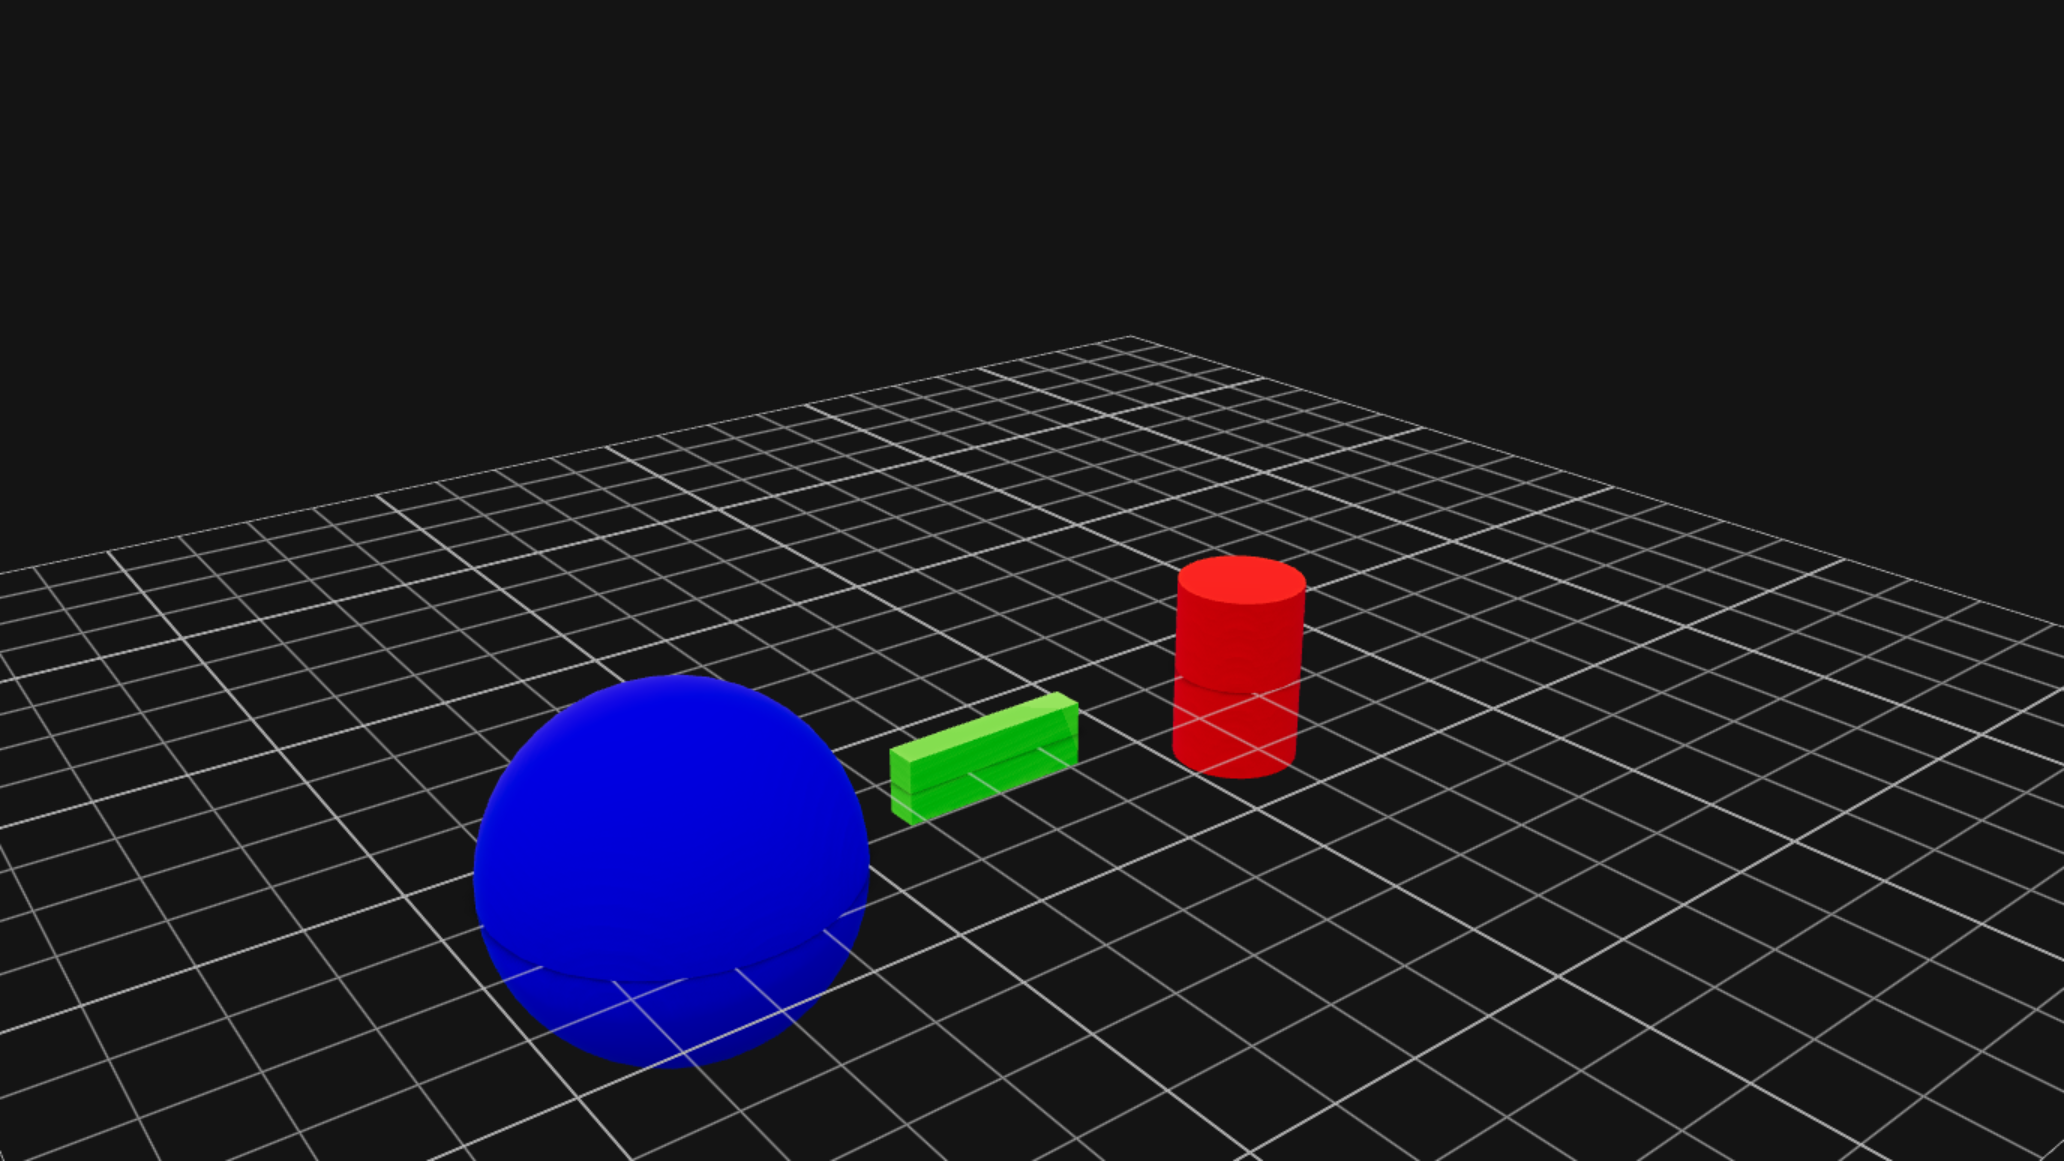
Primitive shapes in the viewer.
tesseract_shapes_viewer -
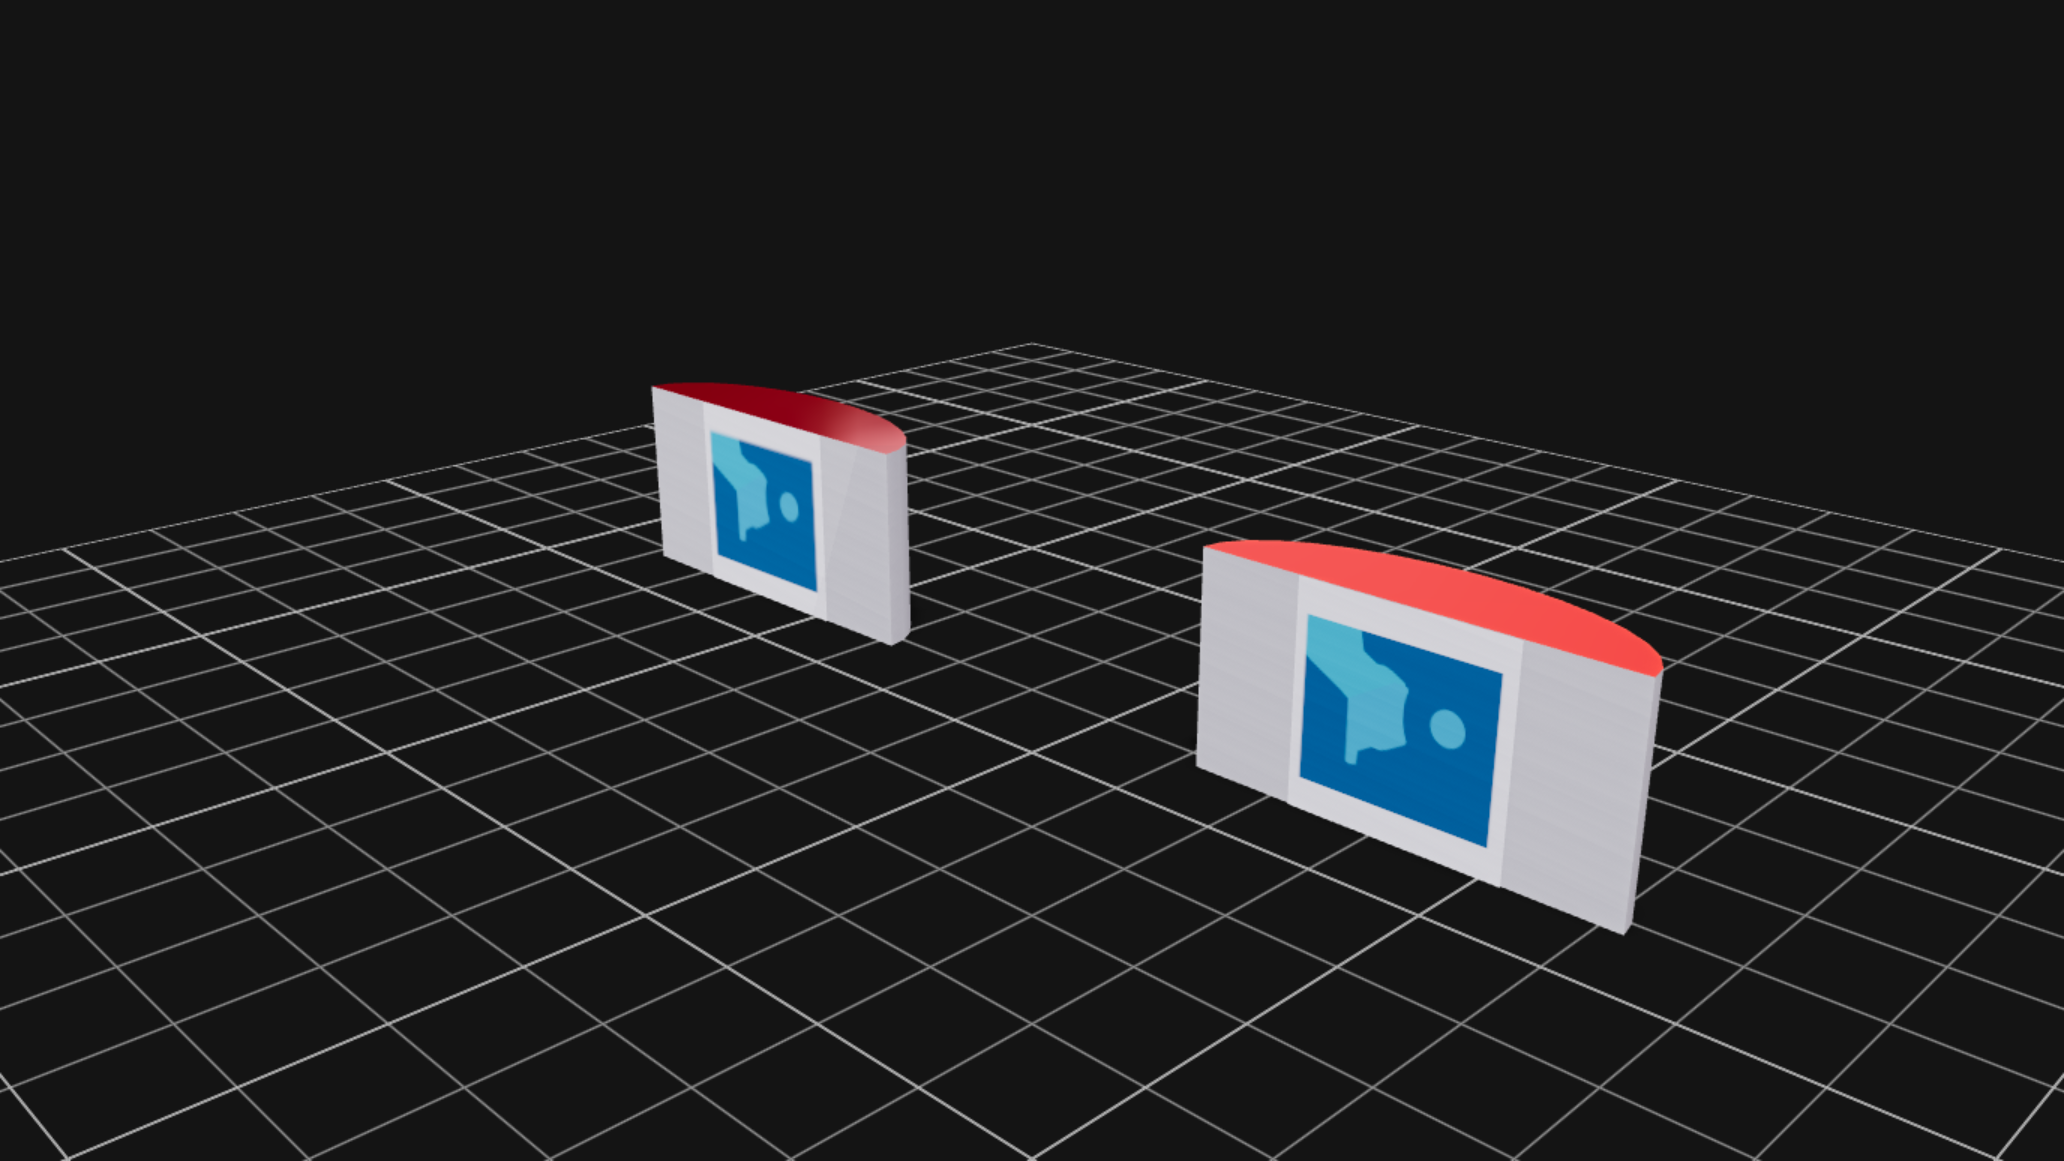
A mesh with materials and textures.
tesseract_material_mesh_viewer
Every example
The console script is the module name with a tesseract_ prefix (kept when the module already
has it). The page column links the walkthrough.
| Module | Console script | Page | What it shows |
|---|---|---|---|
basic_cartesian_example |
tesseract_basic_cartesian_example |
Planning | Cartesian path with TrajOpt |
glass_upright_example |
tesseract_glass_upright_example |
Planning | Linear move with an orientation constraint |
pick_and_place_example |
tesseract_pick_and_place_example |
Planning | Pick, attach, place |
raster_example |
tesseract_raster_example |
Planning | Raster toolpath with freespace transitions |
car_seat_example |
tesseract_car_seat_example |
Planning | Multi-step program on a rail-mounted robot |
chain_example |
tesseract_chain_example |
Planning | Descartes raster refined with TrajOpt |
puzzle_piece_auxillary_axes_example |
tesseract_puzzle_piece_auxillary_axes_example |
Planning | 9-DOF Cartesian toolpath: a 7-DOF arm and a 2-DOF positioner |
abb_irb2400_viewer |
tesseract_abb_irb2400_viewer |
Planning | A planned move and its TCP path in the viewer |
pythonic_api_example |
tesseract_pythonic_api_example |
Low-level examples | The low-level examples' steps through tesseract_robotics.planning |
freespace_ompl_example |
tesseract_freespace_ompl_example |
OMPL | OMPL freespace motion |
freespace_hybrid_example |
tesseract_freespace_hybrid_example |
OMPL | OMPL, then TrajOpt |
freespace_clearance_objective_example |
tesseract_freespace_clearance_objective_example |
OMPL | OMPL objective written in Python; a cost threshold ends the optimize loop |
online_planning_example |
tesseract_online_planning_example |
Online planning | Task composer replanning around a walking person |
online_planning_sqp_example |
tesseract_online_planning_sqp_example |
Online planning | Low-level SQP replanning, warm-started each tick; --sliders to move the person yourself |
python_constraints_example |
tesseract_python_constraints_example |
Python constraints | Seven constraints written in Python, in a live loop, scripted or driven by sliders |
tesseract_kinematics_example |
tesseract_kinematics_example |
Basics | FK and IK with a kinematic group |
tesseract_collision_example |
tesseract_collision_example |
Basics | Discrete collision check |
scene_graph_example |
tesseract_scene_graph_example |
Basics | Build and query a scene graph |
geometry_showcase_example |
tesseract_geometry_showcase_example |
Basics | Every geometry type |
pointcloud_octree_collision_example |
tesseract_pointcloud_octree_collision_example |
Basics | Point cloud to octree to collision-aware TrajOpt |
kinematics_plugins_example |
tesseract_kinematics_plugins_example |
Kinematics | Kinematics plugin factory: solvers, configs |
kinematics_analysis_example |
tesseract_kinematics_analysis_example |
Kinematics | Jacobians, twists, manipulability, limits |
state_solver_example |
tesseract_state_solver_example |
Kinematics | State solver: floating joints, Jacobians |
contact_managers_example |
tesseract_contact_managers_example |
Collision | Contact managers, margins, ACM, cast manager |
trajectory_collision_example |
tesseract_trajectory_collision_example |
Collision | Trajectory checks, LVS, rebuilt from their parts |
convex_decomposition_example |
tesseract_convex_decomposition_example |
Collision | Convex decomposition options and fill modes |
sdf_collision_example |
tesseract_sdf_collision_example |
Collision | A probe swept through a signed distance field |
environment_commands_example |
tesseract_environment_commands_example |
Environment | Commands, history, replay, calibration |
environment_state_example |
tesseract_environment_state_example |
Environment | State, floating joints, TCPs, manipulator info |
plugin_configuration_example |
tesseract_plugin_configuration_example |
Environment | Contact manager and task composer plugin configuration |
mesh_roundtrip_example |
tesseract_mesh_roundtrip_example |
Geometry | Meshes from bytes, materials, round trips |
shapes_viewer |
tesseract_shapes_viewer |
Geometry | Primitive shapes in the viewer |
tesseract_material_mesh_viewer |
tesseract_material_mesh_viewer |
Geometry | Materials and textures |
twc_workcell_positioner_viewer |
tesseract_twc_workcell_positioner_viewer |
Viewer | Industrial workcell with a positioner (needs git submodule update --init) |
Low-level examples
tesseract_robotics.examples.lowlevel ports the C++ tesseract_planning/examples with
the binding types alone, never tesseract_robotics.planning, and with the C++ parameters
(tests/examples/test_lowlevel_bindings_only.py enforces the first). They are the
reference for what the high-level examples above wrap. Run them as modules:
| Example | C++ original | Description |
|---|---|---|
freespace_ompl_c_api_example.py |
freespace_ompl_example.cpp |
OMPLPipeline around a sphere |
basic_cartesian_c_api_example.py |
basic_cartesian_example.cpp |
TrajOpt Cartesian path past an octomap (ifopt=True for TrajOptIfopt) |
glass_upright_c_api_example.py |
glass_upright_example.cpp |
Orientation-held linear move |
puzzle_piece_c_api_example.py |
puzzle_piece_example.cpp |
Toolpath from CSV |
puzzle_piece_auxillary_axes_c_api_example.py |
puzzle_piece_auxillary_axes_example.cpp |
9-DOF toolpath with a positioner |
pick_and_place_c_api_example.py |
pick_and_place_example.cpp |
Pick, attach, place |
car_seat_c_api_example.py |
car_seat_example.cpp |
Seat meshes, attach, multi-phase planning |
descartes_raster_c_api_example.py |
motion_planners/examples/raster_example.cpp |
Descartes then TrajOpt, no task composer |
tesseract_planning_composer_c_api_example.py |
— | The task composer steps, one by one |
tesseract_planning_lowlevel_c_api_example.py |
— | Planners without the task composer |
pythonic_api_example.py (console module tesseract_robotics.examples.pythonic_api_example)
shows the same steps through tesseract_robotics.planning.