Kinematics
Forward kinematics maps joint values to link poses; inverse kinematics finds the joint values
that put a link at a pose. Both run on a kinematic group, a set of joints named in the SRDF
("manipulator"), with the solvers the SRDF's kinematics plugin configuration selects: KDL
(numerical), OPW and UR (closed form). robot.fk(...) and robot.ik(...) are the short form;
the kinematic group gives limits, Jacobians and every IK branch. Angles are rad, lengths m;
Frames and poses fixes the frame of each pose.
Kinematic groups
A kinematic group defines a chain of joints for FK/IK calculations:
<!-- In robot.srdf -->
<group name="manipulator">
  <chain base_link="base_link" tip_link="tool0"/>
</group>
Getting a kinematic group
from tesseract_robotics.planning import Robot

locator = GeneralResourceLocator(paths=[get_tesseract_resource_path()])  # the tesseract-robotics-nanobind-support wheel
robot = Robot.from_tesseract_support("abb_irb2400", locator)
manip = robot.env.getKinematicGroup("manipulator")

# Group info
print(f"Joint names:     {list(manip.getJointIds())}")
print(f"Link names:      {list(manip.getLinkIds())}")
print(f"Base link:       {manip.getBaseLinkId()}")
print(f"Tip link(s):     {list(manip.getAllPossibleTipLinkIds())}")
Forward kinematics
Compute a link's pose from joint values.
import numpy as np

joints = np.array([0.0, -0.5, 0.5, 0.0, 0.5, 0.0])

# group_name, joint positions, then the link whose pose you want
tcp_pose = robot.fk("manipulator", joints, "tool0")

print(f"Position:   ({tcp_pose.x}, {tcp_pose.y}, {tcp_pose.z})")
print(f"Quaternion: ({tcp_pose.qx}, {tcp_pose.qy}, {tcp_pose.qz}, {tcp_pose.qw})")
Quaternion convention — scalar-last project-wide
Project canonical quaternion order is [qx, qy, qz, qw] (scalar-last).
Pose.qx/qy/qz/qw, Pose.quaternion, Quaterniond.from_xyzw,
q.coeffs(), and every factory in common follow this.
There is no scalar-first constructor: build one with
Quaterniond.from_xyzw(qx, qy, qz, qw) or Quaterniond([qx, qy, qz, qw]).
Pose vs Isometry3d
Pose is a subclass of Isometry3d (see planning/transforms.py). Every Pose IS an Isometry3d, so any C++ binding that accepts Isometry3d accepts Pose directly — no conversion step.
from tesseract_robotics.planning import Pose
from tesseract_robotics.common import Isometry3d
import numpy as np

pose = Pose.from_xyz_rpy(0.5, 0.0, 0.3, 0, 0, np.pi / 4)
assert isinstance(pose, Isometry3d)   # subclass relationship

# Need a plain Isometry3d? Pass the Pose through the Isometry3d ctor.
iso = Isometry3d(pose)

# Wrap an existing Isometry3d as a Pose (gains the ergonomic factories +
# @-operator composition).
pose2 = Pose(iso)

# Composition (Pose uses Python's @ operator)
combined = pose @ pose2

# Low-level composition (Isometry3d uses *)
iso_combined = iso * iso
Inverse kinematics
Find joint values that achieve a target pose.
from tesseract_robotics.planning import Pose

target = Pose.from_xyz_rpy(0.6, 0.0, 0.5, 0.0, np.pi, 0.0)

from tesseract_robotics.planning import IKNoSolutionError

# Returns the first solution as an np.ndarray; raises IKNoSolutionError when there is none
try:
    solution = robot.ik("manipulator", target, "tool0", seed=joints)
    print(f"Solution: {solution}")
except IKNoSolutionError:
    print("No IK solution found")

# Enumerate all solutions (e.g. redundant 7-DOF arms)
solutions = robot.ik("manipulator", target, "tool0", seed=joints, all_solutions=True)
print(f"Found {len(solutions)} solution(s)")
The full signature is robot.ik(group_name, target_pose, tip_link, seed=None, all_solutions=False); tip_link is required — see planning/core.py.
from tesseract_robotics.kinematics import KinGroupIKInput

# Pose subclasses Isometry3d, so KinGroupIKInput accepts it directly.
working_frame = manip.getBaseLinkId()
tip_link = list(manip.getActiveLinkIds())[-1]

ik_input = KinGroupIKInput(target, working_frame, tip_link)
seed = np.zeros(6)
solutions = manip.calcInvKin(ik_input, seed)  # list[np.ndarray]
IK may raise IKNoSolutionError
robot.ik(...) raises IKNoSolutionError (a RuntimeError) when:
- the target is outside the workspace,
- no IK solver is configured in the SRDF,
- the solver hit its iteration limit.
A closed-form solver returns every branch:
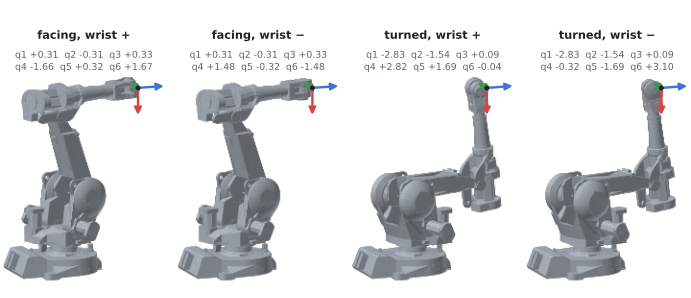
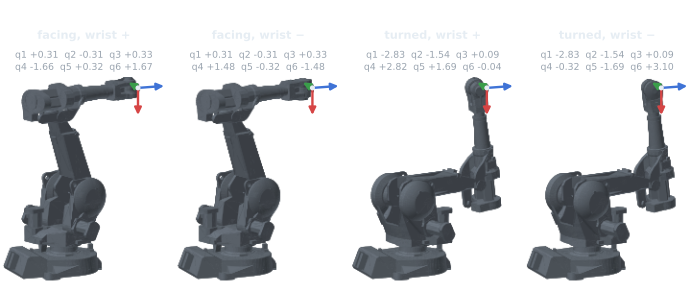
Robot.ik(..., all_solutions=True) returns every branch within the joint limits: four for this tool0 pose on the IRB2400 (0.7, 0.2, 1.4 m, tool z along +x), facing the target or turned half a revolution and leaning back, each with the wrist flipped or not. Joint values in rad; forward kinematics of each lands on the pose. Reproduce: pixi run docs-figures ik_branches.IK solvers
| Solver | Type | Robots |
|---|---|---|
| KDL | Numerical | Any serial chain |
| OPW | Analytical | 6-DOF industrial arms (ABB, KUKA, Fanuc) |
| UR | Analytical | Universal Robots |
Configure the solver in the SRDF:
<kinematics_plugin_config>
  <group name="manipulator">
    <plugin name="KDLInvKin"/>
  </group>
</kinematics_plugin_config>
Filtering IK solutions by configuration
An analytical solver returns one solution per arm configuration. getRobotConfig
classifies a six-axis solution by three letters: wrist **F**lipped or **N**ot (sign of
joint 5), elbow **U**p or D**own (joint 3 against π/2), and arm in fron**T of or
**B**ehind joint 1. Keep one family to get a consistent path, e.g. no wrist flip on an
ABB IRB2400:
import numpy as np
from tesseract_robotics.planning import Pose, Robot
from tesseract_robotics.kinematics import KinGroupIKInput
from tesseract_robotics.motion_planners import (
    RobotConfig,
    getJointTurns,
    getRobotConfig,
    isWithinJointLimits,
)

locator = GeneralResourceLocator(paths=[get_tesseract_resource_path()])  # the tesseract-robotics-nanobind-support wheel
robot = Robot.from_tesseract_support("abb_irb2400", locator)
manip = robot.env.getKinematicGroup("manipulator")

# tool0 pointing along +x of base_link
target = Pose.from_xyz_quat(0.8, 0.0, 1.0, 0.0, 0.70710678, 0.0, 0.70710678)
solutions = manip.calcInvKin(KinGroupIKInput(target, "base_link", "tool0"), np.zeros(6))

for q in solutions:
    config = getRobotConfig(manip, "base_link", "tool0", q)
    print(config.name, getJointTurns(q))   # FUT [ 0  0  0 -1  0 -1], NUT [0 0 0 0 0 0]

no_flip = [q for q in solutions if getRobotConfig(manip, "base_link", "tool0", q) == RobotConfig.NUT]

# Joint limits plus a joint-4 + joint-6 coupling window (for a dress pack, say).
limits = manip.getLimits().joint_limits
in_window = [q for q in no_flip if isWithinJointLimits(q, limits, np.array([-np.pi, np.pi]))]
getRobotConfig reads the last six joint values, so it works for an arm on a rail or
positioner too. Its sign_correction argument (default [1, 1]) flips the sign of
joint 3 and joint 5 for manufacturers whose joint directions differ from the convention.
getJointTurns gives int(q / π) per joint: non-zero where a wrist joint is more than
half a turn from zero.
Joint limits
limits = manip.getLimits()

# Position limits: 2-column matrix [lower, upper] per joint
pos_limits = limits.joint_limits
print(f"Joint 1: [{pos_limits[0, 0]}, {pos_limits[0, 1]}]")

# Velocity / acceleration limits (same shape)
vel_limits = limits.velocity_limits
acc_limits = limits.acceleration_limits
Robot.get_joint_limits("manipulator") returns the same information as a {joint_name: {lower, upper, velocity, acceleration}} dict.
Checking limits
def is_within_limits(joints: np.ndarray, manip) -> bool:
    limits = manip.getLimits()
    lower = limits.joint_limits[:, 0]
    upper = limits.joint_limits[:, 1]
    return bool(np.all(joints >= lower) and np.all(joints <= upper))
Sample grids and reach
The utilities the positioner solvers sample with are callable directly:
from tesseract_robotics import kinematics as tk

graph = env.getSceneGraph()
limits = tk.gatherJointLimits(graph, manip.getJointIds())  # (N, 2) [lower, upper]
grid = tk.buildSampleGrid(limits, np.full(len(limits), 0.1))
# grid[i]: ceil((hi - lo) / 0.1) + 1 evenly spaced values of joint i (not their product)

reach = tk.computeChainReachUpperBound(graph, "base_link", "tool0")  # metres
computeChainReachUpperBound sums the joint offsets along the chain (plus each prismatic
joint's largest |limit|), so it bounds the base-to-tip distance over every configuration.
PositionerSampleResolution(name, value, min=None, max=None) is the per-joint resolution record
of the REP / ROP solver configs; None bounds default to the joint's limits.
Jacobian
The Jacobian relates joint velocities to end-effector velocities:
# 6xN Jacobian matrix at the named link
jacobian = manip.calcJacobian(joints, "tool0")

joint_velocities = np.array([0.1, 0.1, 0.1, 0.1, 0.1, 0.1])
tcp_velocity = jacobian @ joint_velocities  # 6D twist [vx, vy, vz, wx, wy, wz]
Singularity detection
Two measures, both from the singular values σ of the Jacobian:
from tesseract_robotics.kinematics import (
    calcManipulability, calcManipulabilityVolume, calcManipulabilityVolume_each,
    isNearSingularity,
)

near = isNearSingularity(jacobian)             # smallest σ < 0.01 (threshold=...)
w = calcManipulabilityVolume(jacobian)         # Yoshikawa manipulability: the product of all six σ
ellipsoids = calcManipulability(jacobian)      # the velocity and force ellipsoids, whole, linear and angular
assert w == ellipsoids.m.volume

# Along a path: one call for the (M, 6, n) stack, with the GIL released
waypoints = np.linspace(joints, joints + 0.2, 5)
volumes = calcManipulabilityVolume_each(
    np.stack([manip.calcJacobian(q, "tool0") for q in waypoints])
)
isNearSingularity answers "is one direction of motion nearly lost?"; the manipulability
falls smoothly towards 0 as a singularity approaches, which makes it the one to plot along a
path or to bound in an optimization. Its value depends on the robot and the length unit, so
compare it between configurations of one robot.
Use these instead of np.sqrt(np.linalg.det(J @ J.T)): forming J·Jᵀ squares the condition
number, so a singular value below about 1.5e-8 of the largest (√ε) is lost in rounding and a
near-singular configuration cannot be told from a singular one. A Jacobian with a NaN or infinite entry raises
NonFiniteJacobianError instead of reading as a singularity. The definitions, the rank rule and
the errors are in the API reference.
Tool frames
Define Tool Center Point (TCP) offsets relative to the flange:
from tesseract_robotics.planning import Pose

# Gripper extends 15 cm from the flange
tool_offset = Pose.from_xyz(0.0, 0.0, 0.15)

# FK to flange, then apply the tool offset
flange_pose = robot.fk("manipulator", joints, "tool0")
tcp_pose = flange_pose @ tool_offset

# For IK, transform the target back into the flange frame
target_tcp = tcp_pose
target_flange = target_tcp @ tool_offset.inverse()
solution = robot.ik("manipulator", target_flange, "tool0")
fk and ik work on links only. For planning, pass the offset to the MotionProgram
instead (tcp_offset=tool_offset, or the name of an SRDF group TCP) and the planner applies
it: see Frames and the TCP.
Working with multiple groups
Some robots have multiple kinematic groups:
# Dual-arm robot (the IRB2400 has one group, "manipulator")
left_arm  = robot.env.getKinematicGroup("left_arm")
right_arm = robot.env.getKinematicGroup("right_arm")

# Manipulator + external positioner
full_chain = robot.env.getKinematicGroup("manipulator_with_positioner")
Performance tips
Cache kinematic groups
Creating a kinematic group walks the SRDF. Cache the group if you're looping over many configurations:
Prefer analytical IK when available
OPW is dramatically faster than KDL for supported 6-DOF arms. Configure it in your SRDF for production workloads.
IK runs without the GIL
calcInvKin (on KinematicGroup and InverseKinematics) releases the GIL,
so IK on worker threads runs in parallel. calcFwdKin and
getKinematicGroup hold it. See
Threading and the GIL.
Next steps
- Collision Detection — Check for collisions against the world
- Motion Planning — Plan collision-free trajectories