 |
Tesseract 0.28.4
|
|
Tesseract 0.28.4
|
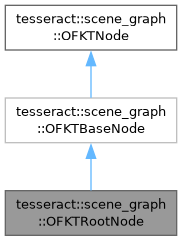
Public Member Functions | |
| EIGEN_MAKE_ALIGNED_OPERATOR_NEW | OFKTRootNode (tesseract::common::LinkId link_id) |
| This should only be used for the root node of the tree. | |
| void | setParent (OFKTNode *parent) override |
| Set the parent node. | |
| void | storeJointValue (double joint_value) override |
| Set the nodes joint value if it has one. | |
| void | setStaticTransformation (const Eigen::Isometry3d &static_tf) override |
| Set the static transformation. | |
| void | computeAndStoreLocalTransformation () override |
| Compute and save the local transformation 'L = S * J(Joint Value)'. | |
| void | computeAndStoreWorldTransformation () override |
| Compute and store the nodes world transformation. | |
| bool | updateWorldTransformationRequired () const override |
| Indicates if an update of the world transformation is required. | |
| Eigen::Isometry3d | computeLocalTransformation (double joint_value) const override |
| Compute the local tranformation but do not save. | |
| Public Member Functions inherited from tesseract::scene_graph::OFKTBaseNode | |
| EIGEN_MAKE_ALIGNED_OPERATOR_NEW | OFKTBaseNode (JointType type, OFKTNode *parent, tesseract::common::LinkId link_id) |
| OFKTBaseNode (JointType type, OFKTNode *parent, tesseract::common::LinkId link_id, tesseract::common::JointId joint_id, const Eigen::Isometry3d &static_tf) | |
| JointType | getType () const override |
| Get the type of joint associated with the node. | |
| OFKTNode * | getParent () override |
| Get the parent node. | |
| const OFKTNode * | getParent () const override |
| Get the parent node (const). | |
| tesseract::common::LinkId | getLinkId () const override |
| Get the link ID associated with the node. | |
| tesseract::common::JointId | getJointId () const override |
| Get the joint ID associated with the node. | |
| double | getJointValue () const override |
| Get the current joint value. | |
| bool | hasJointValueChanged () const override |
| Indicates that the joint value has changed and that local and world transformation need to be recomputed. | |
| const Eigen::Isometry3d & | getStaticTransformation () const override |
| Get the nodes static transformation. | |
| const Eigen::Isometry3d & | getLocalTransformation () const override |
| Get the local transformation: 'L = S * J'. | |
| const Eigen::Isometry3d & | getWorldTransformation () const override |
| Get the nodes world transformation. | |
| Eigen::Matrix< double, 6, 1 > | getLocalTwist () const override |
| Return the twist of the node's link relative to its parent link for a unit joint velocity. | |
| void | addChild (OFKTNode *node) override |
| Add a child node. | |
| void | removeChild (const OFKTNode *node) override |
| Remove a child node assiciated with this node. | |
| std::vector< OFKTNode * > & | getChildren () override |
| Get a vector of child nodes associated with this node. | |
| const std::vector< const OFKTNode * > & | getChildren () const override |
| Get a vector of child nodes associated with this node (Const). | |
| Public Member Functions inherited from tesseract::scene_graph::OFKTNode | |
| OFKTNode (const OFKTNode &)=delete | |
| OFKTNode & | operator= (const OFKTNode &)=delete |
| OFKTNode (OFKTNode &&)=delete | |
| OFKTNode & | operator= (OFKTNode &&)=delete |
Friends | |
| class | OFKTStateSolver |
Additional Inherited Members | |
| Public Types inherited from tesseract::scene_graph::OFKTNode | |
| using | UPtr = std::unique_ptr<OFKTNode> |
| using | Ptr = std::shared_ptr<OFKTNode> |
| using | ConstPtr = std::shared_ptr<const OFKTNode> |
| Protected Attributes inherited from tesseract::scene_graph::OFKTBaseNode | |
| tesseract::scene_graph::JointType | type_ |
| OFKTNode * | parent_ { nullptr } |
| tesseract::common::LinkId | link_id_ |
| tesseract::common::JointId | joint_id_ |
| Eigen::Isometry3d | static_tf_ { Eigen::Isometry3d::Identity() } |
| Eigen::Isometry3d | joint_tf_ { Eigen::Isometry3d::Identity() } |
| Eigen::Isometry3d | local_tf_ { Eigen::Isometry3d::Identity() } |
| Eigen::Isometry3d | world_tf_ { Eigen::Isometry3d::Identity() } |
| Eigen::Matrix< double, 6, 1 > | local_twist_ { Eigen::VectorXd::Zero(6) } |
| double | joint_value_ { 0 } |
| bool | joint_value_changed_ { false } |
| std::vector< OFKTNode * > | children_ |
| std::vector< const OFKTNode * > | children_const_ |
| bool | update_world_required_ { true } |
| tesseract::scene_graph::OFKTRootNode::OFKTRootNode | ( | tesseract::common::LinkId | link_id | ) |
This should only be used for the root node of the tree.
| link_id | The link ID associated with the node |
|
overridevirtual |
Set the parent node.
This should indicate that updateWorldTransformationRequired() = true
| parent | The parent node |
Reimplemented from tesseract::scene_graph::OFKTBaseNode.
|
overridevirtual |
Set the nodes joint value if it has one.
This should indicate hasJointValueChanged() = true
| joint_value | The joint value |
Reimplemented from tesseract::scene_graph::OFKTBaseNode.
|
overridevirtual |
Set the static transformation.
This should recompute the local transformation and updateWorldTransformationRequired() = true.
| static_tf | The new static transformation |
Reimplemented from tesseract::scene_graph::OFKTBaseNode.
|
overridevirtual |
Compute and save the local transformation 'L = S * J(Joint Value)'.
This should reset the flag such that hasJointValueChanged() returns false
Implements tesseract::scene_graph::OFKTNode.
|
overridevirtual |
Compute and store the nodes world transformation.
This should reset the flag such that updateWorldTransformationRequired() returns false
Reimplemented from tesseract::scene_graph::OFKTBaseNode.
|
overridevirtual |
Indicates if an update of the world transformation is required.
This should get set to true when either of the following happen.
Note: setJointValue() is not handle here because that is captured by hasJointValueChanged()
Reimplemented from tesseract::scene_graph::OFKTBaseNode.
|
overridevirtual |
Compute the local tranformation but do not save.
This provides a const method for computing the local transform.
| joint_value | The joint value for calculating the local transformation |
Reimplemented from tesseract::scene_graph::OFKTBaseNode.
 1.15.0