 |
Tesseract 0.28.4
|
|
Tesseract 0.28.4
|
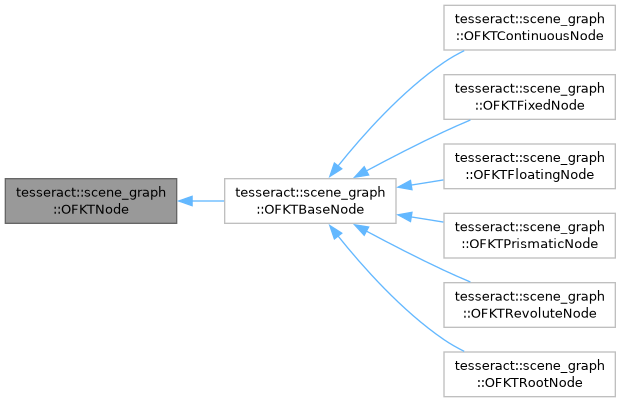
The OFKT node is contains multiple trasformation which are described below. More...
#include <ofkt_node.h>
Public Types | |
| using | UPtr = std::unique_ptr<OFKTNode> |
| using | Ptr = std::shared_ptr<OFKTNode> |
| using | ConstPtr = std::shared_ptr<const OFKTNode> |
Public Member Functions | |
| OFKTNode (const OFKTNode &)=delete | |
| OFKTNode & | operator= (const OFKTNode &)=delete |
| OFKTNode (OFKTNode &&)=delete | |
| OFKTNode & | operator= (OFKTNode &&)=delete |
| virtual JointType | getType () const =0 |
| Get the type of joint associated with the node. | |
| virtual void | setParent (OFKTNode *parent)=0 |
| Set the parent node. | |
| virtual OFKTNode * | getParent ()=0 |
| Get the parent node. | |
| virtual const OFKTNode * | getParent () const =0 |
| Get the parent node (const). | |
| virtual tesseract::common::LinkId | getLinkId () const =0 |
| Get the link ID associated with the node. | |
| virtual tesseract::common::JointId | getJointId () const =0 |
| Get the joint ID associated with the node. | |
| virtual void | storeJointValue (double joint_value)=0 |
| Set the nodes joint value if it has one. | |
| virtual double | getJointValue () const =0 |
| Get the current joint value. | |
| virtual bool | hasJointValueChanged () const =0 |
| Indicates that the joint value has changed and that local and world transformation need to be recomputed. | |
| virtual void | setStaticTransformation (const Eigen::Isometry3d &static_tf)=0 |
| Set the static transformation. | |
| virtual const Eigen::Isometry3d & | getStaticTransformation () const =0 |
| Get the nodes static transformation. | |
| virtual void | computeAndStoreLocalTransformation ()=0 |
| Compute and save the local transformation 'L = S * J(Joint Value)'. | |
| virtual const Eigen::Isometry3d & | getLocalTransformation () const =0 |
| Get the local transformation: 'L = S * J'. | |
| virtual Eigen::Isometry3d | computeLocalTransformation (double joint_value) const =0 |
| Compute the local tranformation but do not save. | |
| virtual void | computeAndStoreWorldTransformation ()=0 |
| Compute and store the nodes world transformation. | |
| virtual const Eigen::Isometry3d & | getWorldTransformation () const =0 |
| Get the nodes world transformation. | |
| virtual bool | updateWorldTransformationRequired () const =0 |
| Indicates if an update of the world transformation is required. | |
| virtual Eigen::Matrix< double, 6, 1 > | getLocalTwist () const =0 |
| Return the twist of the node's link relative to its parent link for a unit joint velocity. | |
| virtual void | addChild (OFKTNode *node)=0 |
| Add a child node. | |
| virtual void | removeChild (const OFKTNode *node)=0 |
| Remove a child node assiciated with this node. | |
| virtual std::vector< OFKTNode * > & | getChildren ()=0 |
| Get a vector of child nodes associated with this node. | |
| virtual const std::vector< const OFKTNode * > & | getChildren () const =0 |
| Get a vector of child nodes associated with this node (Const). | |
The OFKT node is contains multiple trasformation which are described below.
|
pure virtual |
Get the type of joint associated with the node.
Implemented in tesseract::scene_graph::OFKTBaseNode.
|
pure virtual |
Set the parent node.
This should indicate that updateWorldTransformationRequired() = true
| parent | The parent node |
Implemented in tesseract::scene_graph::OFKTBaseNode, and tesseract::scene_graph::OFKTRootNode.
|
pure virtual |
|
pure virtual |
Get the parent node (const).
Implemented in tesseract::scene_graph::OFKTBaseNode.
|
pure virtual |
Get the link ID associated with the node.
Implemented in tesseract::scene_graph::OFKTBaseNode.
|
pure virtual |
Get the joint ID associated with the node.
Implemented in tesseract::scene_graph::OFKTBaseNode.
|
pure virtual |
Set the nodes joint value if it has one.
This should indicate hasJointValueChanged() = true
| joint_value | The joint value |
Implemented in tesseract::scene_graph::OFKTBaseNode, tesseract::scene_graph::OFKTFixedNode, tesseract::scene_graph::OFKTFloatingNode, tesseract::scene_graph::OFKTRevoluteNode, and tesseract::scene_graph::OFKTRootNode.
|
pure virtual |
Get the current joint value.
Implemented in tesseract::scene_graph::OFKTBaseNode, tesseract::scene_graph::OFKTFixedNode, and tesseract::scene_graph::OFKTFloatingNode.
|
pure virtual |
Indicates that the joint value has changed and that local and world transformation need to be recomputed.
Implemented in tesseract::scene_graph::OFKTBaseNode.
|
pure virtual |
Set the static transformation.
This should recompute the local transformation and updateWorldTransformationRequired() = true.
| static_tf | The new static transformation |
Implemented in tesseract::scene_graph::OFKTBaseNode, tesseract::scene_graph::OFKTFixedNode, tesseract::scene_graph::OFKTFloatingNode, and tesseract::scene_graph::OFKTRootNode.
|
pure virtual |
Get the nodes static transformation.
Implemented in tesseract::scene_graph::OFKTBaseNode.
|
pure virtual |
Compute and save the local transformation 'L = S * J(Joint Value)'.
This should reset the flag such that hasJointValueChanged() returns false
Implemented in tesseract::scene_graph::OFKTContinuousNode, tesseract::scene_graph::OFKTFixedNode, tesseract::scene_graph::OFKTFloatingNode, tesseract::scene_graph::OFKTPrismaticNode, tesseract::scene_graph::OFKTRevoluteNode, and tesseract::scene_graph::OFKTRootNode.
|
pure virtual |
Get the local transformation: 'L = S * J'.
Implemented in tesseract::scene_graph::OFKTBaseNode.
|
pure virtual |
Compute the local tranformation but do not save.
This provides a const method for computing the local transform.
| joint_value | The joint value for calculating the local transformation |
Implemented in tesseract::scene_graph::OFKTBaseNode, tesseract::scene_graph::OFKTContinuousNode, tesseract::scene_graph::OFKTFixedNode, tesseract::scene_graph::OFKTFloatingNode, tesseract::scene_graph::OFKTPrismaticNode, tesseract::scene_graph::OFKTRevoluteNode, and tesseract::scene_graph::OFKTRootNode.
|
pure virtual |
Compute and store the nodes world transformation.
This should reset the flag such that updateWorldTransformationRequired() returns false
Implemented in tesseract::scene_graph::OFKTBaseNode, and tesseract::scene_graph::OFKTRootNode.
|
pure virtual |
Get the nodes world transformation.
Implemented in tesseract::scene_graph::OFKTBaseNode.
|
pure virtual |
Indicates if an update of the world transformation is required.
This should get set to true when either of the following happen.
Note: setJointValue() is not handle here because that is captured by hasJointValueChanged()
Implemented in tesseract::scene_graph::OFKTBaseNode, and tesseract::scene_graph::OFKTRootNode.
|
pure virtual |
Return the twist of the node's link relative to its parent link for a unit joint velocity.
It is expressed in the frame of the node's link, with the origin of that link as the reference point, so it does not depend on the joint value or on the joint origin. It is zero for a node without a joint value.
Implemented in tesseract::scene_graph::OFKTBaseNode.
|
pure virtual |
Add a child node.
| node | The node which is a child of this node |
Implemented in tesseract::scene_graph::OFKTBaseNode.
|
pure virtual |
Remove a child node assiciated with this node.
| node | The child node to be removed |
Implemented in tesseract::scene_graph::OFKTBaseNode.
|
pure virtual |
Get a vector of child nodes associated with this node.
Implemented in tesseract::scene_graph::OFKTBaseNode.
|
pure virtual |
Get a vector of child nodes associated with this node (Const).
Implemented in tesseract::scene_graph::OFKTBaseNode.
 1.15.0