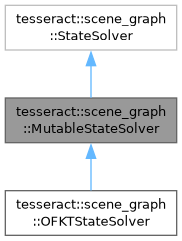
A mutable state solver allows you to reconfigure the solver's links and joints.
More...
|
|
| MutableStateSolver (const MutableStateSolver &)=default |
|
MutableStateSolver & | operator= (const MutableStateSolver &)=default |
|
| MutableStateSolver (MutableStateSolver &&)=default |
|
MutableStateSolver & | operator= (MutableStateSolver &&)=default |
| virtual void | setRevision (int revision)=0 |
| | Set the state solver revision number.
|
| virtual int | getRevision () const =0 |
| | Get the state solver revision number.
|
| virtual bool | addLink (const Link &link, const Joint &joint)=0 |
| | Adds a link/joint to the solver.
|
| virtual bool | moveLink (const Joint &joint)=0 |
| | Move a link.
|
| virtual bool | removeLink (const tesseract::common::LinkId &link_id)=0 |
| | Removes a link from the graph.
|
| virtual bool | replaceJoint (const Joint &joint)=0 |
| | Replace and existing joint with the provided one.
|
| virtual bool | removeJoint (const tesseract::common::JointId &joint_id)=0 |
| | Removes a joint from the graph.
|
| virtual bool | moveJoint (const tesseract::common::JointId &joint_id, const tesseract::common::LinkId &parent_link_id)=0 |
| | Move joint to new parent link.
|
| virtual bool | changeJointOrigin (const tesseract::common::JointId &joint_id, const Eigen::Isometry3d &new_origin)=0 |
| | Changes the "origin" transform of the joint and recomputes the associated edge.
|
| virtual bool | changeJointPositionLimits (const tesseract::common::JointId &joint_id, double lower, double upper)=0 |
| | Changes the position limits associated with a joint.
|
| virtual bool | changeJointVelocityLimits (const tesseract::common::JointId &joint_id, double limit)=0 |
| | Changes the velocity limits associated with a joint.
|
| virtual bool | changeJointAccelerationLimits (const tesseract::common::JointId &joint_id, double limit)=0 |
| | Changes the acceleration limits associated with a joint.
|
| virtual bool | changeJointJerkLimits (const tesseract::common::JointId &joint_id, double limit)=0 |
| | Changes the jerk limits associated with a joint.
|
| virtual bool | insertSceneGraph (const SceneGraph &scene_graph, const Joint &joint, const std::string &prefix="")=0 |
| | Merge a scene into the current solver.
|
|
| StateSolver (const StateSolver &)=default |
|
StateSolver & | operator= (const StateSolver &)=default |
|
| StateSolver (StateSolver &&)=default |
|
StateSolver & | operator= (StateSolver &&)=default |
| virtual StateSolver::UPtr | clone () const =0 |
| | This should clone the object so it may be used in a multi threaded application where each thread would clone the solver.
|
| virtual void | setState (const Eigen::Ref< const Eigen::VectorXd > &joint_values, const tesseract::common::JointIdTransformMap &floating_joint_values={})=0 |
| | Set the current state of the solver.
|
| virtual void | setState (const tesseract::common::JointIdTransformMap &floating_joint_values)=0 |
| | Set the current state of the floating joint values.
|
| virtual void | setState (const SceneState::JointValues &joint_values, const tesseract::common::JointIdTransformMap &floating_joint_values={})=0 |
| | Set the current state using a JointId-keyed map.
|
| virtual void | setState (const std::vector< tesseract::common::JointId > &joint_ids, const Eigen::Ref< const Eigen::VectorXd > &joint_values, const tesseract::common::JointIdTransformMap &floating_joint_values={})=0 |
| | Set the current state using a vector of JointIds.
|
| virtual SceneState | getState (const Eigen::Ref< const Eigen::VectorXd > &joint_values, const tesseract::common::JointIdTransformMap &floating_joint_values={}) const =0 |
| | Get the state of the solver given the joint values.
|
| virtual SceneState | getState (const tesseract::common::JointIdTransformMap &floating_joint_values) const =0 |
| | Get the state given floating joint values.
|
| virtual SceneState | getState (const SceneState::JointValues &joint_values, const tesseract::common::JointIdTransformMap &floating_joint_values={}) const =0 |
| | Get the state using a JointId-keyed map.
|
| virtual SceneState | getState (const std::vector< tesseract::common::JointId > &joint_ids, const Eigen::Ref< const Eigen::VectorXd > &joint_values, const tesseract::common::JointIdTransformMap &floating_joint_values={}) const =0 |
| | Get the state using a vector of JointIds.
|
| virtual void | getLinkTransforms (tesseract::common::LinkIdTransformMap &link_transforms, const std::vector< tesseract::common::JointId > &joint_ids, const Eigen::Ref< const Eigen::VectorXd > &joint_values, const tesseract::common::JointIdTransformMap &floating_joint_values) const =0 |
| | Get the link transforms of the scene for a given set or subset of joint values.
|
| virtual void | getLinkTransforms (tesseract::common::LinkIdTransformMap &link_transforms, const std::vector< tesseract::common::JointId > &joint_ids, const Eigen::Ref< const Eigen::VectorXd > &joint_values) const =0 |
| | Get link transforms without applying floating joint values.
|
| virtual SceneState | getState () const =0 |
| | Get the current state of the scene.
|
| virtual Eigen::MatrixXd | getJacobian (const Eigen::Ref< const Eigen::VectorXd > &joint_values, const tesseract::common::LinkId &link_id, const tesseract::common::JointIdTransformMap &floating_joint_values={}) const =0 |
| | Get the jacobian for a link identified by LinkId.
|
| virtual Eigen::MatrixXd | getJacobian (const std::vector< tesseract::common::JointId > &joint_ids, const Eigen::Ref< const Eigen::VectorXd > &joint_values, const tesseract::common::LinkId &link_id, const tesseract::common::JointIdTransformMap &floating_joint_values={}) const =0 |
| | Get the jacobian for a given set or subset of joint IDs.
|
| virtual SceneState | getRandomState () const =0 |
| | Get the random state of the environment.
|
| virtual std::vector< tesseract::common::JointId > | getJointIds () const =0 |
| | Get the vector of joint IDs.
|
| virtual std::vector< tesseract::common::JointId > | getFloatingJointIds () const =0 |
| | Get the vector of floating joint IDs.
|
| virtual std::vector< tesseract::common::JointId > | getActiveJointIds () const =0 |
| | Get the vector of active joint IDs which align with the limits.
|
| virtual tesseract::common::LinkId | getBaseLinkId () const =0 |
| | Get the base link ID.
|
| virtual std::vector< tesseract::common::LinkId > | getLinkIds () const =0 |
| | Get the vector of link IDs.
|
| virtual std::vector< tesseract::common::LinkId > | getActiveLinkIds () const =0 |
| | Get the vector of active link IDs.
|
| virtual std::vector< tesseract::common::LinkId > | getStaticLinkIds () const =0 |
| | Get a vector of static link IDs.
|
| virtual bool | isActiveLinkId (const tesseract::common::LinkId &link_id) const =0 |
| | Check if link is an active link.
|
| virtual bool | hasLinkId (const tesseract::common::LinkId &link_id) const =0 |
| | Check if link id exists.
|
| virtual tesseract::common::VectorIsometry3d | getLinkTransforms () const =0 |
| | Get all of the links transforms.
|
| virtual Eigen::Isometry3d | getLinkTransform (const tesseract::common::LinkId &link_id) const =0 |
| | Get the transform corresponding to the link.
|
| virtual Eigen::Isometry3d | getRelativeLinkTransform (const tesseract::common::LinkId &from_link_id, const tesseract::common::LinkId &to_link_id) const =0 |
| | Get transform between two links using the current state.
|
| virtual tesseract::common::KinematicLimits | getLimits () const =0 |
| | Getter for kinematic limits.
|
A mutable state solver allows you to reconfigure the solver's links and joints.

 1.15.0