 |
Tesseract 0.28.4
|
|
Tesseract 0.28.4
|
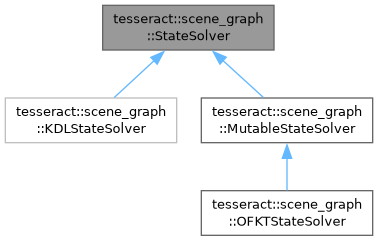
Public Member Functions | |
| StateSolver (const StateSolver &)=default | |
| StateSolver & | operator= (const StateSolver &)=default |
| StateSolver (StateSolver &&)=default | |
| StateSolver & | operator= (StateSolver &&)=default |
| virtual StateSolver::UPtr | clone () const =0 |
| This should clone the object so it may be used in a multi threaded application where each thread would clone the solver. | |
| virtual void | setState (const Eigen::Ref< const Eigen::VectorXd > &joint_values, const tesseract::common::JointIdTransformMap &floating_joint_values={})=0 |
| Set the current state of the solver. | |
| virtual void | setState (const tesseract::common::JointIdTransformMap &floating_joint_values)=0 |
| Set the current state of the floating joint values. | |
| virtual void | setState (const SceneState::JointValues &joint_values, const tesseract::common::JointIdTransformMap &floating_joint_values={})=0 |
| Set the current state using a JointId-keyed map. | |
| virtual void | setState (const std::vector< tesseract::common::JointId > &joint_ids, const Eigen::Ref< const Eigen::VectorXd > &joint_values, const tesseract::common::JointIdTransformMap &floating_joint_values={})=0 |
| Set the current state using a vector of JointIds. | |
| virtual SceneState | getState (const Eigen::Ref< const Eigen::VectorXd > &joint_values, const tesseract::common::JointIdTransformMap &floating_joint_values={}) const =0 |
| Get the state of the solver given the joint values. | |
| virtual SceneState | getState (const tesseract::common::JointIdTransformMap &floating_joint_values) const =0 |
| Get the state given floating joint values. | |
| virtual SceneState | getState (const SceneState::JointValues &joint_values, const tesseract::common::JointIdTransformMap &floating_joint_values={}) const =0 |
| Get the state using a JointId-keyed map. | |
| virtual SceneState | getState (const std::vector< tesseract::common::JointId > &joint_ids, const Eigen::Ref< const Eigen::VectorXd > &joint_values, const tesseract::common::JointIdTransformMap &floating_joint_values={}) const =0 |
| Get the state using a vector of JointIds. | |
| virtual void | getLinkTransforms (tesseract::common::LinkIdTransformMap &link_transforms, const std::vector< tesseract::common::JointId > &joint_ids, const Eigen::Ref< const Eigen::VectorXd > &joint_values, const tesseract::common::JointIdTransformMap &floating_joint_values) const =0 |
| Get the link transforms of the scene for a given set or subset of joint values. | |
| virtual void | getLinkTransforms (tesseract::common::LinkIdTransformMap &link_transforms, const std::vector< tesseract::common::JointId > &joint_ids, const Eigen::Ref< const Eigen::VectorXd > &joint_values) const =0 |
| Get link transforms without applying floating joint values. | |
| virtual SceneState | getState () const =0 |
| Get the current state of the scene. | |
| virtual Eigen::MatrixXd | getJacobian (const Eigen::Ref< const Eigen::VectorXd > &joint_values, const tesseract::common::LinkId &link_id, const tesseract::common::JointIdTransformMap &floating_joint_values={}) const =0 |
| Get the jacobian for a link identified by LinkId. | |
| virtual Eigen::MatrixXd | getJacobian (const std::vector< tesseract::common::JointId > &joint_ids, const Eigen::Ref< const Eigen::VectorXd > &joint_values, const tesseract::common::LinkId &link_id, const tesseract::common::JointIdTransformMap &floating_joint_values={}) const =0 |
| Get the jacobian for a given set or subset of joint IDs. | |
| virtual SceneState | getRandomState () const =0 |
| Get the random state of the environment. | |
| virtual std::vector< tesseract::common::JointId > | getJointIds () const =0 |
| Get the vector of joint IDs. | |
| virtual std::vector< tesseract::common::JointId > | getFloatingJointIds () const =0 |
| Get the vector of floating joint IDs. | |
| virtual std::vector< tesseract::common::JointId > | getActiveJointIds () const =0 |
| Get the vector of active joint IDs which align with the limits. | |
| virtual tesseract::common::LinkId | getBaseLinkId () const =0 |
| Get the base link ID. | |
| virtual std::vector< tesseract::common::LinkId > | getLinkIds () const =0 |
| Get the vector of link IDs. | |
| virtual std::vector< tesseract::common::LinkId > | getActiveLinkIds () const =0 |
| Get the vector of active link IDs. | |
| virtual std::vector< tesseract::common::LinkId > | getStaticLinkIds () const =0 |
| Get a vector of static link IDs. | |
| virtual bool | isActiveLinkId (const tesseract::common::LinkId &link_id) const =0 |
| Check if link is an active link. | |
| virtual bool | hasLinkId (const tesseract::common::LinkId &link_id) const =0 |
| Check if link id exists. | |
| virtual tesseract::common::VectorIsometry3d | getLinkTransforms () const =0 |
| Get all of the links transforms. | |
| virtual Eigen::Isometry3d | getLinkTransform (const tesseract::common::LinkId &link_id) const =0 |
| Get the transform corresponding to the link. | |
| virtual Eigen::Isometry3d | getRelativeLinkTransform (const tesseract::common::LinkId &from_link_id, const tesseract::common::LinkId &to_link_id) const =0 |
| Get transform between two links using the current state. | |
| virtual tesseract::common::KinematicLimits | getLimits () const =0 |
| Getter for kinematic limits. | |
|
pure virtual |
This should clone the object so it may be used in a multi threaded application where each thread would clone the solver.
Implemented in tesseract::scene_graph::KDLStateSolver, and tesseract::scene_graph::OFKTStateSolver.
|
pure virtual |
Set the current state of the solver.
This must be the same size and order as what is returned by getJointIds
| joint_values | The joint values |
Implemented in tesseract::scene_graph::KDLStateSolver, and tesseract::scene_graph::OFKTStateSolver.
|
pure virtual |
Set the current state of the floating joint values.
| floating_joint_values | The floating joint values to set |
Implemented in tesseract::scene_graph::KDLStateSolver, and tesseract::scene_graph::OFKTStateSolver.
|
pure virtual |
Set the current state using a JointId-keyed map.
Implemented in tesseract::scene_graph::KDLStateSolver, and tesseract::scene_graph::OFKTStateSolver.
|
pure virtual |
Set the current state using a vector of JointIds.
Implemented in tesseract::scene_graph::KDLStateSolver, and tesseract::scene_graph::OFKTStateSolver.
|
pure virtual |
Get the state of the solver given the joint values.
This must be the same size and order as what is returned by getJointIds
| joint_values | The joint values |
| floating_joint_values | The floating joint origin transform |
Implemented in tesseract::scene_graph::KDLStateSolver, and tesseract::scene_graph::OFKTStateSolver.
|
pure virtual |
Get the state given floating joint values.
| floating_joint_values | The floating joint values to leverage |
Implemented in tesseract::scene_graph::KDLStateSolver, and tesseract::scene_graph::OFKTStateSolver.
|
pure virtual |
Get the state using a JointId-keyed map.
This does not change the internal state of the solver.
Implemented in tesseract::scene_graph::KDLStateSolver, and tesseract::scene_graph::OFKTStateSolver.
|
pure virtual |
Get the state using a vector of JointIds.
Implemented in tesseract::scene_graph::KDLStateSolver, and tesseract::scene_graph::OFKTStateSolver.
|
pure virtual |
Get the link transforms of the scene for a given set or subset of joint values.
This is provided to optimize motion planning where link_transforms are poplated multiple time
This does not change the internal state of the solver.
This overwrites the transform of every link in the solver's tree but does not clear link_transforms first; keys from a different tree persist. Reusing a scratch map without clearing is safe iff every key later read is a link of this solver.
| link_transforms | The link_transforms to populate with data. |
| joint_ids | A list of joint IDs to change. |
| joint_values | The joint values |
| floating_joint_values | The floating joint origin transform |
Implemented in tesseract::scene_graph::KDLStateSolver, and tesseract::scene_graph::OFKTStateSolver.
|
pure virtual |
Get link transforms without applying floating joint values.
This is provided to optimize motion planning where link_transforms are poplated multiple time
This does not change the internal state of the solver.
This overwrites the transform of every link in the solver's tree but does not clear link_transforms first; keys from a different tree persist. Reusing a scratch map without clearing is safe iff every key later read is a link of this solver.
| link_transforms | The link_transforms to populate with data. |
| joint_ids | A list of joint IDs to change. |
| joint_values | The joint values |
Implemented in tesseract::scene_graph::KDLStateSolver, and tesseract::scene_graph::OFKTStateSolver.
|
pure virtual |
Get the current state of the scene.
Implemented in tesseract::scene_graph::KDLStateSolver, and tesseract::scene_graph::OFKTStateSolver.
|
pure virtual |
Get the jacobian for a link identified by LinkId.
This must be the same size and order as what is returned by getJointIds
| joint_values | The joint values |
| link_id | The link ID to calculate the jacobian for |
| floating_joint_values | The floating joint origin transform |
Implemented in tesseract::scene_graph::KDLStateSolver, and tesseract::scene_graph::OFKTStateSolver.
|
pure virtual |
Get the jacobian for a given set or subset of joint IDs.
This does not change the internal state of the solver.
| joint_ids | A list of joint IDs to change. |
| joint_values | The joint values |
| link_id | The link ID to calculate the jacobian for |
| floating_joint_values | The floating joint origin transform |
Implemented in tesseract::scene_graph::KDLStateSolver, and tesseract::scene_graph::OFKTStateSolver.
|
pure virtual |
Get the random state of the environment.
Implemented in tesseract::scene_graph::KDLStateSolver, and tesseract::scene_graph::OFKTStateSolver.
|
pure virtual |
Get the vector of joint IDs.
Implemented in tesseract::scene_graph::KDLStateSolver, and tesseract::scene_graph::OFKTStateSolver.
|
pure virtual |
Get the vector of floating joint IDs.
Implemented in tesseract::scene_graph::KDLStateSolver, and tesseract::scene_graph::OFKTStateSolver.
|
pure virtual |
Get the vector of active joint IDs which align with the limits.
Implemented in tesseract::scene_graph::KDLStateSolver, and tesseract::scene_graph::OFKTStateSolver.
|
pure virtual |
Get the base link ID.
Implemented in tesseract::scene_graph::KDLStateSolver, and tesseract::scene_graph::OFKTStateSolver.
|
pure virtual |
Get the vector of link IDs.
Implemented in tesseract::scene_graph::KDLStateSolver, and tesseract::scene_graph::OFKTStateSolver.
|
pure virtual |
Get the vector of active link IDs.
Implemented in tesseract::scene_graph::KDLStateSolver, and tesseract::scene_graph::OFKTStateSolver.
|
pure virtual |
Get a vector of static link IDs.
Implemented in tesseract::scene_graph::KDLStateSolver, and tesseract::scene_graph::OFKTStateSolver.
|
pure virtual |
Check if link is an active link.
| link_id | The link id to check |
Implemented in tesseract::scene_graph::KDLStateSolver, and tesseract::scene_graph::OFKTStateSolver.
|
pure virtual |
Check if link id exists.
| link_id | The link id to check for |
Implemented in tesseract::scene_graph::KDLStateSolver, and tesseract::scene_graph::OFKTStateSolver.
|
pure virtual |
Get all of the links transforms.
Order should be the same as getLinkIds()
Implemented in tesseract::scene_graph::KDLStateSolver, and tesseract::scene_graph::OFKTStateSolver.
|
pure virtual |
Get the transform corresponding to the link.
Implemented in tesseract::scene_graph::KDLStateSolver, and tesseract::scene_graph::OFKTStateSolver.
|
pure virtual |
Get transform between two links using the current state.
| from_link_id | The link id the transform should be relative to |
| to_link_id | The link id to get transform |
Implemented in tesseract::scene_graph::KDLStateSolver, and tesseract::scene_graph::OFKTStateSolver.
|
pure virtual |
Getter for kinematic limits.
Implemented in tesseract::scene_graph::KDLStateSolver, and tesseract::scene_graph::OFKTStateSolver.
 1.15.0