 |
Tesseract 0.28.4
|
|
Tesseract 0.28.4
|
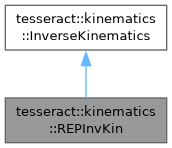
Robot With External Positioner Inverse kinematic implementation. More...
#include <rep_inv_kin.h>
Public Types | |
| using | Ptr = std::shared_ptr<REPInvKin> |
| using | ConstPtr = std::shared_ptr<const REPInvKin> |
| using | UPtr = std::unique_ptr<REPInvKin> |
| using | ConstUPtr = std::unique_ptr<const REPInvKin> |
| Public Types inherited from tesseract::kinematics::InverseKinematics | |
| using | Ptr = std::shared_ptr<InverseKinematics> |
| using | ConstPtr = std::shared_ptr<const InverseKinematics> |
| using | UPtr = std::unique_ptr<InverseKinematics> |
| using | ConstUPtr = std::unique_ptr<const InverseKinematics> |
Public Member Functions | |
| REPInvKin (const REPInvKin &other) | |
| REPInvKin & | operator= (const REPInvKin &other) |
| REPInvKin (REPInvKin &&)=default | |
| REPInvKin & | operator= (REPInvKin &&)=default |
| REPInvKin (const tesseract::scene_graph::SceneGraph &scene_graph, const tesseract::scene_graph::SceneState &scene_state, InverseKinematics::UPtr manipulator, double manipulator_reach, std::unique_ptr< ForwardKinematics > positioner, const Eigen::VectorXd &positioner_sample_resolution, std::string solver_name=DEFAULT_REP_INV_KIN_SOLVER_NAME) | |
| Construct Inverse Kinematics for a robot on a positioner. | |
| REPInvKin (const tesseract::scene_graph::SceneGraph &scene_graph, const tesseract::scene_graph::SceneState &scene_state, InverseKinematics::UPtr manipulator, double manipulator_reach, std::unique_ptr< ForwardKinematics > positioner, const Eigen::MatrixX2d &positioner_sample_range, const Eigen::VectorXd &positioner_sample_resolution, std::string solver_name=DEFAULT_REP_INV_KIN_SOLVER_NAME) | |
| Construct Inverse Kinematics for a robot on a positioner. | |
| void | calcInvKin (IKSolutions &solutions, const tesseract::common::LinkIdTransformMap &tip_link_poses, const Eigen::Ref< const Eigen::VectorXd > &seed) const override final |
| Calculates joint solutions given a pose for each tip link. | |
| std::vector< tesseract::common::JointId > | getJointIds () const override final |
| Get list of joint ids for kinematic object. | |
| Eigen::Index | numJoints () const override final |
| Number of joints in robot. | |
| tesseract::common::LinkId | getBaseLinkId () const override final |
| Get the robot base link id. | |
| tesseract::common::LinkId | getWorkingFrame () const override final |
| Get the inverse kinematics working frame. | |
| std::vector< tesseract::common::LinkId > | getTipLinkIds () const override final |
| Get the ids of the tip links of the kinematics group. | |
| std::string | getSolverName () const override final |
| Get the name of the solver. Recommend using the name of the class. | |
| InverseKinematics::UPtr | clone () const override final |
| Clone the forward kinematics object. | |
| Public Member Functions inherited from tesseract::kinematics::InverseKinematics | |
| InverseKinematics (const InverseKinematics &)=default | |
| InverseKinematics & | operator= (const InverseKinematics &)=default |
| InverseKinematics (InverseKinematics &&)=default | |
| InverseKinematics & | operator= (InverseKinematics &&)=default |
| IKSolutions | calcInvKin (const tesseract::common::LinkIdTransformMap &tip_link_poses, const Eigen::Ref< const Eigen::VectorXd > &seed) const |
| Calculates joint solutions given a pose for each tip link. | |
Robot With External Positioner Inverse kinematic implementation.
In this kinematic arrangement the base link is the tip link of the external positioner and the tip link is the tip link of the manipulator. Therefore all provided target poses are expected to the tip link of the positioner.
| tesseract::kinematics::REPInvKin::REPInvKin | ( | const tesseract::scene_graph::SceneGraph & | scene_graph, |
| const tesseract::scene_graph::SceneState & | scene_state, | ||
| InverseKinematics::UPtr | manipulator, | ||
| double | manipulator_reach, | ||
| std::unique_ptr< ForwardKinematics > | positioner, | ||
| const Eigen::VectorXd & | positioner_sample_resolution, | ||
| std::string | solver_name = DEFAULT_REP_INV_KIN_SOLVER_NAME ) |
Construct Inverse Kinematics for a robot on a positioner.
| scene_graph | The Tesseract Scene Graph |
| scene_state | The Tesseract Scene State |
| manipulator | |
| manipulator_reach | |
| positioner | |
| positioner_sample_resolution | |
| solver_name | The name given to the solver. This is exposed so you may have same solver with different |
| tesseract::kinematics::REPInvKin::REPInvKin | ( | const tesseract::scene_graph::SceneGraph & | scene_graph, |
| const tesseract::scene_graph::SceneState & | scene_state, | ||
| InverseKinematics::UPtr | manipulator, | ||
| double | manipulator_reach, | ||
| std::unique_ptr< ForwardKinematics > | positioner, | ||
| const Eigen::MatrixX2d & | positioner_sample_range, | ||
| const Eigen::VectorXd & | positioner_sample_resolution, | ||
| std::string | solver_name = DEFAULT_REP_INV_KIN_SOLVER_NAME ) |
Construct Inverse Kinematics for a robot on a positioner.
| scene_graph | The Tesseract Scene Graph |
| manipulator | |
| manipulator_reach | |
| positioner | |
| positioner_sample_range | |
| positioner_sample_resolution | |
| solver_name | The name given to the solver. This is exposed so you may have same solver with different sampling resolutions |
|
finaloverridevirtual |
Calculates joint solutions given a pose for each tip link.
This interface supports IK for both kinematic chains that have a single tool tip link and kinematic chains that have multiple tip links. For example, consider a robot with external part positioner: a pose can be specified to be relative to the tip link of the robot or the tip link of the positioner is to support a pose relative to a active link. For example a robot with an external positioner where the pose is relative to the tip link of the positioner.
| solutions | The object to store the calculated solutions |
| tip_link_poses | A map of poses corresponding to each tip link provided in getTipLinkIds and relative to the working frame of the kinematics group for which to solve inverse kinematics |
| seed | Vector of seed joint angles (size must match number of joints in kinematic object) |
Implements tesseract::kinematics::InverseKinematics.
|
finaloverridevirtual |
Get list of joint ids for kinematic object.
Implements tesseract::kinematics::InverseKinematics.
|
finaloverridevirtual |
Number of joints in robot.
Implements tesseract::kinematics::InverseKinematics.
|
finaloverridevirtual |
Get the robot base link id.
Implements tesseract::kinematics::InverseKinematics.
|
finaloverridevirtual |
Get the inverse kinematics working frame.
This is the frame of reference in which all poses given to the calcInvKin function should be defined
Implements tesseract::kinematics::InverseKinematics.
|
finaloverridevirtual |
Get the ids of the tip links of the kinematics group.
In the case of a kinematic chain, this returns one tip link; in the case of a kinematic tree this returns the tip link for each branch of the tree.
Implements tesseract::kinematics::InverseKinematics.
|
finaloverridevirtual |
Get the name of the solver. Recommend using the name of the class.
Implements tesseract::kinematics::InverseKinematics.
|
finaloverridevirtual |
Clone the forward kinematics object.
Implements tesseract::kinematics::InverseKinematics.
 1.15.0