 |
Tesseract 0.28.4
|
|
Tesseract 0.28.4
|
Forward kinematics functions. More...
#include <forward_kinematics.h>
Public Member Functions | |
| ForwardKinematics (const ForwardKinematics &)=default | |
| ForwardKinematics & | operator= (const ForwardKinematics &)=default |
| ForwardKinematics (ForwardKinematics &&)=default | |
| ForwardKinematics & | operator= (ForwardKinematics &&)=default |
| tesseract::common::LinkIdTransformMap | calcFwdKin (const Eigen::Ref< const Eigen::VectorXd > &joint_angles) const |
| Calculates the transform for each tip link in the kinematic group. | |
| Eigen::MatrixXd | calcJacobian (const Eigen::Ref< const Eigen::VectorXd > &joint_angles, const tesseract::common::LinkId &link_id) const |
| Calculates the Jacobian matrix for a given joint state in the reference frame of the specified link. | |
| virtual void | calcFwdKin (tesseract::common::LinkIdTransformMap &transforms, const Eigen::Ref< const Eigen::VectorXd > &joint_angles) const =0 |
| Calculates the transform for each tip link in the kinematic group. | |
| virtual void | calcJacobian (Eigen::Ref< Eigen::MatrixXd > jacobian, const Eigen::Ref< const Eigen::VectorXd > &joint_angles, const tesseract::common::LinkId &link_id) const =0 |
| Calculates the Jacobian matrix for a given joint state in the reference frame of the specified link. | |
| virtual tesseract::common::LinkId | getBaseLinkId () const =0 |
| Get the robot base link id. | |
| virtual std::vector< tesseract::common::JointId > | getJointIds () const =0 |
| Get list of joint ids for kinematic object. | |
| virtual std::vector< tesseract::common::LinkId > | getTipLinkIds () const =0 |
| Get list of tip link ids for kinematic object. | |
| virtual Eigen::Index | numJoints () const =0 |
| Number of joints in robot. | |
| virtual std::string | getSolverName () const =0 |
| Get the name of the solver. Recommend using the name of the class. | |
| virtual ForwardKinematics::UPtr | clone () const =0 |
| Clone the forward kinematics object. | |
Forward kinematics functions.
| tesseract::common::LinkIdTransformMap tesseract::kinematics::ForwardKinematics::calcFwdKin | ( | const Eigen::Ref< const Eigen::VectorXd > & | joint_angles | ) | const |
Calculates the transform for each tip link in the kinematic group.
This should return a transform for every link listed in getTipLinkIds() Throws an exception on failures (including uninitialized)
| joint_angles | Vector of joint angles (size must match number of joints in robot chain) |
| Eigen::MatrixXd tesseract::kinematics::ForwardKinematics::calcJacobian | ( | const Eigen::Ref< const Eigen::VectorXd > & | joint_angles, |
| const tesseract::common::LinkId & | link_id ) const |
Calculates the Jacobian matrix for a given joint state in the reference frame of the specified link.
This should be able to return a jacobian given any link listed in getTipLinkIds() Throws an exception on failures (including uninitialized)
| joint_angles | Input vector of joint angles |
| link_id | The link id to calculate jacobian |
|
pure virtual |
Calculates the transform for each tip link in the kinematic group.
This should return a transform for every link listed in getTipLinkIds() Throws an exception on failures (including uninitialized)
| transforms(out) | The object to populate with transforms |
| joint_angles | Vector of joint angles (size must match number of joints in robot chain) |
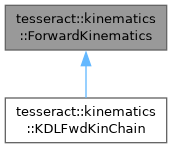
Implemented in tesseract::kinematics::KDLFwdKinChain.
|
pure virtual |
Calculates the Jacobian matrix for a given joint state in the reference frame of the specified link.
This should be able to return a jacobian given any link listed in getTipLinkIds() Throws an exception on failures (including uninitialized)
| jacobian[out] | The object to populate (assumes already the correct size) |
| joint_angles | Input vector of joint angles |
| link_id | The link id to calculate jacobian |
Implemented in tesseract::kinematics::KDLFwdKinChain.
|
pure virtual |
Get the robot base link id.
Implemented in tesseract::kinematics::KDLFwdKinChain.
|
pure virtual |
Get list of joint ids for kinematic object.
Implemented in tesseract::kinematics::KDLFwdKinChain.
|
pure virtual |
Get list of tip link ids for kinematic object.
Implemented in tesseract::kinematics::KDLFwdKinChain.
|
pure virtual |
Number of joints in robot.
Implemented in tesseract::kinematics::KDLFwdKinChain.
|
pure virtual |
Get the name of the solver. Recommend using the name of the class.
Implemented in tesseract::kinematics::KDLFwdKinChain.
|
pure virtual |
Clone the forward kinematics object.
Implemented in tesseract::kinematics::KDLFwdKinChain.
 1.15.0