 |
Tesseract 0.28.4
|
|
Tesseract 0.28.4
|
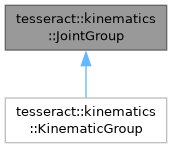
A Joint Group is defined by a list of joint_names. More...
#include <joint_group.h>
Public Types | |
| using | Ptr = std::shared_ptr<JointGroup> |
| using | ConstPtr = std::shared_ptr<const JointGroup> |
| using | UPtr = std::unique_ptr<JointGroup> |
| using | ConstUPtr = std::unique_ptr<const JointGroup> |
Public Member Functions | |
| JointGroup (const JointGroup &other) | |
| JointGroup & | operator= (const JointGroup &other) |
| JointGroup (JointGroup &&)=default | |
| JointGroup & | operator= (JointGroup &&)=default |
| JointGroup (std::string name, std::vector< tesseract::common::JointId > joint_ids, const tesseract::scene_graph::SceneGraph &scene_graph, const tesseract::scene_graph::SceneState &scene_state) | |
| Create a kinematics group without inverse kinematics for the provided joint ids. | |
| tesseract::common::LinkIdTransformMap | calcFwdKin (const Eigen::Ref< const Eigen::VectorXd > &joint_angles) const |
| Calculates tool pose of robot chain. | |
| void | calcFwdKin (tesseract::common::LinkIdTransformMap &transforms, const Eigen::Ref< const Eigen::VectorXd > &joint_angles) const |
| Calculates tool pose of robot chain. | |
| Eigen::MatrixXd | calcJacobian (const Eigen::Ref< const Eigen::VectorXd > &joint_angles, const tesseract::common::LinkId &link_id) const |
| Calculates jacobian of robot given joint angles. | |
| Eigen::MatrixXd | calcJacobian (const Eigen::Ref< const Eigen::VectorXd > &joint_angles, const tesseract::common::LinkId &link_id, const Eigen::Vector3d &link_point) const |
| Calculates jacobian of robot given joint angles. | |
| Eigen::MatrixXd | calcJacobian (const Eigen::Ref< const Eigen::VectorXd > &joint_angles, const tesseract::common::LinkId &base_link_id, const tesseract::common::LinkId &link_id) const |
| Calculates jacobian of robot given joint angles. | |
| Eigen::MatrixXd | calcJacobian (const Eigen::Ref< const Eigen::VectorXd > &joint_angles, const tesseract::common::LinkId &base_link_id, const tesseract::common::LinkId &link_id, const Eigen::Vector3d &link_point) const |
| Calculates jacobian of robot given joint angles. | |
| const std::vector< tesseract::common::JointId > & | getJointIds () const |
| Get list of joint ids for kinematic object. | |
| const std::vector< tesseract::common::LinkId > & | getLinkIds () const |
| Get list of all link ids (with and without geometry) for kinematic object. | |
| const std::vector< tesseract::common::LinkId > & | getActiveLinkIds () const |
| Get list of active link ids (with and without geometry) for kinematic object. | |
| const std::vector< tesseract::common::LinkId > & | getStaticLinkIds () const |
| Get list of static link ids (with and without geometry) for kinematic object. | |
| bool | isActiveLinkId (const tesseract::common::LinkId &link_id) const |
| Check if link is an active link. | |
| bool | hasLinkId (const tesseract::common::LinkId &link_id) const |
| Check if link id exists. | |
| tesseract::common::KinematicLimits | getLimits () const |
| Get the kinematic limits (joint, velocity, acceleration, etc.). | |
| void | setLimits (const tesseract::common::KinematicLimits &limits) |
| Setter for kinematic limits (joint, velocity, acceleration, etc.). | |
| std::vector< Eigen::Index > | getRedundancyCapableJointIndices () const |
| Get vector indicating which joints are capable of producing redundant solutions. | |
| Eigen::Index | numJoints () const |
| Number of joints in robot. | |
| tesseract::common::LinkId | getBaseLinkId () const |
| Get the robot base link ID. | |
| std::string | getName () const |
| Name of the manipulator. | |
| bool | checkJoints (const Eigen::Ref< const Eigen::VectorXd > &vec) const |
| Check for consistency in # and limits of joints. | |
Protected Attributes | |
| std::string | name_ |
| tesseract::scene_graph::SceneState | state_ |
| std::unique_ptr< tesseract::scene_graph::StateSolver > | state_solver_ |
| std::vector< tesseract::common::LinkId > | link_ids_ |
| std::vector< tesseract::common::JointId > | joint_ids_ |
| std::unordered_set< tesseract::common::LinkId > | link_id_set_ |
| std::vector< tesseract::common::LinkId > | active_link_ids_ |
| std::unordered_set< tesseract::common::LinkId > | active_link_ids_set_ |
| std::vector< tesseract::common::LinkId > | static_link_ids_ |
| tesseract::common::LinkIdTransformMap | static_link_transforms_ |
| tesseract::common::KinematicLimits | limits_ |
| std::vector< Eigen::Index > | redundancy_indices_ |
| std::vector< Eigen::Index > | jacobian_map_ |
A Joint Group is defined by a list of joint_names.
Provides the ability to calculate forward kinematics and jacobian.
| tesseract::kinematics::JointGroup::JointGroup | ( | std::string | name, |
| std::vector< tesseract::common::JointId > | joint_ids, | ||
| const tesseract::scene_graph::SceneGraph & | scene_graph, | ||
| const tesseract::scene_graph::SceneState & | scene_state ) |
Create a kinematics group without inverse kinematics for the provided joint ids.
| name | The name of the kinematic group |
| joint_ids | The joint ids to create kinematic group from |
| scene_graph | The scene graph |
| scene_state | The scene state |
| tesseract::common::LinkIdTransformMap tesseract::kinematics::JointGroup::calcFwdKin | ( | const Eigen::Ref< const Eigen::VectorXd > & | joint_angles | ) | const |
Calculates tool pose of robot chain.
Throws an exception on failures (including uninitialized)
| joint_angles | Vector of joint angles (size must match number of joints in robot chain) |
| void tesseract::kinematics::JointGroup::calcFwdKin | ( | tesseract::common::LinkIdTransformMap & | transforms, |
| const Eigen::Ref< const Eigen::VectorXd > & | joint_angles ) const |
Calculates tool pose of robot chain.
Throws an exception on failures (including uninitialized). Overwrites the transform of every link in the group but does not clear transforms first; keys from another group persist. Reusing a scratch map without clearing is safe iff every key later read is a link of this group.
| transforms | The map to populate with transforms |
| joint_angles | Vector of joint angles (size must match number of joints in robot chain) |
| Eigen::MatrixXd tesseract::kinematics::JointGroup::calcJacobian | ( | const Eigen::Ref< const Eigen::VectorXd > & | joint_angles, |
| const tesseract::common::LinkId & | link_id ) const |
Calculates jacobian of robot given joint angles.
| joint_angles | Input vector of joint angles |
| link_id | The frame that the jacobian is calculated for |
| Eigen::MatrixXd tesseract::kinematics::JointGroup::calcJacobian | ( | const Eigen::Ref< const Eigen::VectorXd > & | joint_angles, |
| const tesseract::common::LinkId & | link_id, | ||
| const Eigen::Vector3d & | link_point ) const |
Calculates jacobian of robot given joint angles.
| joint_angles | Input vector of joint angles |
| link_id | The frame that the jacobian is calculated for |
| link_point | A point on the link that the jacobian is calculated for |
| Eigen::MatrixXd tesseract::kinematics::JointGroup::calcJacobian | ( | const Eigen::Ref< const Eigen::VectorXd > & | joint_angles, |
| const tesseract::common::LinkId & | base_link_id, | ||
| const tesseract::common::LinkId & | link_id ) const |
Calculates jacobian of robot given joint angles.
| joint_angles | Input vector of joint angles |
| base_link_id | The frame that the jacobian is calculated in |
| link_id | The frame that the jacobian is calculated for |
| std::runtime_error | If the base link does not exist |
| Eigen::MatrixXd tesseract::kinematics::JointGroup::calcJacobian | ( | const Eigen::Ref< const Eigen::VectorXd > & | joint_angles, |
| const tesseract::common::LinkId & | base_link_id, | ||
| const tesseract::common::LinkId & | link_id, | ||
| const Eigen::Vector3d & | link_point ) const |
Calculates jacobian of robot given joint angles.
| joint_angles | Input vector of joint angles |
| base_link_id | The frame that the jacobian is calculated in |
| link_id | The frame that the jacobian is calculated for |
| link_point | A point on the link that the jacobian is calculated for |
| std::runtime_error | If the base link does not exist |
| const std::vector< tesseract::common::JointId > & tesseract::kinematics::JointGroup::getJointIds | ( | ) | const |
Get list of joint ids for kinematic object.
| const std::vector< tesseract::common::LinkId > & tesseract::kinematics::JointGroup::getLinkIds | ( | ) | const |
Get list of all link ids (with and without geometry) for kinematic object.
| const std::vector< tesseract::common::LinkId > & tesseract::kinematics::JointGroup::getActiveLinkIds | ( | ) | const |
Get list of active link ids (with and without geometry) for kinematic object.
Note: This only includes links that are children of the active joints
| const std::vector< tesseract::common::LinkId > & tesseract::kinematics::JointGroup::getStaticLinkIds | ( | ) | const |
Get list of static link ids (with and without geometry) for kinematic object.
| bool tesseract::kinematics::JointGroup::isActiveLinkId | ( | const tesseract::common::LinkId & | link_id | ) | const |
Check if link is an active link.
| link_id | The link id to check |
| bool tesseract::kinematics::JointGroup::hasLinkId | ( | const tesseract::common::LinkId & | link_id | ) | const |
Check if link id exists.
| link_id | The link id to check for |
| tesseract::common::KinematicLimits tesseract::kinematics::JointGroup::getLimits | ( | ) | const |
Get the kinematic limits (joint, velocity, acceleration, etc.).
| void tesseract::kinematics::JointGroup::setLimits | ( | const tesseract::common::KinematicLimits & | limits | ) |
Setter for kinematic limits (joint, velocity, acceleration, etc.).
| Kinematic | Limits |
| std::vector< Eigen::Index > tesseract::kinematics::JointGroup::getRedundancyCapableJointIndices | ( | ) | const |
Get vector indicating which joints are capable of producing redundant solutions.
| Eigen::Index tesseract::kinematics::JointGroup::numJoints | ( | ) | const |
Number of joints in robot.
| bool tesseract::kinematics::JointGroup::checkJoints | ( | const Eigen::Ref< const Eigen::VectorXd > & | vec | ) | const |
Check for consistency in # and limits of joints.
| vec | Vector of joint values |
 1.15.0