 |
Tesseract 0.28.4
|
|
Tesseract 0.28.4
|
Public Member Functions | |
| DiscreteContactManager (const DiscreteContactManager &)=delete | |
| DiscreteContactManager & | operator= (const DiscreteContactManager &)=delete |
| DiscreteContactManager (DiscreteContactManager &&)=delete | |
| DiscreteContactManager & | operator= (DiscreteContactManager &&)=delete |
| virtual std::string | getName () const =0 |
| Get the name of the contact manager. | |
| virtual DiscreteContactManager::UPtr | clone () const =0 |
| Clone the manager. | |
| virtual bool | addCollisionObject (const tesseract::common::LinkId &id, const int &mask_id, const CollisionShapesConst &shapes, const tesseract::common::VectorIsometry3d &shape_poses, bool enabled=true)=0 |
| Add a object to the checker. | |
| virtual bool | addCollisionObjects (const std::vector< CollisionObjectSpec > &objects) |
| Add a batch of collision objects, applying one broadphase update per batch where the backend supports it. | |
| virtual const CollisionShapesConst & | getCollisionObjectGeometries (const tesseract::common::LinkId &id) const =0 |
| Get a collision objects collision geometries. | |
| virtual const tesseract::common::VectorIsometry3d & | getCollisionObjectGeometriesTransforms (const tesseract::common::LinkId &id) const =0 |
| Get a collision objects collision geometries transforms. | |
| virtual bool | hasCollisionObject (const tesseract::common::LinkId &id) const =0 |
| Find if a collision object already exists. | |
| virtual bool | removeCollisionObject (const tesseract::common::LinkId &id)=0 |
| Remove an object from the checker. | |
| virtual bool | removeCollisionObjects (const std::vector< tesseract::common::LinkId > &ids) |
| Remove a batch of collision objects, applying one broadphase and cache update per batch where the backend supports it. | |
| virtual bool | enableCollisionObject (const tesseract::common::LinkId &id)=0 |
| Enable an object. | |
| virtual bool | disableCollisionObject (const tesseract::common::LinkId &id)=0 |
| Disable an object. | |
| virtual bool | isCollisionObjectEnabled (const tesseract::common::LinkId &id) const =0 |
| Check if collision object is enabled. | |
| virtual bool | setCollisionObjectsEnabled (const std::unordered_map< tesseract::common::LinkId, bool > &enabled) |
| Enable or disable a batch of collision objects, applying one broadphase update per batch where the backend supports it. | |
| bool | setCollisionObjectsEnabled (const std::vector< tesseract::common::LinkId > &ids, bool enabled) |
| Enable or disable a batch of collision objects that all take the same state. | |
| virtual void | setCollisionObjectsTransform (const tesseract::common::LinkId &id, const Eigen::Isometry3d &pose)=0 |
| Set a single collision object's transforms. | |
| virtual Eigen::Isometry3d | getCollisionObjectsTransform (const tesseract::common::LinkId &id) const =0 |
| Get the world transform of a single collision object. | |
| virtual void | setCollisionObjectsTransform (const tesseract::common::LinkIdTransformMap &transforms)=0 |
| Set a series of collision object's transforms. | |
| virtual void | setCollisionObjectsTransform (const std::vector< tesseract::common::LinkId > &ids, const tesseract::common::VectorIsometry3d &poses) |
| Set a series of collision object's transforms. | |
| virtual void | setCollisionObjectsTransform (const std::unordered_set< tesseract::common::LinkId > &ids, const tesseract::common::LinkIdTransformMap &state) |
| Set the transforms of a set of collision objects from a transform map. | |
| virtual void | setCollisionObjectsTransform (const std::vector< tesseract::common::LinkId > &ids, const tesseract::common::LinkIdTransformMap &state) |
| Set the transforms of a list of collision objects from a transform map. | |
| virtual const std::vector< tesseract::common::LinkId > & | getCollisionObjects () const =0 |
| Get all collision objects. | |
| virtual void | setActiveCollisionObjects (const std::unordered_set< tesseract::common::LinkId > &ids)=0 |
| Set which collision objects can move. | |
| virtual void | setActiveCollisionObjects (const std::vector< tesseract::common::LinkId > &ids) |
| Set which collision objects can move by vector (delegates to set overload). | |
| virtual void | setActiveCollisionObjects (std::initializer_list< tesseract::common::LinkId > ids) |
| Set which collision objects can move by initializer list (delegates to set overload). | |
| virtual const std::unordered_set< tesseract::common::LinkId > & | getActiveCollisionObjects () const =0 |
| Get which collision objects can move. | |
| virtual void | setCollisionMarginData (CollisionMarginData collision_margin_data)=0 |
| Set the contact distance threshold. | |
| virtual const CollisionMarginData & | getCollisionMarginData () const =0 |
| Get the contact distance threshold. | |
| virtual void | setCollisionMarginPairData (const CollisionMarginPairData &pair_margin_data, CollisionMarginPairOverrideType override_type=CollisionMarginPairOverrideType::REPLACE)=0 |
| Set the contact distance thresholds for which collision should be considered on a per pair basis. | |
| virtual void | setDefaultCollisionMargin (double default_collision_margin)=0 |
| Set the default collision margin. | |
| virtual void | setCollisionMarginPair (const tesseract::common::LinkId &id1, const tesseract::common::LinkId &id2, double collision_margin)=0 |
| Set the margin for a given contact pair. | |
| virtual void | incrementCollisionMargin (double increment)=0 |
| Increment the collision margin data by some value. | |
| virtual void | setContactAllowedValidator (std::shared_ptr< const tesseract::common::ContactAllowedValidator > validator)=0 |
| Set the active function for determining if two links are allowed to be in collision. | |
| virtual std::shared_ptr< const tesseract::common::ContactAllowedValidator > | getContactAllowedValidator () const =0 |
| Get the active function for determining if two links are allowed to be in collision. | |
| virtual void | contactTest (ContactResultMap &collisions, const ContactRequest &request)=0 |
| Perform a contact test for all objects based. | |
| virtual void | applyContactManagerConfig (const ContactManagerConfig &config) |
| Applies settings in the config. | |
|
pure virtual |
Get the name of the contact manager.
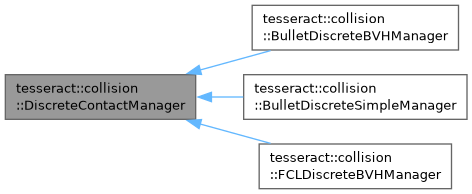
Implemented in tesseract::collision::BulletDiscreteBVHManager, tesseract::collision::BulletDiscreteSimpleManager, and tesseract::collision::FCLDiscreteBVHManager.
|
pure virtual |
Clone the manager.
This is to be used for multi threaded application. A user should make a clone for each thread.
Implemented in tesseract::collision::BulletDiscreteBVHManager, tesseract::collision::BulletDiscreteSimpleManager, and tesseract::collision::FCLDiscreteBVHManager.
|
pure virtual |
Add a object to the checker.
| id | The LinkId of the object, must be unique. |
| mask_id | User defined id which gets stored in the results structure. |
| shapes | A vector of shapes that make up the collision object. |
| shape_poses | A vector of poses for each shape, must be same length as shapes |
Implemented in tesseract::collision::BulletDiscreteBVHManager, tesseract::collision::BulletDiscreteSimpleManager, and tesseract::collision::FCLDiscreteBVHManager.
|
virtual |
Add a batch of collision objects, applying one broadphase update per batch where the backend supports it.
Observably equivalent to calling addCollisionObject once per entry, in order. A false return still leaves every object that was added registered; only the failing ones are absent. Within one batch a repeated id behaves as the repeated single calls do: the last entry naming that id decides both the object and its position in getCollisionObjects(), and if that last entry fails the id is left unregistered even when an earlier entry for it succeeded. Equivalence covers returns, not throws: building an object may throw, and a backend that builds the whole batch before it mutates anything then leaves the manager untouched where the repeated single calls would have left the earlier entries applied.
| objects | The objects to add |
Reimplemented in tesseract::collision::FCLDiscreteBVHManager.
|
pure virtual |
Get a collision objects collision geometries.
| id | The collision object's LinkId |
Implemented in tesseract::collision::BulletDiscreteBVHManager, tesseract::collision::BulletDiscreteSimpleManager, and tesseract::collision::FCLDiscreteBVHManager.
|
pure virtual |
Get a collision objects collision geometries transforms.
| id | The collision object's LinkId |
Implemented in tesseract::collision::BulletDiscreteBVHManager, tesseract::collision::BulletDiscreteSimpleManager, and tesseract::collision::FCLDiscreteBVHManager.
|
pure virtual |
Find if a collision object already exists.
| id | The LinkId of the collision object |
Implemented in tesseract::collision::BulletDiscreteBVHManager, tesseract::collision::BulletDiscreteSimpleManager, and tesseract::collision::FCLDiscreteBVHManager.
|
pure virtual |
Remove an object from the checker.
| id | The LinkId of the object |
Implemented in tesseract::collision::BulletDiscreteBVHManager, tesseract::collision::BulletDiscreteSimpleManager, and tesseract::collision::FCLDiscreteBVHManager.
|
virtual |
Remove a batch of collision objects, applying one broadphase and cache update per batch where the backend supports it.
Observably equivalent to calling removeCollisionObject once per id, in order. Within one batch a repeated id behaves as the repeated single calls do: the first occurrence removes it and the second reports it absent.
| ids | The LinkIds to remove; ids the manager does not hold are skipped |
Reimplemented in tesseract::collision::BulletDiscreteBVHManager, and tesseract::collision::FCLDiscreteBVHManager.
|
pure virtual |
Enable an object.
| id | The LinkId of the object |
Implemented in tesseract::collision::BulletDiscreteBVHManager, tesseract::collision::BulletDiscreteSimpleManager, and tesseract::collision::FCLDiscreteBVHManager.
|
pure virtual |
Disable an object.
| id | The LinkId of the object |
Implemented in tesseract::collision::BulletDiscreteBVHManager, tesseract::collision::BulletDiscreteSimpleManager, and tesseract::collision::FCLDiscreteBVHManager.
|
pure virtual |
Check if collision object is enabled.
| id | The LinkId of the object |
Implemented in tesseract::collision::BulletDiscreteBVHManager, tesseract::collision::BulletDiscreteSimpleManager, and tesseract::collision::FCLDiscreteBVHManager.
|
virtual |
Enable or disable a batch of collision objects, applying one broadphase update per batch where the backend supports it.
Observably equivalent to calling enableCollisionObject or disableCollisionObject once per entry. A map key occurs at most once, so there is no duplicate-id case.
| enabled | Map of [link id] to true (enable) or false (disable); ids the manager does not hold are skipped |
Reimplemented in tesseract::collision::BulletDiscreteBVHManager.
| bool tesseract::collision::DiscreteContactManager::setCollisionObjectsEnabled | ( | const std::vector< tesseract::common::LinkId > & | ids, |
| bool | enabled ) |
Enable or disable a batch of collision objects that all take the same state.
Builds the map form's argument and forwards to it, so it carries that overload's contract exactly. It is not virtual: a backend customises the batch by overriding the map overload.
| ids | The link ids to enable or disable; ids the manager does not hold are skipped |
| enabled | True to enable every named object, false to disable every named object |
|
pure virtual |
Set a single collision object's transforms.
| id | The LinkId of the object |
| pose | The transformation in world |
Implemented in tesseract::collision::BulletDiscreteBVHManager, tesseract::collision::BulletDiscreteSimpleManager, and tesseract::collision::FCLDiscreteBVHManager.
|
pure virtual |
Get the world transform of a single collision object.
| id | The LinkId of the object |
| std::out_of_range | if the LinkId is not registered with the manager |
Implemented in tesseract::collision::BulletDiscreteBVHManager, tesseract::collision::BulletDiscreteSimpleManager, and tesseract::collision::FCLDiscreteBVHManager.
|
pure virtual |
Set a series of collision object's transforms.
| transforms | A transform map <LinkId, pose> |
Implemented in tesseract::collision::BulletDiscreteBVHManager, tesseract::collision::BulletDiscreteSimpleManager, and tesseract::collision::FCLDiscreteBVHManager.
|
virtual |
Set a series of collision object's transforms.
| ids | The LinkIds of the objects |
| poses | The poses, one per id |
| std::runtime_error | if ids and poses differ in size |
Reimplemented in tesseract::collision::BulletDiscreteBVHManager, tesseract::collision::BulletDiscreteSimpleManager, and tesseract::collision::FCLDiscreteBVHManager.
|
virtual |
Set the transforms of a set of collision objects from a transform map.
| ids | The LinkIds of the objects to update |
| state | A transform map that must contain every id |
| std::out_of_range | if an id is absent from state |
Reimplemented in tesseract::collision::BulletDiscreteBVHManager, tesseract::collision::BulletDiscreteSimpleManager, and tesseract::collision::FCLDiscreteBVHManager.
|
virtual |
Set the transforms of a list of collision objects from a transform map.
| std::out_of_range | if an id is absent from state |
Reimplemented in tesseract::collision::BulletDiscreteBVHManager, tesseract::collision::BulletDiscreteSimpleManager, and tesseract::collision::FCLDiscreteBVHManager.
|
pure virtual |
Get all collision objects.
Implemented in tesseract::collision::BulletDiscreteBVHManager, tesseract::collision::BulletDiscreteSimpleManager, and tesseract::collision::FCLDiscreteBVHManager.
|
pure virtual |
Set which collision objects can move.
| ids | A set of LinkIds identifying the active collision objects |
Implemented in tesseract::collision::BulletDiscreteBVHManager, tesseract::collision::BulletDiscreteSimpleManager, and tesseract::collision::FCLDiscreteBVHManager.
|
virtual |
Set which collision objects can move by vector (delegates to set overload).
Reimplemented in tesseract::collision::BulletDiscreteBVHManager, tesseract::collision::BulletDiscreteSimpleManager, and tesseract::collision::FCLDiscreteBVHManager.
|
virtual |
Set which collision objects can move by initializer list (delegates to set overload).
Reimplemented in tesseract::collision::BulletDiscreteBVHManager, tesseract::collision::BulletDiscreteSimpleManager, and tesseract::collision::FCLDiscreteBVHManager.
|
pure virtual |
Get which collision objects can move.
Implemented in tesseract::collision::BulletDiscreteBVHManager, tesseract::collision::BulletDiscreteSimpleManager, and tesseract::collision::FCLDiscreteBVHManager.
|
pure virtual |
Set the contact distance threshold.
| collision_margin_data | The contact distance |
Implemented in tesseract::collision::BulletDiscreteBVHManager, tesseract::collision::BulletDiscreteSimpleManager, and tesseract::collision::FCLDiscreteBVHManager.
|
pure virtual |
Get the contact distance threshold.
Implemented in tesseract::collision::BulletDiscreteBVHManager, tesseract::collision::BulletDiscreteSimpleManager, and tesseract::collision::FCLDiscreteBVHManager.
|
pure virtual |
Set the contact distance thresholds for which collision should be considered on a per pair basis.
| pair_margin_data | Contains the pair collision margins that will replace the current settings |
| override_type | This determines how the provided CollisionMarginData is applied |
Implemented in tesseract::collision::BulletDiscreteBVHManager, tesseract::collision::BulletDiscreteSimpleManager, and tesseract::collision::FCLDiscreteBVHManager.
|
pure virtual |
Set the default collision margin.
| default_collision_margin | New default collision margin |
Implemented in tesseract::collision::BulletDiscreteBVHManager, tesseract::collision::BulletDiscreteSimpleManager, and tesseract::collision::FCLDiscreteBVHManager.
|
pure virtual |
Set the margin for a given contact pair.
The order of the object ids does not matter, that is handled internal to the class.
| obj1 | The first object id. Order doesn't matter |
| obj2 | The Second object id. Order doesn't matter |
| collision_margin | contacts with distance < collision_margin are considered in collision |
Implemented in tesseract::collision::BulletDiscreteBVHManager, tesseract::collision::BulletDiscreteSimpleManager, and tesseract::collision::FCLDiscreteBVHManager.
|
pure virtual |
Increment the collision margin data by some value.
| increment | The value to increment the collision margin value |
Implemented in tesseract::collision::BulletDiscreteBVHManager, tesseract::collision::BulletDiscreteSimpleManager, and tesseract::collision::FCLDiscreteBVHManager.
|
pure virtual |
Set the active function for determining if two links are allowed to be in collision.
Implemented in tesseract::collision::BulletDiscreteBVHManager, tesseract::collision::BulletDiscreteSimpleManager, and tesseract::collision::FCLDiscreteBVHManager.
|
pure virtual |
Get the active function for determining if two links are allowed to be in collision.
Implemented in tesseract::collision::BulletDiscreteBVHManager, tesseract::collision::BulletDiscreteSimpleManager, and tesseract::collision::FCLDiscreteBVHManager.
|
pure virtual |
Perform a contact test for all objects based.
| collisions | The contact results data |
| request | The contact request data |
Implemented in tesseract::collision::BulletDiscreteBVHManager, tesseract::collision::BulletDiscreteSimpleManager, and tesseract::collision::FCLDiscreteBVHManager.
|
virtual |
Applies settings in the config.
| config | Settings to be applies |
 1.15.0