 |
Tesseract 0.28.4
|
|
Tesseract 0.28.4
|
Should return true if links are allowed to be in collision, otherwise false. More...
#include <contact_allowed_validator.h>
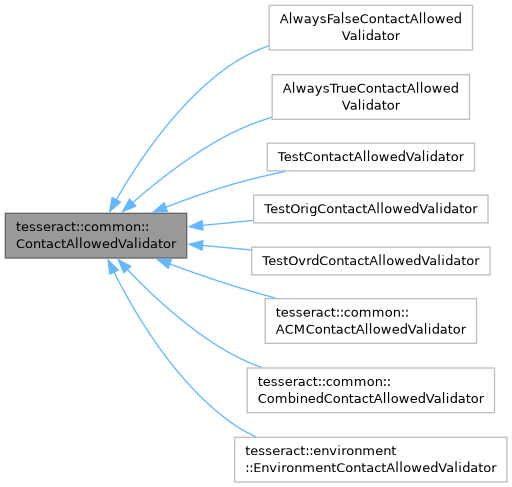
Public Types | |
| using | Ptr = std::shared_ptr<ContactAllowedValidator> |
| using | ConstPtr = std::shared_ptr<const ContactAllowedValidator> |
| using | UPtr = std::unique_ptr<ContactAllowedValidator> |
| using | ConstUPtr = std::unique_ptr<const ContactAllowedValidator> |
Public Member Functions | |
| virtual bool | operator() (const LinkIdPair &pair) const =0 |
Should return true if links are allowed to be in collision, otherwise false.
 1.15.0