 |
Tesseract 0.28.4
|
|
Tesseract 0.28.4
|
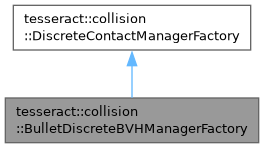
The yaml config for each of the factories below is the same. More...
#include <bullet_factories.h>
Public Member Functions | |
| tesseract::common::PropertyTree | schema () const override |
| Return the PropertyTree schema describing the config this factory accepts. | |
| Public Member Functions inherited from tesseract::collision::DiscreteContactManagerFactory | |
| std::unique_ptr< DiscreteContactManager > | create (const std::string &name, const YAML::Node &config) const |
| Create Discrete Contact Manager Object. | |
Protected Member Functions | |
| std::unique_ptr< DiscreteContactManager > | createImpl (const std::string &name, const tesseract::common::PropertyTree &config) const override final |
Additional Inherited Members | |
| Public Types inherited from tesseract::collision::DiscreteContactManagerFactory | |
| using | Ptr = std::shared_ptr<DiscreteContactManagerFactory> |
| using | ConstPtr = std::shared_ptr<const DiscreteContactManagerFactory> |
| Static Protected Member Functions inherited from tesseract::collision::DiscreteContactManagerFactory | |
| static std::string | getSection () |
The yaml config for each of the factories below is the same.
The config and its parameters shown below are optional The values shown below are the default that will be used.
The current defaults will result in 7MB being allocated for every contact manager created. If share_pool_allocators is set to true then this 7MB is shared between it and any clones created.
Example Yaml Config:
plugins: BulletDiscreteBVHManager: class: BulletDiscreteBVHManagerFactory config: share_pool_allocators: false max_persistent_manifold_pool_size: 4096 max_collision_algorithm_pool_size: 4096
|
overridevirtual |
Return the PropertyTree schema describing the config this factory accepts.
Reimplemented from tesseract::collision::DiscreteContactManagerFactory.
|
finaloverrideprotectedvirtual |
 1.15.0