 |
Tesseract 0.28.4
|
|
Tesseract 0.28.4
|
Define a inverse kinematics plugin which the factory can create an instance. More...
#include <kinematics_plugin_factory.h>
Public Types | |
| using | Ptr = std::shared_ptr<InvKinFactory> |
| using | ConstPtr = std::shared_ptr<const InvKinFactory> |
Public Member Functions | |
| std::unique_ptr< InverseKinematics > | create (const std::string &solver_name, const tesseract::scene_graph::SceneGraph &scene_graph, const tesseract::scene_graph::SceneState &scene_state, const KinematicsPluginFactory &plugin_factory, const YAML::Node &config) const |
| Create Inverse Kinematics Object. | |
| virtual tesseract::common::PropertyTree | schema () const |
| Return the PropertyTree schema describing the config this factory accepts. | |
Protected Member Functions | |
| virtual std::unique_ptr< InverseKinematics > | createImpl (const std::string &solver_name, const tesseract::scene_graph::SceneGraph &scene_graph, const tesseract::scene_graph::SceneState &scene_state, const KinematicsPluginFactory &plugin_factory, const tesseract::common::PropertyTree &config) const =0 |
Static Protected Member Functions | |
| static std::string | getSection () |
Friends | |
| class | boost_plugin_loader::PluginLoader |
| class | KinematicsPluginFactory |
Define a inverse kinematics plugin which the factory can create an instance.
| std::unique_ptr< InverseKinematics > tesseract::kinematics::InvKinFactory::create | ( | const std::string & | solver_name, |
| const tesseract::scene_graph::SceneGraph & | scene_graph, | ||
| const tesseract::scene_graph::SceneState & | scene_state, | ||
| const KinematicsPluginFactory & | plugin_factory, | ||
| const YAML::Node & | config ) const |
Create Inverse Kinematics Object.
| solver_name | The solver name of the kinematic object |
| scene_graph | The Tesseract Scene Graph |
| scene_state | The state of the scene graph |
| plugin_factory | Provide access to the plugin factory so plugins and load plugins |
| tesseract::common::PropertyTreeValidationError | if config does not match schema() |
| std::exception | if the implementation fails to create the object |
|
virtual |
Return the PropertyTree schema describing the config this factory accepts.
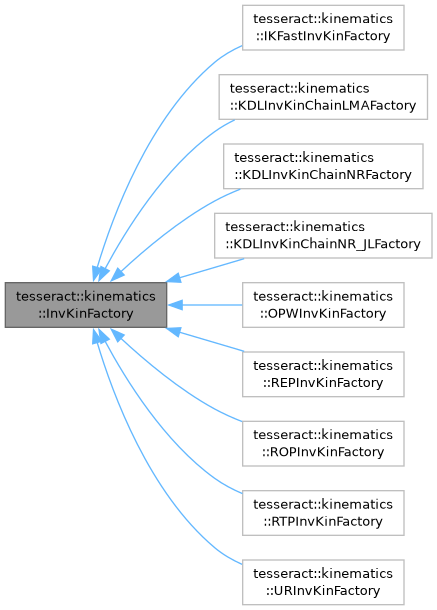
Reimplemented in tesseract::kinematics::IKFastInvKinFactory, tesseract::kinematics::KDLInvKinChainLMAFactory, tesseract::kinematics::KDLInvKinChainNR_JLFactory, tesseract::kinematics::KDLInvKinChainNRFactory, tesseract::kinematics::OPWInvKinFactory, tesseract::kinematics::REPInvKinFactory, tesseract::kinematics::ROPInvKinFactory, tesseract::kinematics::RTPInvKinFactory, and tesseract::kinematics::URInvKinFactory.
 1.15.0