
Tesseract 0.28.4
Loading...
Searching...
No Matches
tesseract::collision::bullet_internal::TesseractConvexSdfAlgorithm Class Reference

Convex vs signed distance field narrowphase that honors the contact distance threshold. More...

#include <tesseract_convex_sdf_algorithm.h>
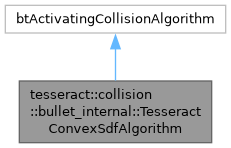
Inheritance diagram for tesseract::collision::bullet_internal::TesseractConvexSdfAlgorithm:

Classes

struct  CreateFunc
struct  SwappedCreateFunc

Public Member Functions

 TesseractConvexSdfAlgorithm (btPersistentManifold *mf, const btCollisionAlgorithmConstructionInfo &ci, const btCollisionObjectWrapper *body0Wrap, const btCollisionObjectWrapper *body1Wrap, bool isSwapped)
 TesseractConvexSdfAlgorithm (const TesseractConvexSdfAlgorithm &)=delete
TesseractConvexSdfAlgorithm & operator= (const TesseractConvexSdfAlgorithm &)=delete
 TesseractConvexSdfAlgorithm (TesseractConvexSdfAlgorithm &&)=delete
TesseractConvexSdfAlgorithm & operator= (TesseractConvexSdfAlgorithm &&)=delete
void processCollision (const btCollisionObjectWrapper *body0Wrap, const btCollisionObjectWrapper *body1Wrap, const btDispatcherInfo &dispatchInfo, btManifoldResult *resultOut) override
btScalar calculateTimeOfImpact (btCollisionObject *body0, btCollisionObject *body1, const btDispatcherInfo &dispatchInfo, btManifoldResult *resultOut) override
void getAllContactManifolds (btManifoldArray &manifoldArray) override

Detailed Description

Convex vs signed distance field narrowphase that honors the contact distance threshold.

Stock Bullet only samples an SDF at a convex shape's vertices, and ignores btManifoldResult::m_closestPointDistanceThreshold, so separated contacts inside the collision margin are never reported; Tesseract's margin-based consumers (TrajOpt costs, contact gates) need them. Boxes, spheres, capsules, cylinders and cones are collided with the field through the backend-neutral implicit solver. Other polyhedra fall back to sampling the field at their vertices, with the acceptance band widened by the pair's contact distance threshold.